How to make physical intelligence continue to evolve has always been a central issue for the entire industry.
The most direct approach is to improve single-unit capabilities - more agile hands, stronger generalization capabilities, more reliable execution performance, etc. This is also the most competitive direction in the industry for a long time.
But real-world tasks are never designed specifically for one person or a robot. A smarter robot can't solve all problems.
So another idea slowly became important: how about adding robots to complex tasks?
Collaborative models are naturally suitable for those physical tasks that require multiple action points, multiple workspaces, or scenarios where parallel operations occur.
In factories, multiple general-purpose robots typically work at their own pace, making full use of single-unit intelligence; they can quickly combine capabilities when faced with complex tasks. The physical capabilities required for the system can be expanded almost linearly as the number of robots increases, without having to redesign an entire automation program each time.
But if robots leave the flow line, get out of control of the central controller, and into a more general scenario, they're going to do it all, standing there with tears in their eyes, or worse.
How to make them really like two reliable colleagues, able to naturally dismantle, take over, collaborate on a complex task without human command or a unified strategy, achieving the effect of 1+1>2?
This means that multi-robot systems will achieve both the high efficiency of picking up firewood and the elimination of the three remaining water shortages.
Group collaboration must be one of the key capabilities when robots enter large-scale applications, and it can even be said that it is a must.
Zeno-1, a 3B-parameter base model, was released by Xeno, the first physically intelligent base model designed specifically for decentralized multi-robot collaboration, capable of localized closed-circuit vision at 30 Hz.
Simply put, robots can actually collaborate autonomously to complete tasks from now on!
Let's take a closer look at the details of how these two robots work together.
The first is the movement of the hanger. It fully demonstrates the precision of the actions of the two robots, accurately pulling the hanger through the hanger shelf, connecting the hanger shelf completely naturally, stable, without a bit of excess vibration.
This is a complex task that takes a long time and is a very typical home application scenario. The robot firmly completes the automated decision-making process by inserting an elastic pillow into a transparent vacuum bag, tightening the bag while holding it tightly, and finally sucking the vacuum into its position.
What's even more interesting is that each robot in the demo is actually a copy of the same strategic model, making judgments based on the information they observe. Who to grab, who to cooperate, when to wait, when to take, these collaborative behaviors emerge from the same model of distributed "emergence".
Technical report:
This, along with traditional multi-robot systems that rely on the idea of a centrally controlled, synchronized clockwork, are already two completely different routes.
Technical dismantling: four-phase training of Zeno-1
The core question of Zeno-1 can be summed up in one sentence: how can a model learn to collaborate with its teammates without being told what their teammates think?
There are three reasons why this question is difficult.
First, the dimensional explosion. The two robots each have their own observation space and operating space, and the joint state space expands rapidly as the number of robots increases, and the cross-attention computation between the various intelligent agents increases exponentially. The traditional practice of multi-intelligent reinforcement learning is to train all agents simultaneously in a centralized simulator, but this method is almost impossible on physical robots, as the necessary multi-robot synchronous collaboration data and privileged data are extremely difficult to obtain.
The second is the time-accumulation error. Two robots collaborate not in rotational alternations like chess, but in a continuous, real-time manner. 0.1 seconds of sequence deviation may not be important at the moment, but 5 seconds later may cause the entire task to fail.
Third, partner uncertainty. In real life situations, your partner may hesitate, may slip, may make unexpected moves because of the observation of noise. Any assumption that "a partner will perfectly execute a predetermined trajectory" is bound to be fragile.
Four stages of progressive training
Stage one: Learn the world: Mass video pre-training.
The goal of the first phase is for the model to build extensive prior knowledge of the physical world.
Zeno-1 pre-trains on large-scale video data to learn the basic laws of the physical world: how objects move under the influence of force, what happens when contact occurs, how flexible objects shape when captured, and how fluid flows when poured.
This step does not involve robot control at all, as the model observes a large number of physical interaction videos of the real world like a "bystander", extracting general physical precedents such as movement, contact, transformation, causation. These precedents provide the basis for a subsequent stage: the model does not need to learn from scratch "object will fall" or "force over the assembly to overturn things", which are already encoded in the pre-training stage.
The second stage: learn your own "single-body" training.
The physical intuition acquired from video pre-training is general and cannot directly drive specific robot actions. The second stage is to land these general priorities on specific robot bodies.
At this stage, single-piece robots train in real environments, transforming pre-trained vision - physical precedence - into concrete perception - decision-making - execution ability. The model learns to extract task-related characteristics from its own visual observations and physical states and maps them into a coherent whole-body sequence of movements.
After this stage, the Zeno-1 as a single unit already has basic capabilities such as agility, tool use and mobile interaction.
"Become a qualified individual and then be qualified to collaborate".
The third phase: learning collaboration, closed-loop partner interaction, CPI. This is the core innovation of Zeno-1.
The traditional path is to collect large amounts of multi-robot collaboration demonstration data and then to simulate it with supervised learning. But this path is almost impossible: you can hardly allow two real robots to mass-produce high-quality collaboration data in real environments without cost and efficiency.
CPI is a completely different way of thinking. It allows two independently running robots to train each other as partners. Each robot acts independently based on its own observations, and its actions change the shared physical environment, thus affecting the next decision of the other robot.
It is worth mentioning that in CPI training, the partner itself is an autonomous person who is learning, and its behavior is inherently imperfect: sometimes fast, sometimes slow, sometimes mistakes.
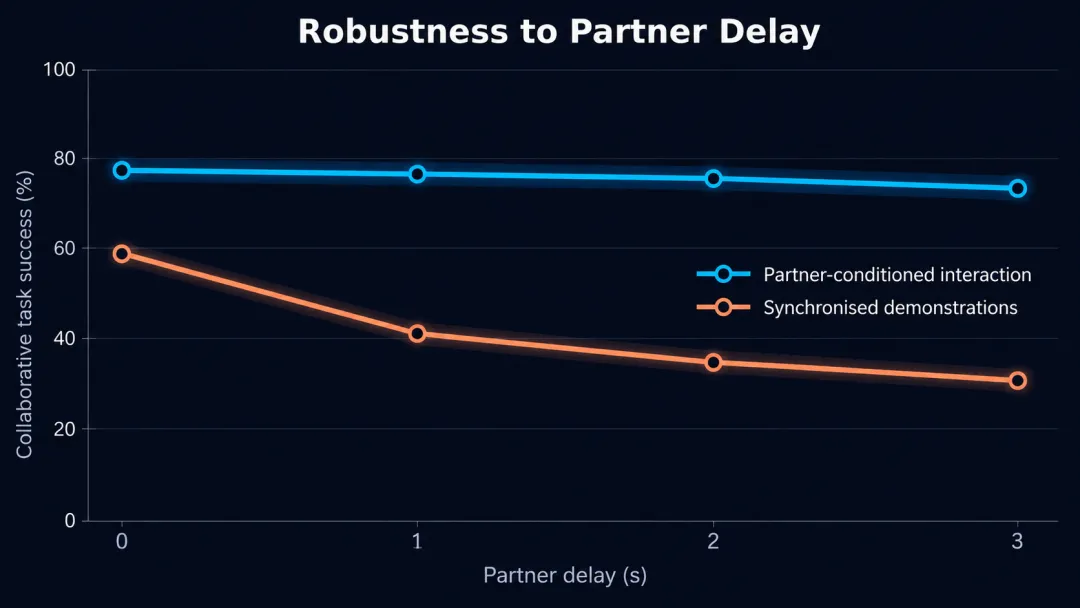
Zeno-1's deployment of robustness is particularly evident when we attempt to disrupt the timing of the actions of collaborative robots. Zeno-1 maintains coordinated collaboration even in the face of rapid delays that could cause a strategy based on synchronous demonstration training to fail.
Through CPI training, Zeno-1 learns a range of specific collaborative adaptation behaviors: slowing down, waiting, concessions, maintaining contact, re-calibration timing, and then returning to normal rhythms when interactions become compatible again. These behaviors emerge entirely spontaneously from closed-loop interactions.
Phase 4: Targeted correction of failure of collaboration
The practical approach is to observe the collaborative processes of robots in real deployments, identify critical moments when the collaboration makes a problem, and then provide corrective demonstrations by operators around these critical moments, which are supplemented with training data.
The key mechanism is that in the final step, the model does not learn all experiences uniformly, and it will invest more learning resources where collaboration is most likely to go wrong.
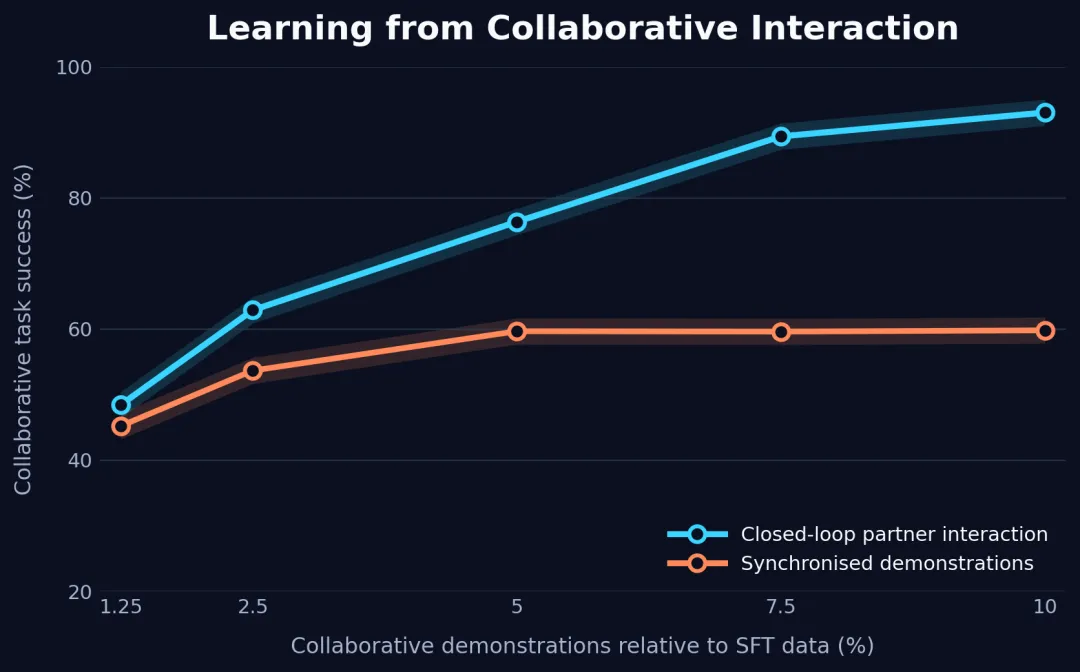
Increasing the ratio of closed-loop partner interactions in the process of collaborative adaptation is significantly better than the effect of adding synchronous multi-robot demonstration data.
Specifically, the training process is as follows:
Step 1: Two robots are placed in the same physical environment, each loading a strategy trained through the first two stages.
Step 2: The two robots act independently according to their respective observations. Robot A's actions change the shared physical environment, which changes the environment into B's next series of observations, affecting B's decisions, and vice versa.
Step 3: As the interaction progresses, the timing rhythms, movement trajectories and contact forces of the two robots need to be continuously adapted to each other.
Step 4: The system identifies the moment of collapse of the collaboration. When the collaboration fails, these failures are marked out and the model is trained at these critical moments.
The two robots "co-evolute" in continuous interaction, learning to collaborate through real collaboration rather than "imitate" collaboration by watching human demonstrations.
Two key subsystems: persistent interactive memory and predictive memory
In the demonstration video, we find that robots can accomplish long-range tasks smoothly. That is, in addition to the CPI, Zeno-1 has two other subsystems that make long-range collaboration possible.
Zeno-1 robot demonstration of long-range missions
Persistent Interaction Memory, also known as Persistent Interaction Memory.
Multi-robot collaboration tasks typically span minutes or even more than 10 minutes. On this time scale, purely reactive strategies lose a significant amount of critical context.
Zeno-1 solves this problem with a learning memory module. This module is updated every step of the way, maintaining a compressed interaction history. It encodes three types of information:
Mission Progress: At what stage is the current mission and which sub-goals have been completed.
Partner behaviour patterns: recent trends in partner movements, whether they are slowing down, accelerating, changing strategies.
Shared physical state evolution: how object configuration changes, how contact points migrate.
According to dissolution experiments, lasting memory is critical for collaborative tasks of more than 3 minutes. After removing the module, the model's performance on long-range tasks deteriorated significantly.
A robot without a lasting interactive memory is a purely "goldfish" memory, with every step judging the situation from scratch and unable to absorb the accumulated interactive experience.
It is also known as Predictive Introspection.
This mechanism allows Zeno-1 to "go through the brain" before performing the action.
At the level of partner interaction, a move may seem optimum locally, but it is sub-optimal from a team standpoint if it causes the partner to be placed at a disadvantage.
Zeno-1 will evaluate the potential impact of each candidate's action on their partner's follow-up behavior. Based on the evaluation data in the technical report, in the retention of test sets:
Zeno-1 has an 87% probability of choosing the best follow-up moves in collaborative decision-making.
In contrast, after removing the partner behavior prediction module (taking into account only the immediate effect of the action), the proportion dropped to 61%.
"Thinking for a partner" is not just an added bonus, but a key determinant of collaboration quality.
At the physical contact level, Zeno-1 incorporates an Action-Conditioned Latent World Model to predict how the physical state of sharing will evolve after an action is performed.
Its core function is to identify possible failures before an action is performed: catch errors, slide, grab unstable and object disruption.
The team tested the world model in 200 real-world robotic experiments, where the predicted AUC for contact failure reached 0.94 within the 0.5 second warning window, compared to 0.81 based on current observational predictions alone.
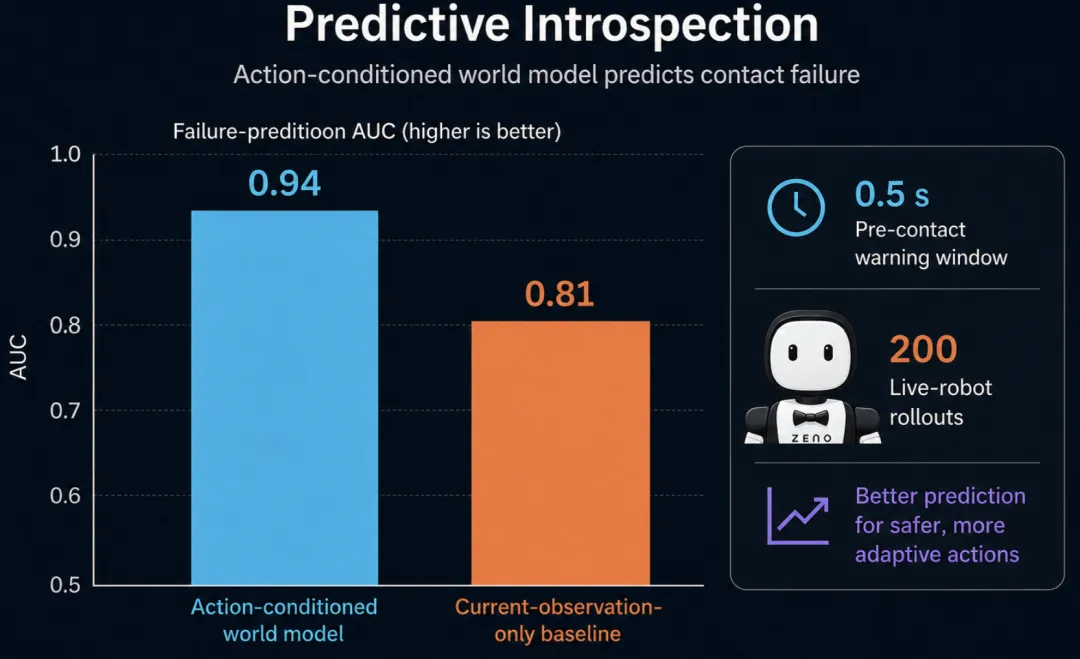
Zeno-1 can predict an impending failure 0.5 seconds before contact.
Simply put, it can prevent collaboration errors. Zeno-1 can consider both "the action is not good for the partner" and "the action will physically fail".
1+1>2, starting point for multi-robot collaboration
The collaboration of robots seems to be a unified control, but why does Xeno insist on decentralization?
Extensibility. The combined action space of a centralized controller expands with the robot number index. Assuming that each robot's action space dimension is d, N of the robot's combined space is d^N. Under the decentralized architecture of Zeno-1, adding one robot requires only loading a copy of the same strategy, without having to redesign the controller or redistribute the combined action space, calculating linear growth.
In a decentralized system, each robot makes an independent decision and the failure of a single node does not spread to the entire team.
This feature is very practical. You don't need to deploy a full team of robots all at once, but you can increase capacity on demand.
In the real world, a lot of work naturally needs to be done in collaboration. An industry analysis by the Tencent Cloud Developer Community indicates that in the second half of 2026, the smart body is entering the "reconstruction of flexible workstations" phase: single-piece robots will be able to work again, and the production lines that require multitasking collaboration will still be unmanageable.
The answer is: the physical world itself.
In Zeno-1's technical pathway, "the shared physical world is itself a coordinated interface". Each robot is created naturally by observing the environment and the behavior of other robots, judging the progress of tasks, understanding the state of the collaboration, and adjusting its next steps accordingly.
The academic community has also begun to move in a similar direction. In June this year, a team at Stanford's Chelsea Finn, Jeannette Bohg, proposed a method called CHORUS, which proposed decentralized multi-bot collaboration based on a single VLA policy.
The industry has also begun to see collaboration as an important next-generation capability. Figure's Helix 02 and Google DeepMind's Gemini Robotics 2 have both clearly demonstrated or emphasized multi-robot collaboration, indicating that collaboration is gradually entering the core capability definition of a robot-based model.
An increasingly clear trend emerges: the basic robot model is moving further from the ability of a single entity to collaborative intelligence.
Zeno-1 proves at least one thing: collaborative physical intelligence can be achieved in a single decentralized strategy.
When robots really learn to observe each other, understand each other, and work together as colleagues, 1+1 begins to be really bigger than 2 and the limits of the entire robotics industry opens up.
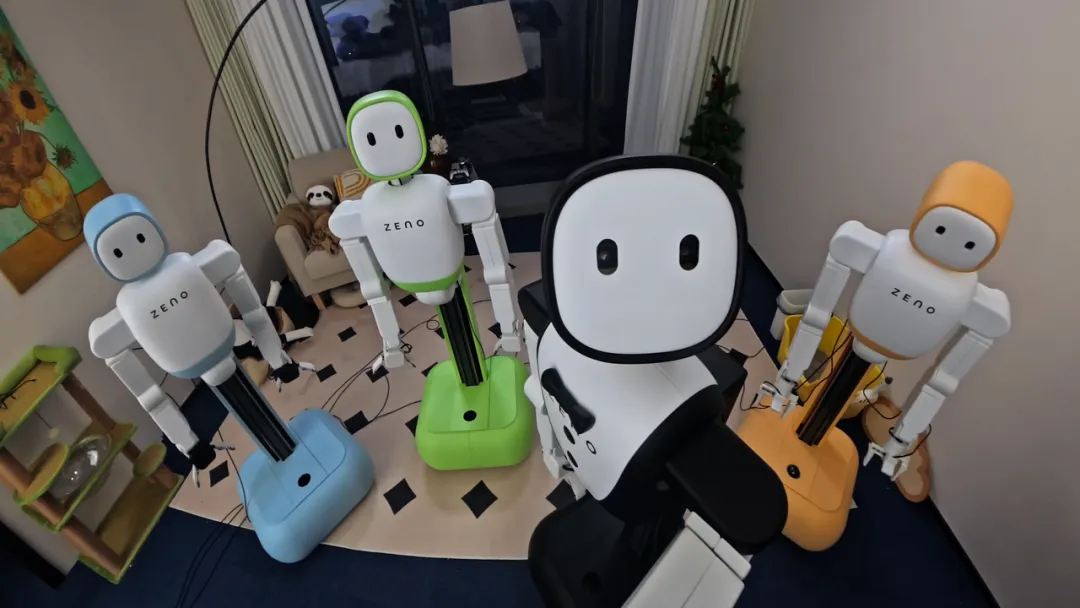
From a distance, a civilized world with a lot of robots is coming to us.