Traditional 3D Gauges are rebuilt following a fixed model: relying onMultiple images, SfM camera labels, multiple view frequency constraintsGenetically optimized Tom MiGOS, native 3DGS fully follows this framework. The program requires reliance on multiple viewpoints and known camera parameters, and the collection and pre-processing processes are cumbersome, making it difficult to achieve rapid modeling of single graphs.
Monograms unmarked by Humphreys rebuilding subverting traditional rebuilding logicRepresentative work includes:Splatter Image、Flash3D、Gamba、DreamGaussian• Simply input single-disc RGB images without multiple view materials, external labeling and COLMAP processing, and use pre-trained 3D forecasts or scattering to generate forecast projections of shading area structures, directly generating dense 3D gauges from end to end.
The technical routes are mainly divided into two categories:Direct ForecastSpeedy reasoning, but big view projection is easy to misrepresent, is represented by Splatter Image, Gamba, Flash3D; another category isOptimization of generated ancestryIn the DreamGaussian series, the structural integrity behind objects is better, with the disadvantage being that reasoning takes longer. It needs to be clear: the reasoning phase is not labeled, and does not represent the training phase abandoning the geometric constraints of projection.
This direction breaks down two inherent cognitions: overthrowing reconstruction must rely on the consensus of observations from multiple viewpoints to get rid of it.Cameras marked for forced entryThe limitation is to convert the time-consuming scenario reversal optimization into an instantaneous forward generation mode.
There is still a clear bottleneck in the current scheme: single-chart natural existenceDiscrimination on the scaleIt is not possible to directly obtain real physical dimensions; large angle shifts are easy to cause structural variation; the shading region relies on model drift, geometric accuracy is lower than multi-view reconstruction, and is a common problem with existing mainstream methods.
At the application level,Montoya Microgas significantly lowered the threshold for making 3D assets3D Gaussian models that can be rendered in real-time by taking a single-touch photo, adapted to instantaneous reconstruction of mobile devices, rapid production of AR content, and the elimination of complex image sequencing and SFM processes, opening up new directions for lightweight 3D reconstruction.
So how do we learn from the latest technologies such as SLAM, 3D reconstruction, physical intelligence, and so on?"Three-D Vision from Inception to Enlightenment"In addition to learning about SLAM and 3DGS, there is also information on self-driving, intelligent, unmanned aerial vehicles, and machine arms clutching.
Many fans ask the following questions:
"Three-D vision from inception to mastery" is the planet of knowledge, inside.What's in it?Is it possible to study video lessons to join the planet?What are the rights of members?The following details will be given to you: (Note: After adding the browser, you can log in to the Knowledge Planet APP/WeChat at the end of the web page to enter the planet)
Today, let's talk about this sadness together.Almost nine years3D visual technology circles.
One, what is a planet of knowledge?
Knowledge Planet is a highly active community platform where you can explore the challenges of research work with small partners from the same research direction, share the latest developments in the field, share 3D Vision's latest summit papers & code information, share videos, explain 3D Vision's important knowledge points, publish high-quality job information, undertake projects, etc.
2nd, 3D vision from entrance to awareness.
Currently, there are nearly 6,300+ active members, mainly involved in the areas of industrial 3D vision, SLAM, autonomous driving, 3D reconstruction, drones, physical intelligence, large models, and technology fronts.
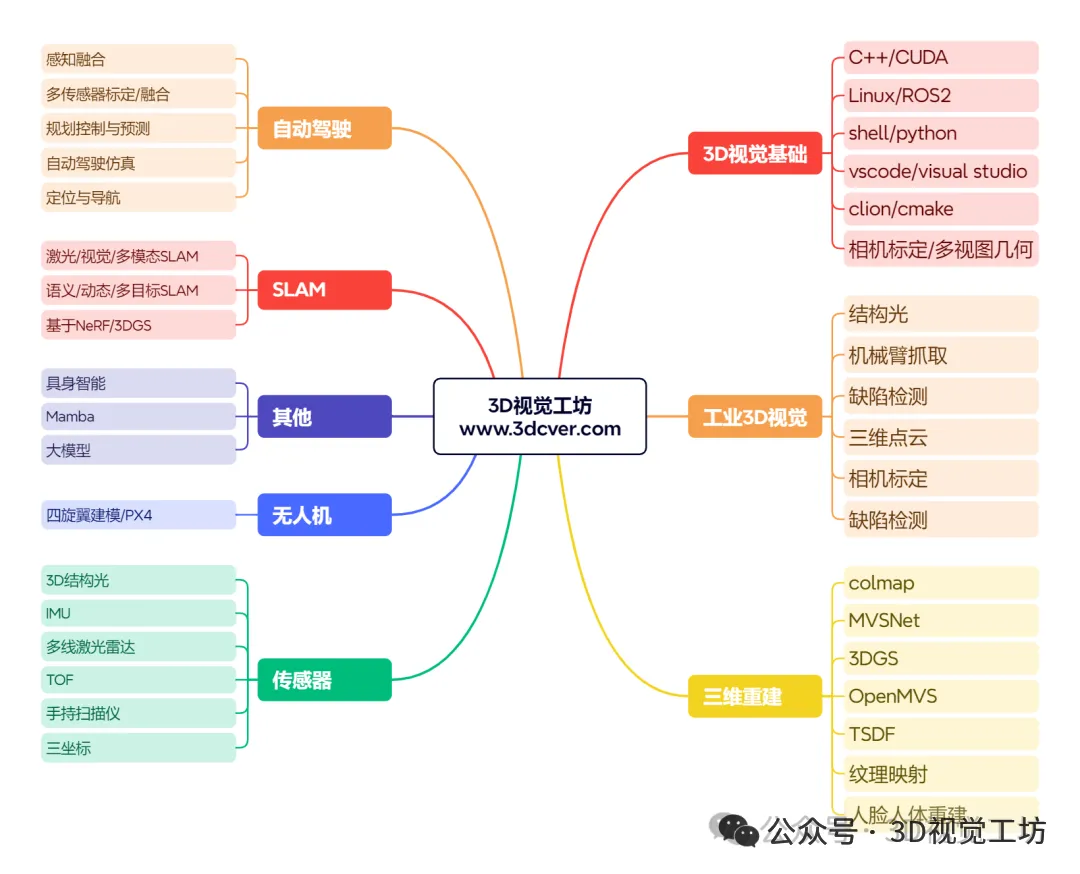
There are many sub-disciplines, including but not limited to: industrial 3D vision, 3D reconstruction, autonomous driving, physical intelligence, large models, widespread models, and technology fronts, including visual competitions, hardware selection, visual product landing experience sharing, academic & job exchange, etc. We also keep up with the latest cutting-edge technological developments and are a hot topic of discussion on our planet.
| Features | ||
|---|---|---|
| The earliest in the country | Nearly 20 video clips | 3D visual excellence answers |
| The latest summit papers and code sharing | 3DGS exclusive series of videos | Professional think tanks responding to confusion |
| The latest cutting edge technology workshop | Connecting high-quality projects | Source code for each module |
| The latest industry recruitment information | Applications for a job | Research and life spit |
| Sharing the latest industry modules | Ask questions at any time | Monthly Cash Rewards for Accounting |
Summary of the entire series of video tutorials across three planets
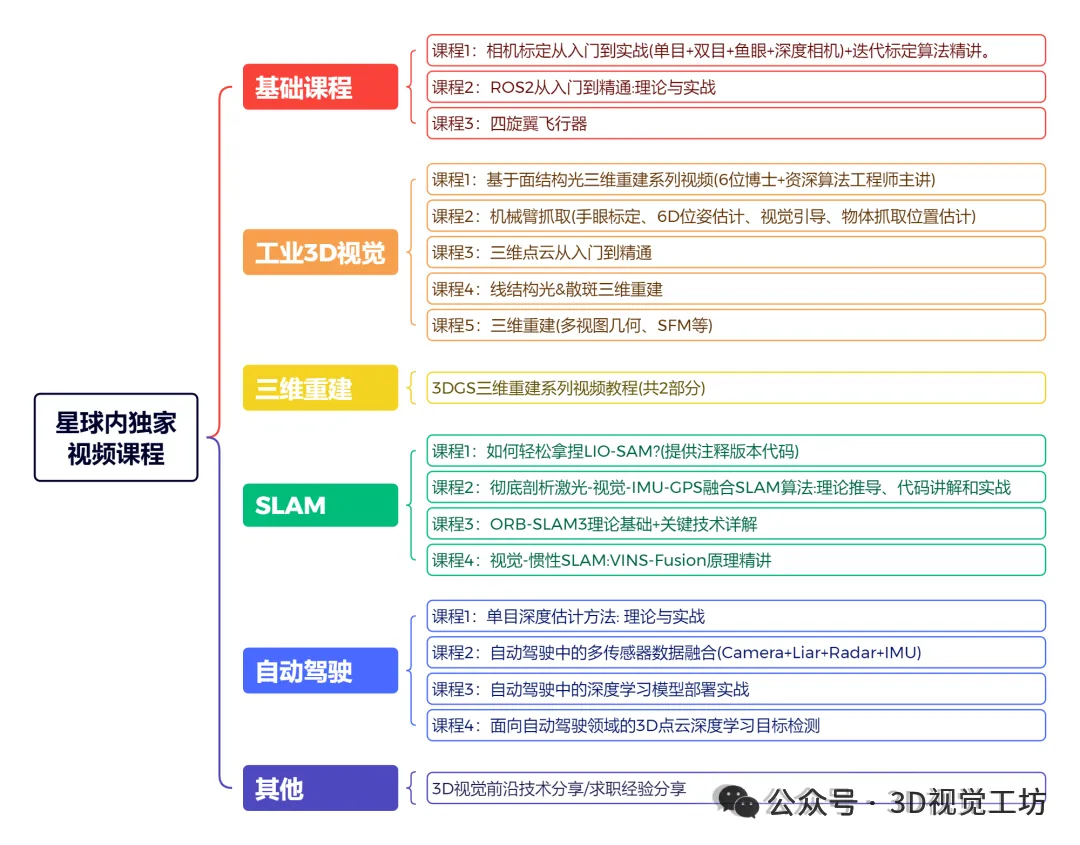
Video tutorials are divided intoTwo large platesThe first block is:Core core curriculumWe've thoroughly honed nearly 20 series of video tutorials, content systems, step-by-step, and more importantly, what you've learned about 3D visual technologies like industrial 3D vision, SLAM, 3DGS, autonomous driving and drones, which we'll cover in more detail below.Technology sharing at the forefrontIn a special event, industry leaders and academic leaders were invited to share live content covering top trends such as physical intelligence, autonomous driving, 3D reconstruction, digital people, distributed modeling, 3D generation, and others. This section is not focused on the content and is no longer discussed in detail.
| Video tutorials from the mainstream (mainstream) | |||
|---|---|---|---|
| 3DGS series | 3DGS-SLAM | Cameras are marked | ROS2 |
| Quad flyers | C++ | Facial structural light | The mechanical arm grabs |
| 3D point clouds | Linear structural light | LIO-SAM | Integration of SLAM algorithms |
| ORB-SLAM3 | VINS-Fusion | Multi-sensor integration | 3D target detection |
| One-point depth estimate | Models deployed in real combat | This section is continuously updated | |
3DGS exclusive video tutorials
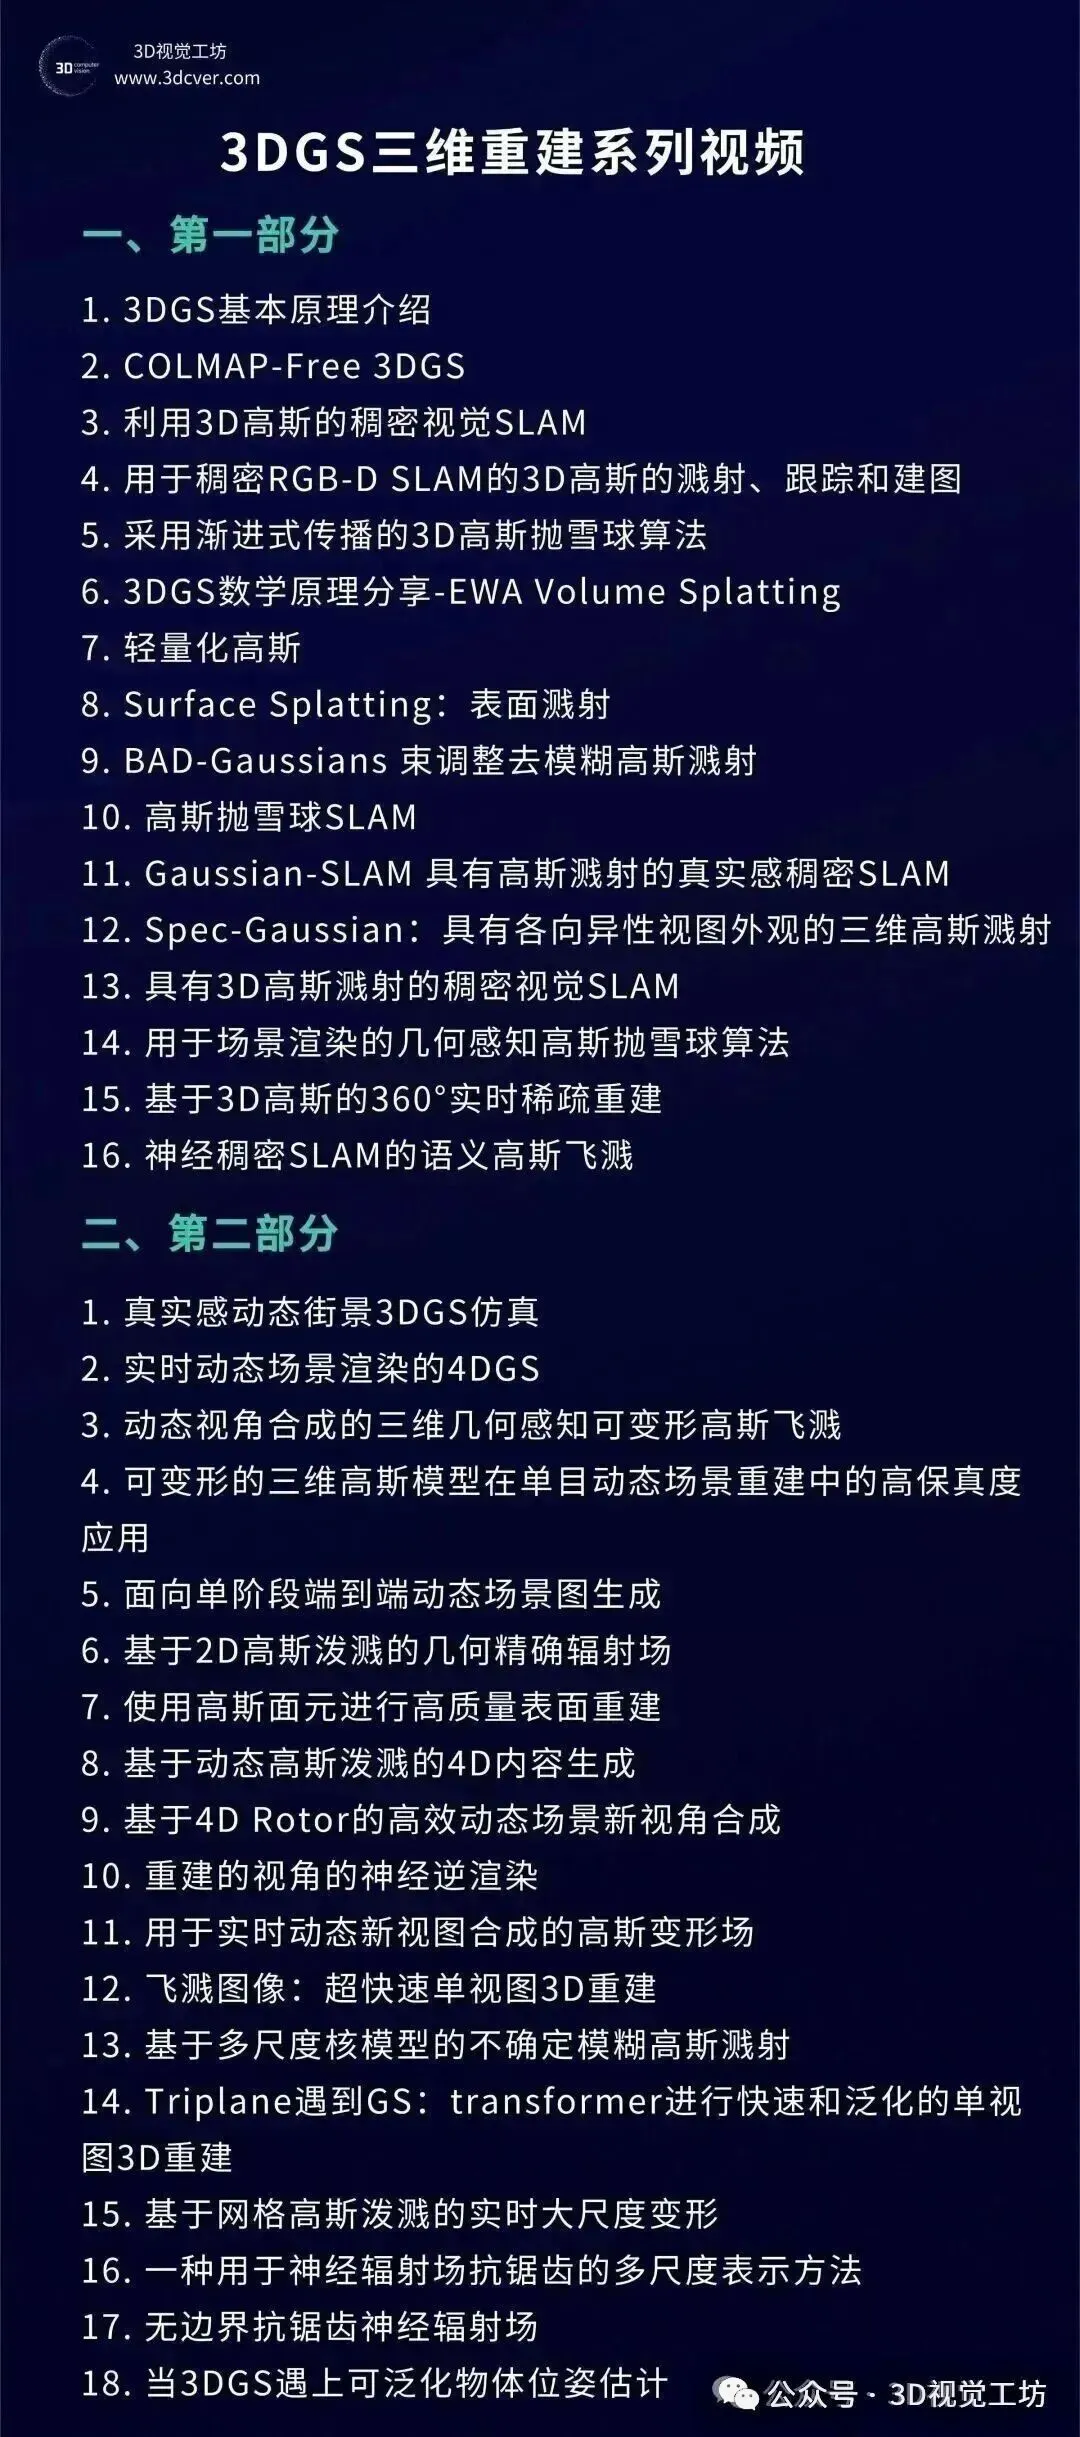
3.0.1 3DGS 3D rebuilding series video tutorials
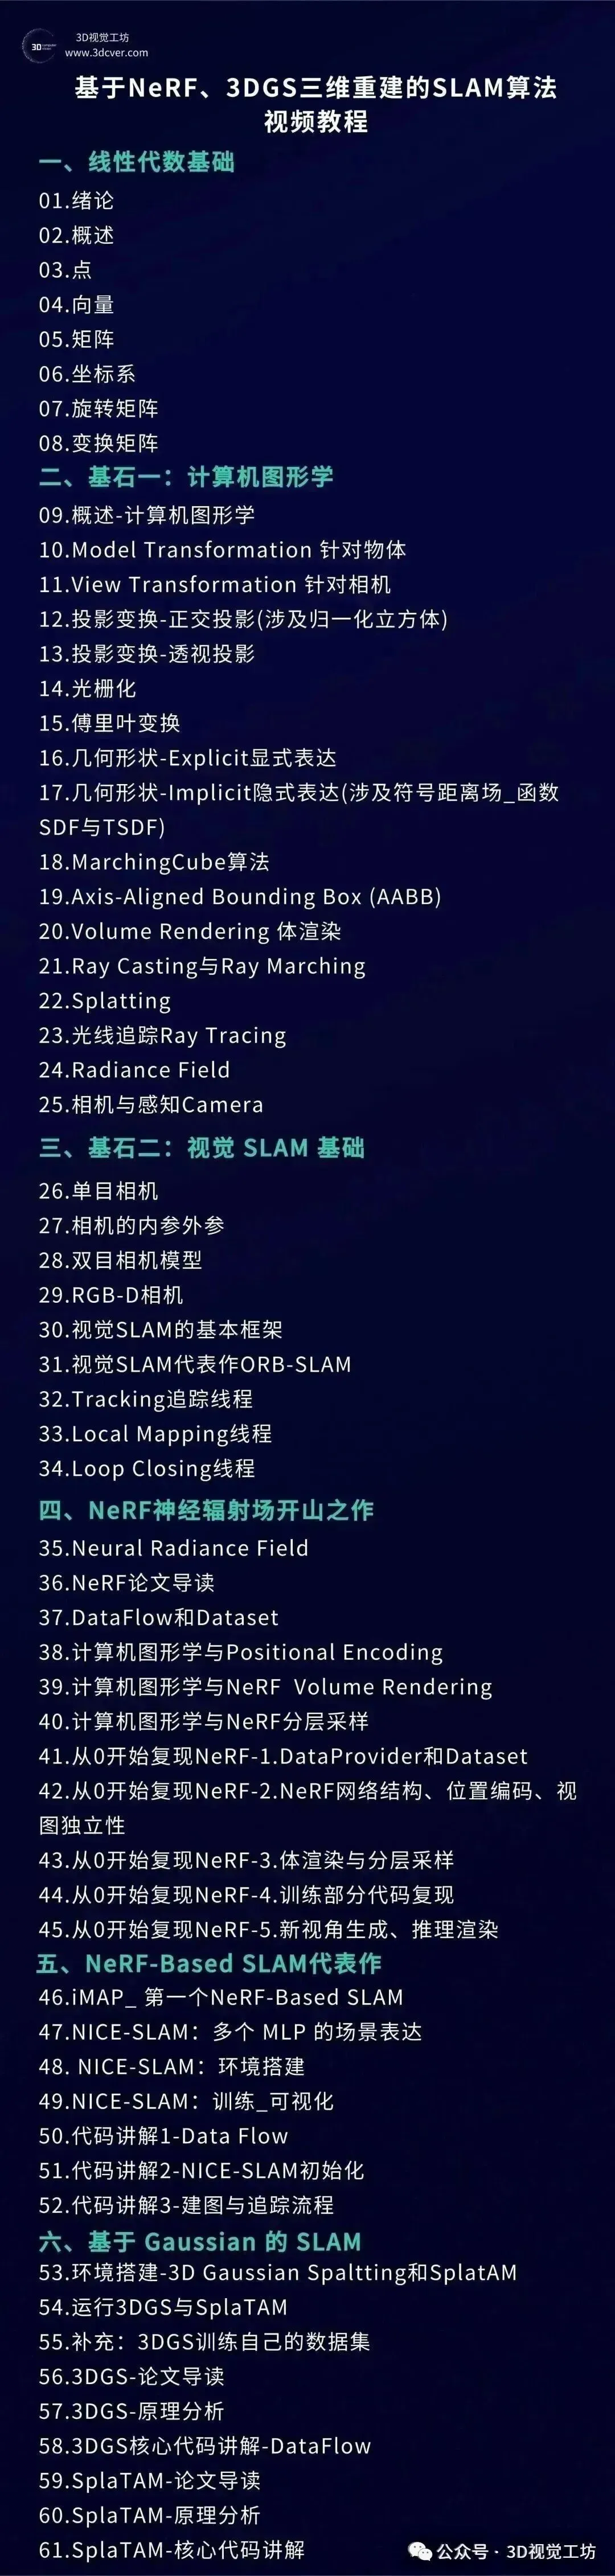
3.0.2 SLAM algorithm video tutorials based on NeRF, 3DGS three dimensional reconstruction
This video tutorial takes you from theoretical and code realization to learning the principles of zero-entry NeRF/Gaussian Based SLAM, reading papers, coding, etc. Theoretical level, from linear algebra to traditional computer graphics, gives you a glimpse into the theoretical foundations and sources of modern 3D reconstruction; the code level teaches you how to reproduce computer graphics, NeRF-related work through multiple hands-on exercises.
3.1 Basic courses
3.1.1 High-precision camera calibration from theoretical to practical combat system instruction
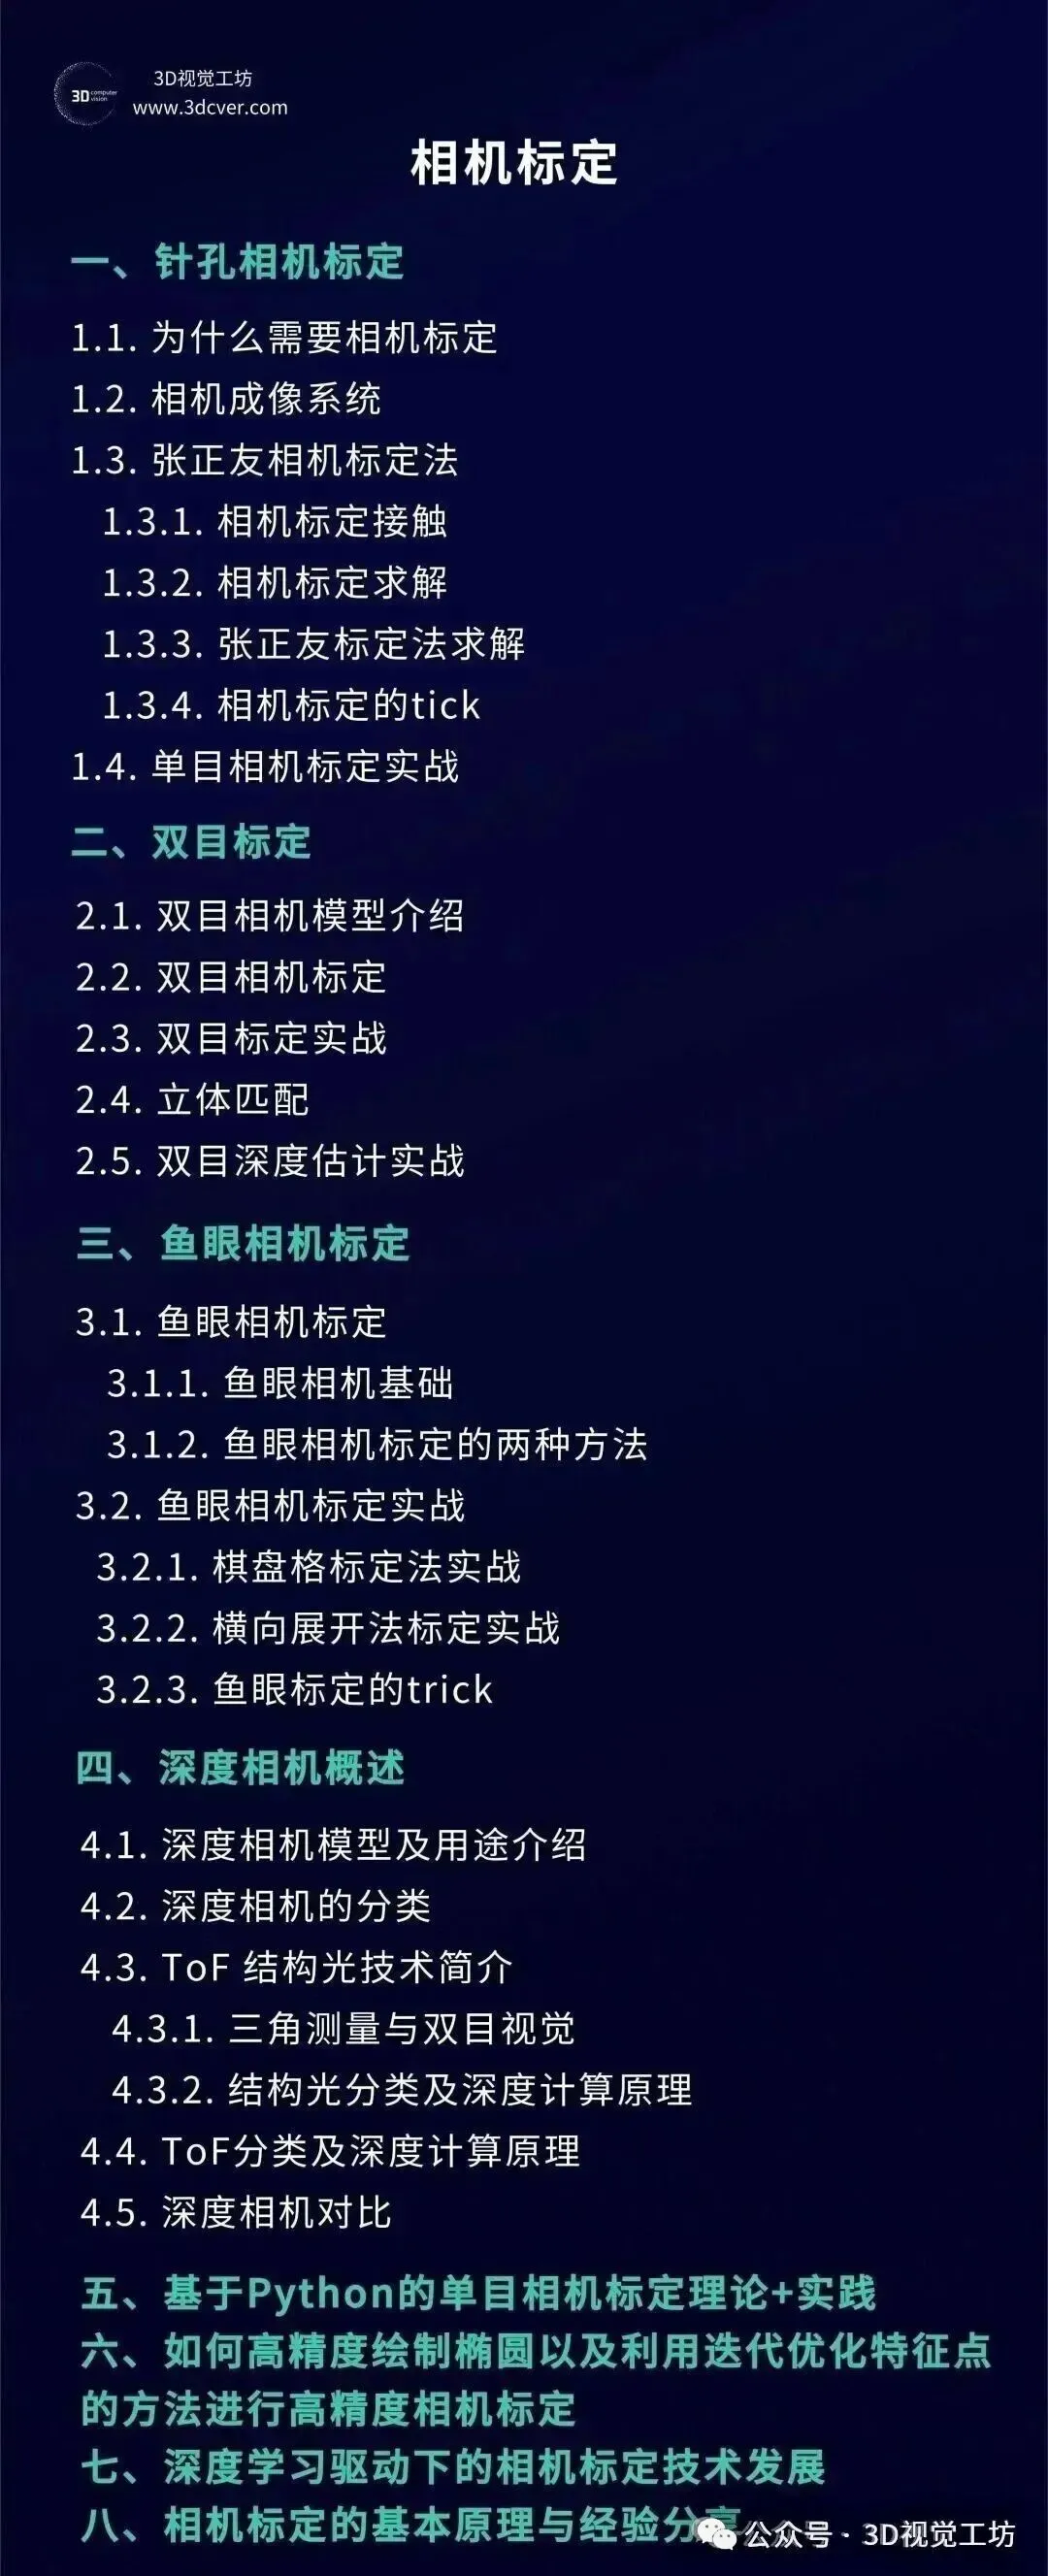
This course mainly consists of two parts: camera labelling and 3D vision; camera labelling includes single-eyed, double-eyed and fish-eyed camera labelling; 3D vision includes stereo vision, structural light and TOF, based on stereo vision.Courses provide corresponding data and code。
Highlights of the CourseIn addition to the basic principles and code that the camera labels, the planet also adds:High-precision camera-labeled improved methods and real-world warfare techniques, which are quite hardcore.。
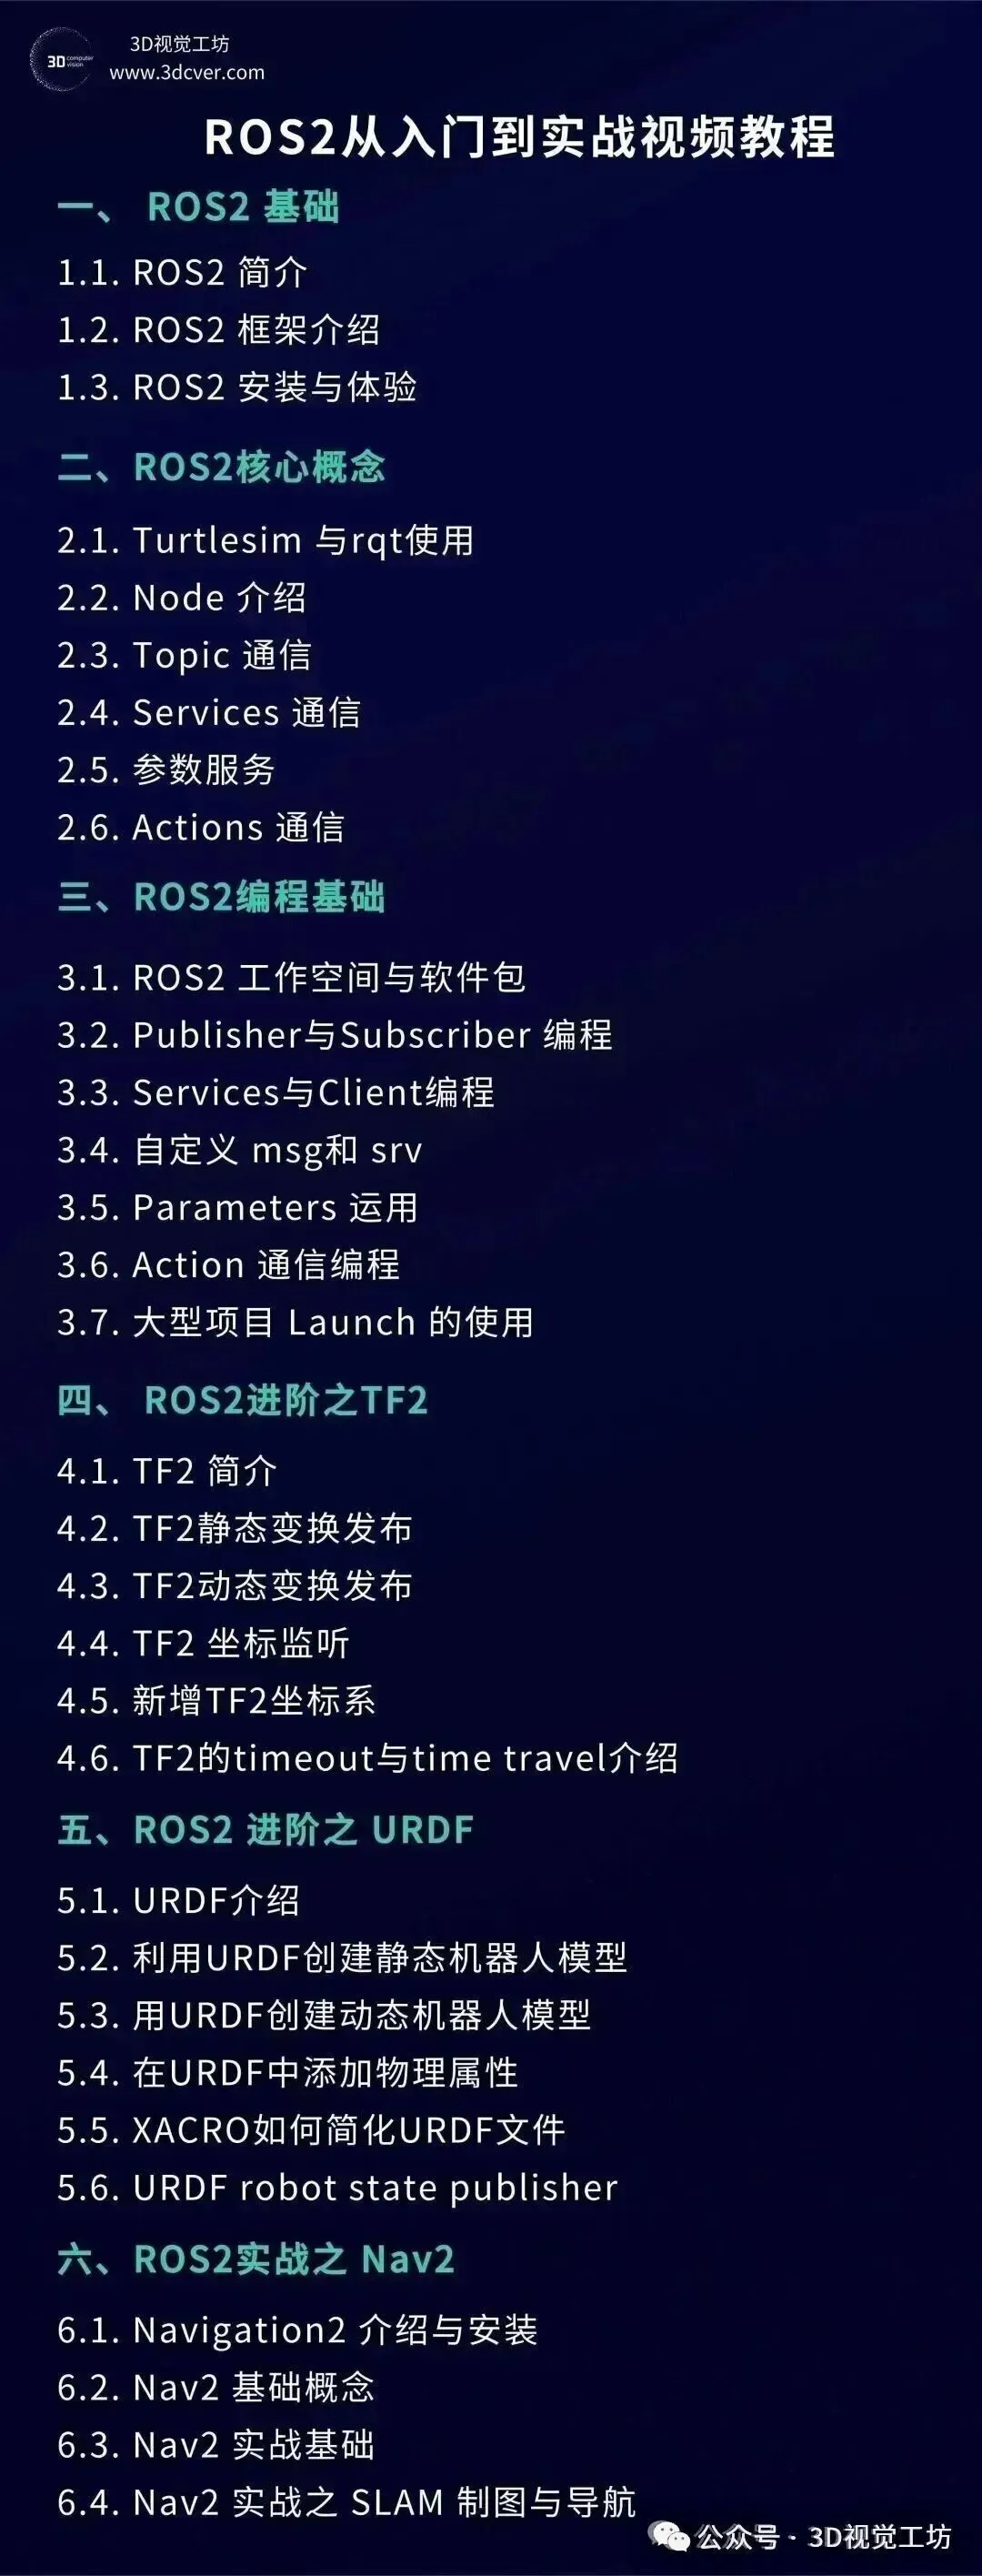
3.1.2 ROS2 from entry to live video tutorials
ROS2 provides a comprehensive hands-on instructional training on ROS2 from entry-level to real-world video tutorials, introductions and high-level presentations, and systematic learning opportunities for all.
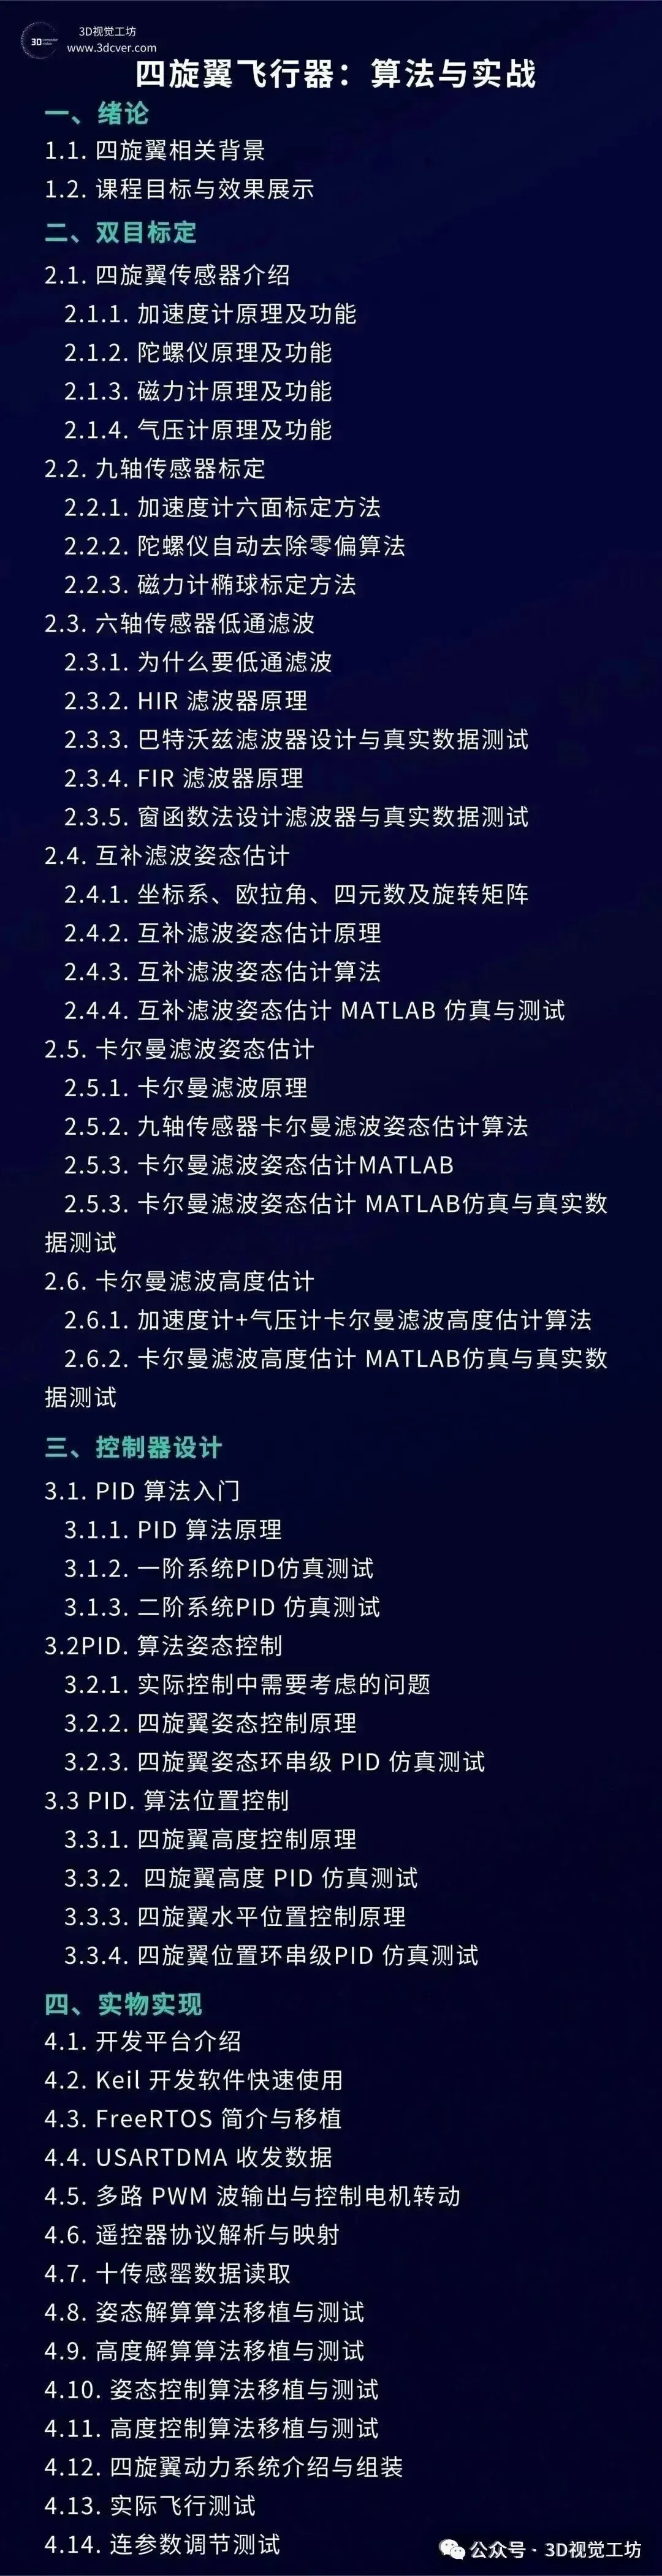
3.1.3 Quad Flyers: Algorithms and Combat
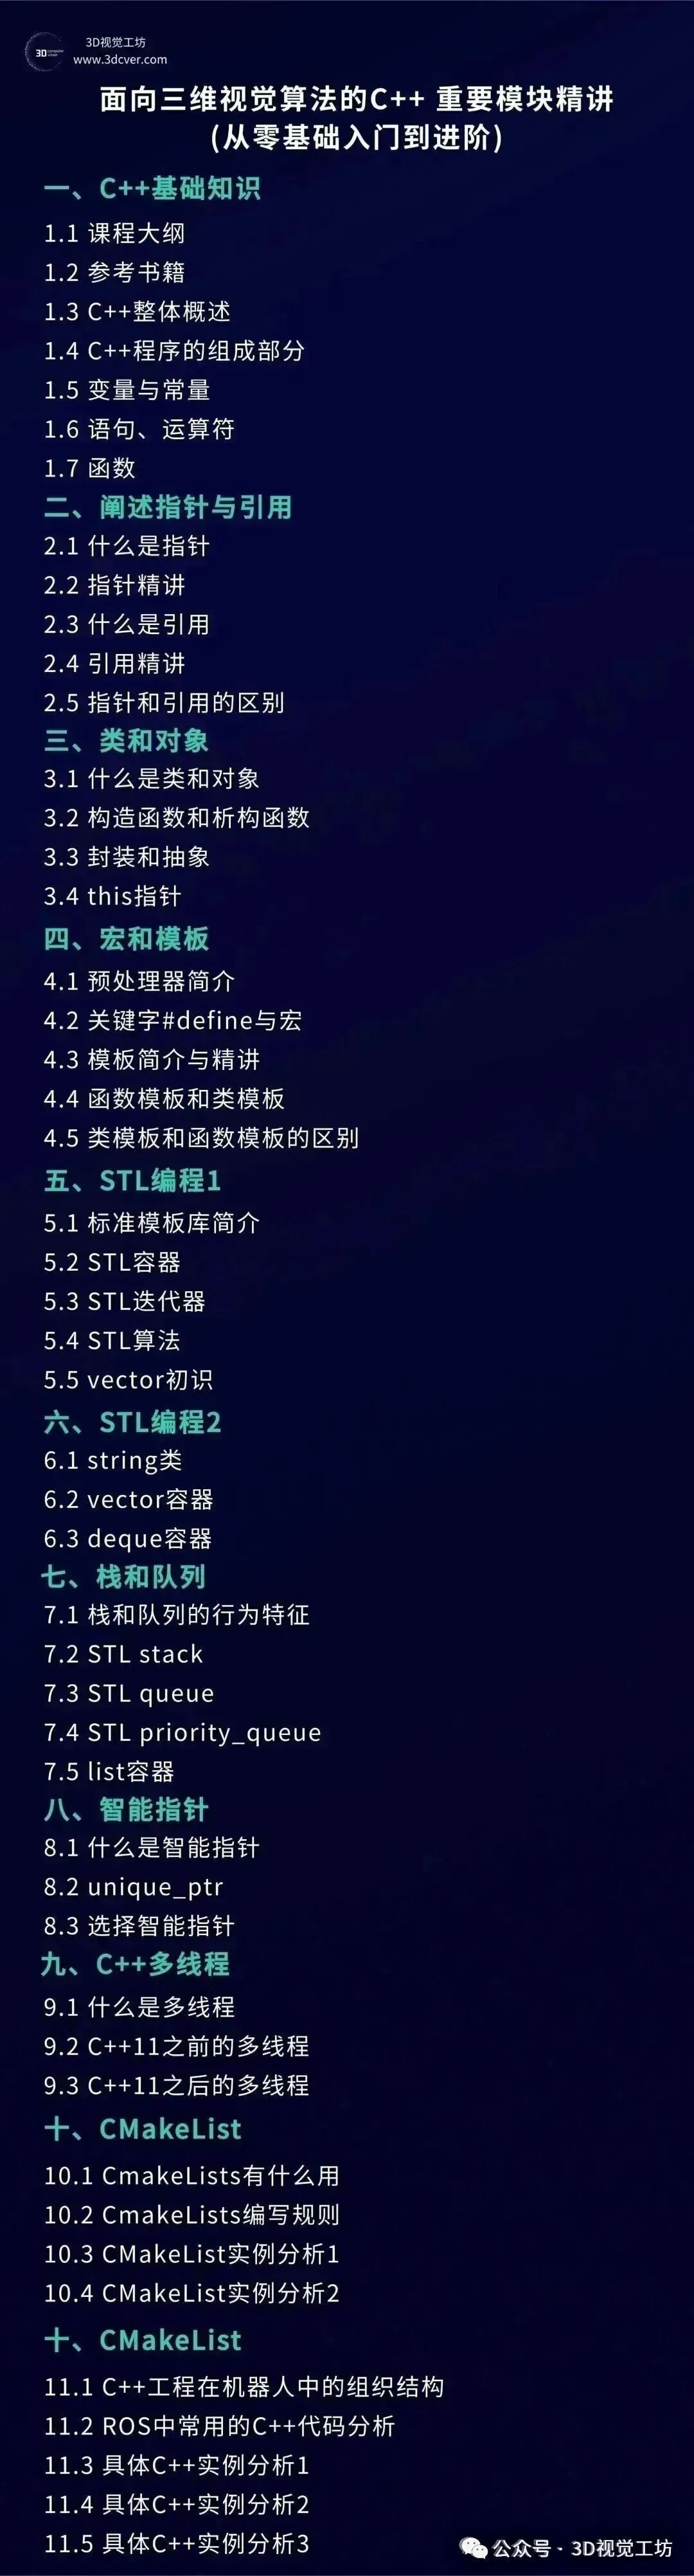
3.1.4 C++ goes from zero-based to advanced
Try to learn through video tutorials, fully understand some of the more difficult modules in C++, master algorithms such as SLAM, learn C++ related job interview skills.
3.2 Industrial 3D visual series video courses
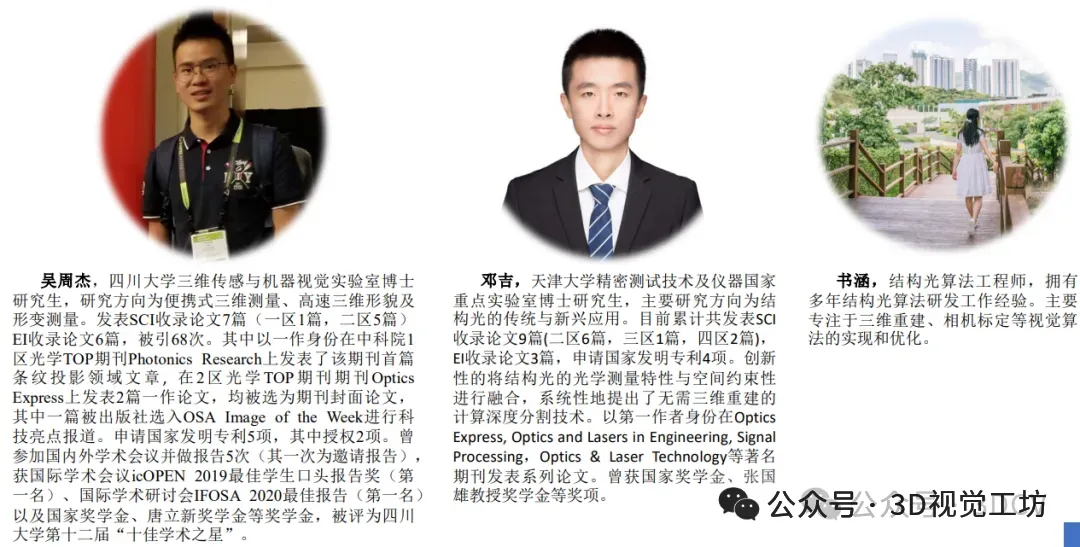
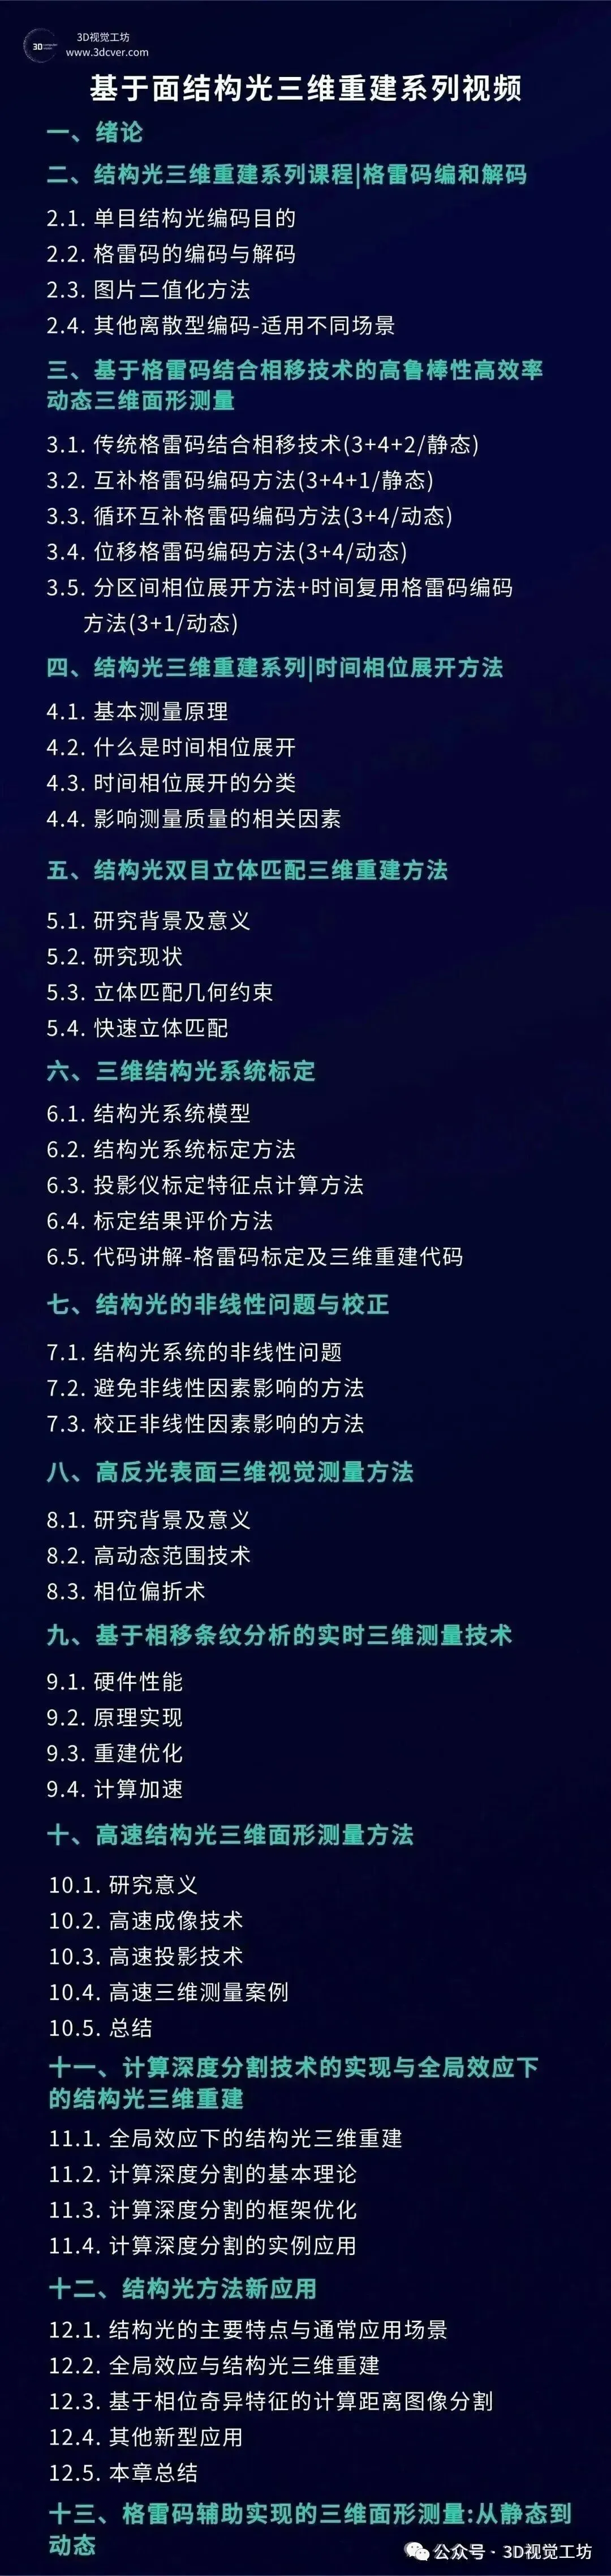
3.2.1 3D reconstruction of video series based on facial structures
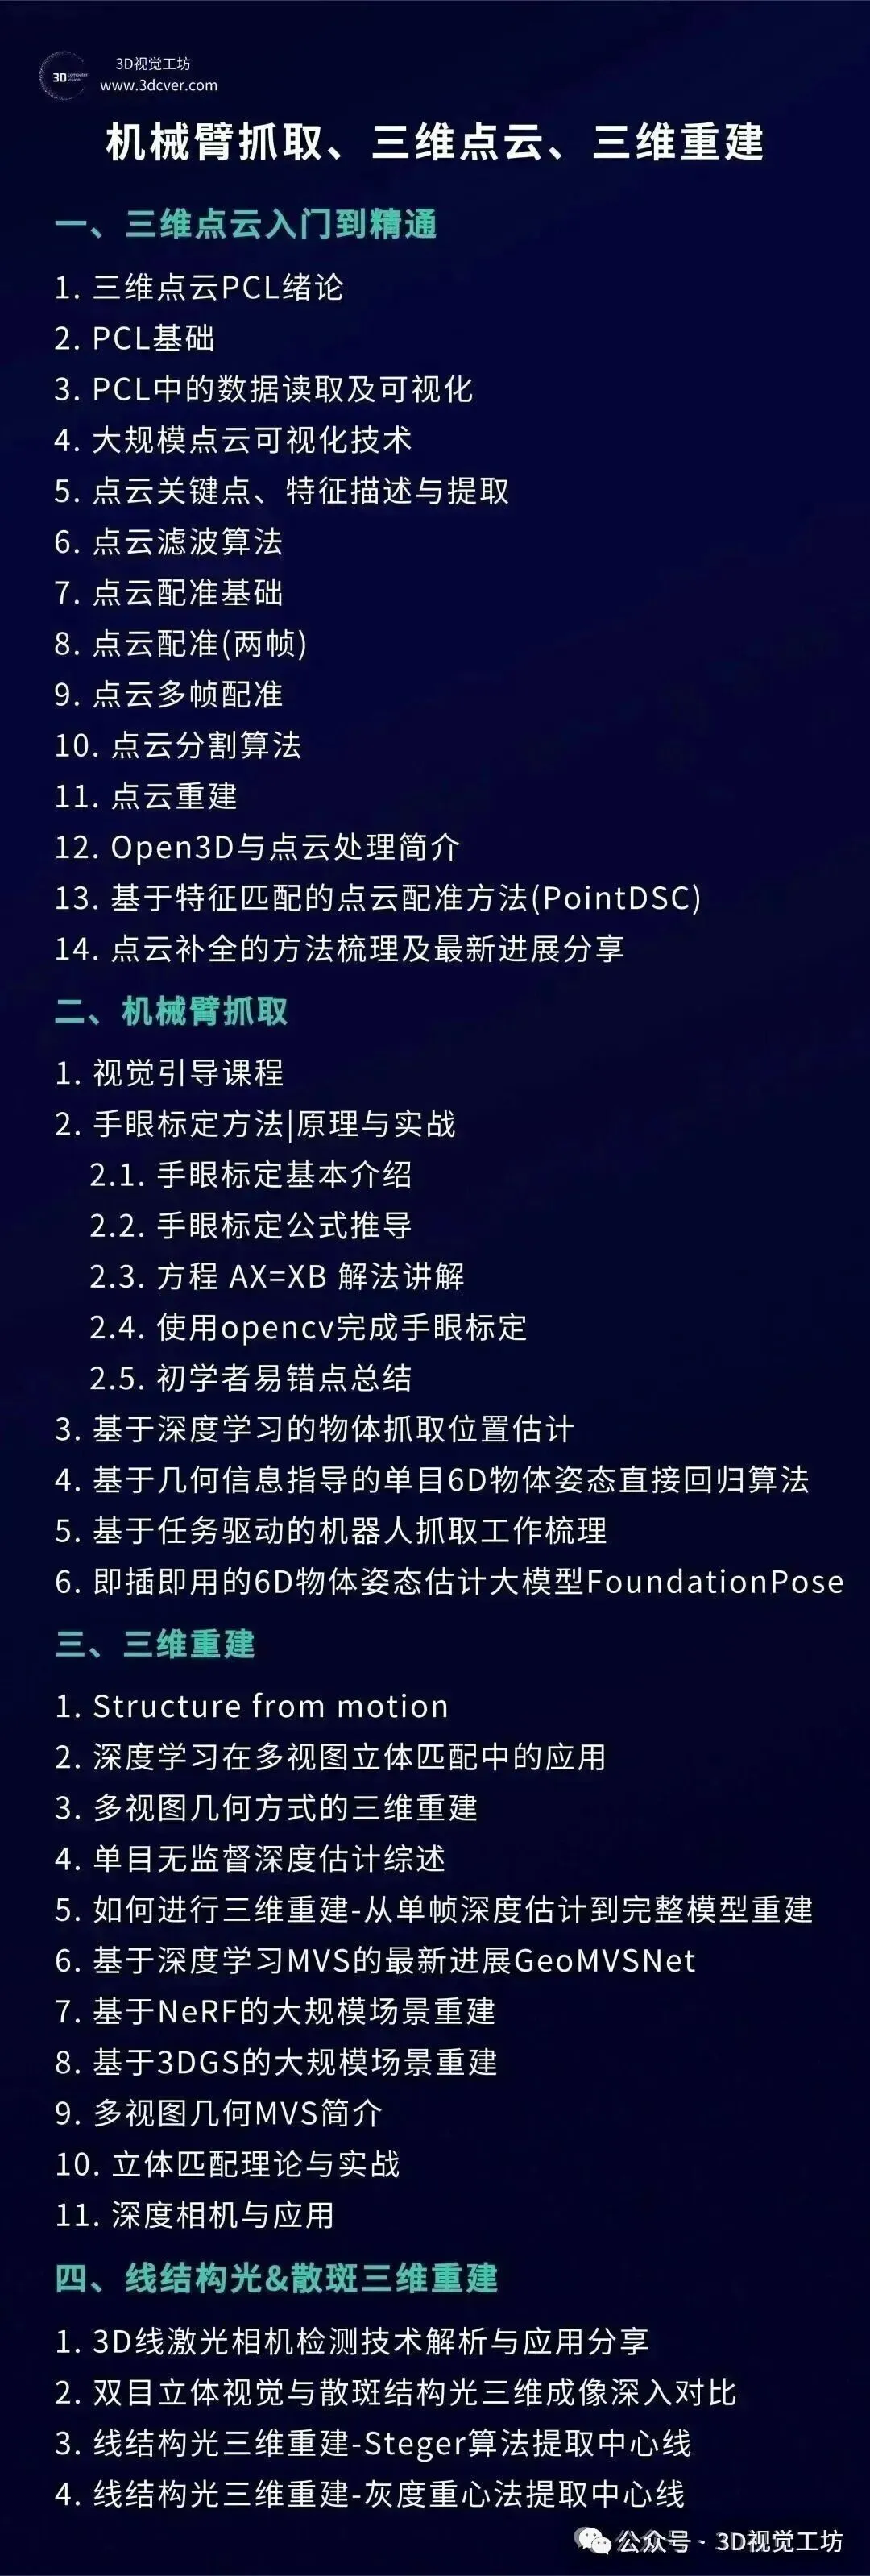
3.2.2 Mechanical arm grabbing, 3D point cloud, 3D reconstruction and so on
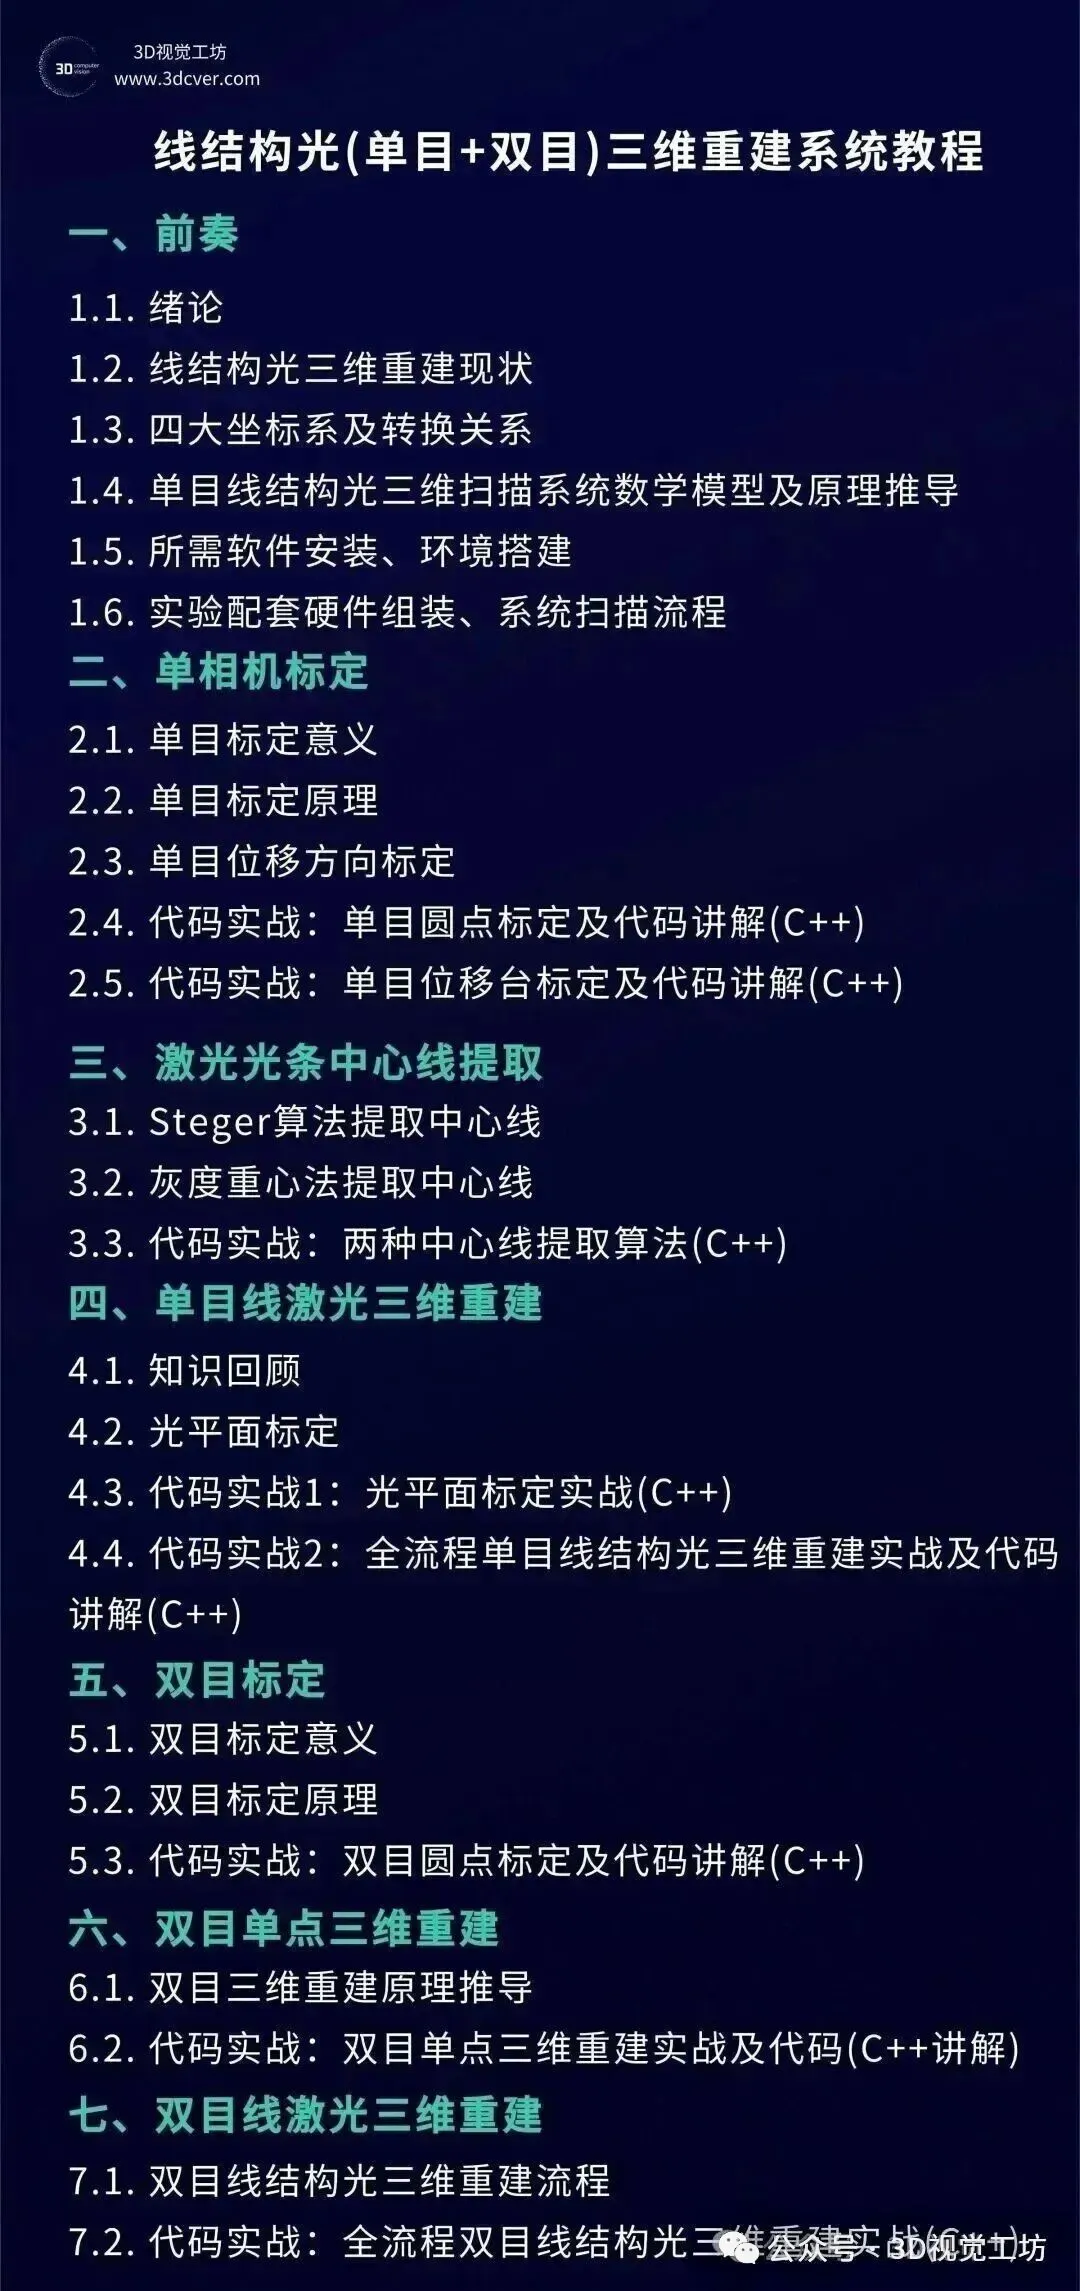
3.2.3 Linear structural light (single) and three-dimensional system reconstruction tutorials
This course focuses on real-world warfare instruction, hand-in-hand with the implementation of a linear laser 3D scanning system of its own from scratch. Almost every chapter is equipped with corresponding lectures and codes to help you better understand the technology of linear laser 3D reconstruction.
3.3 SLAM series of videos
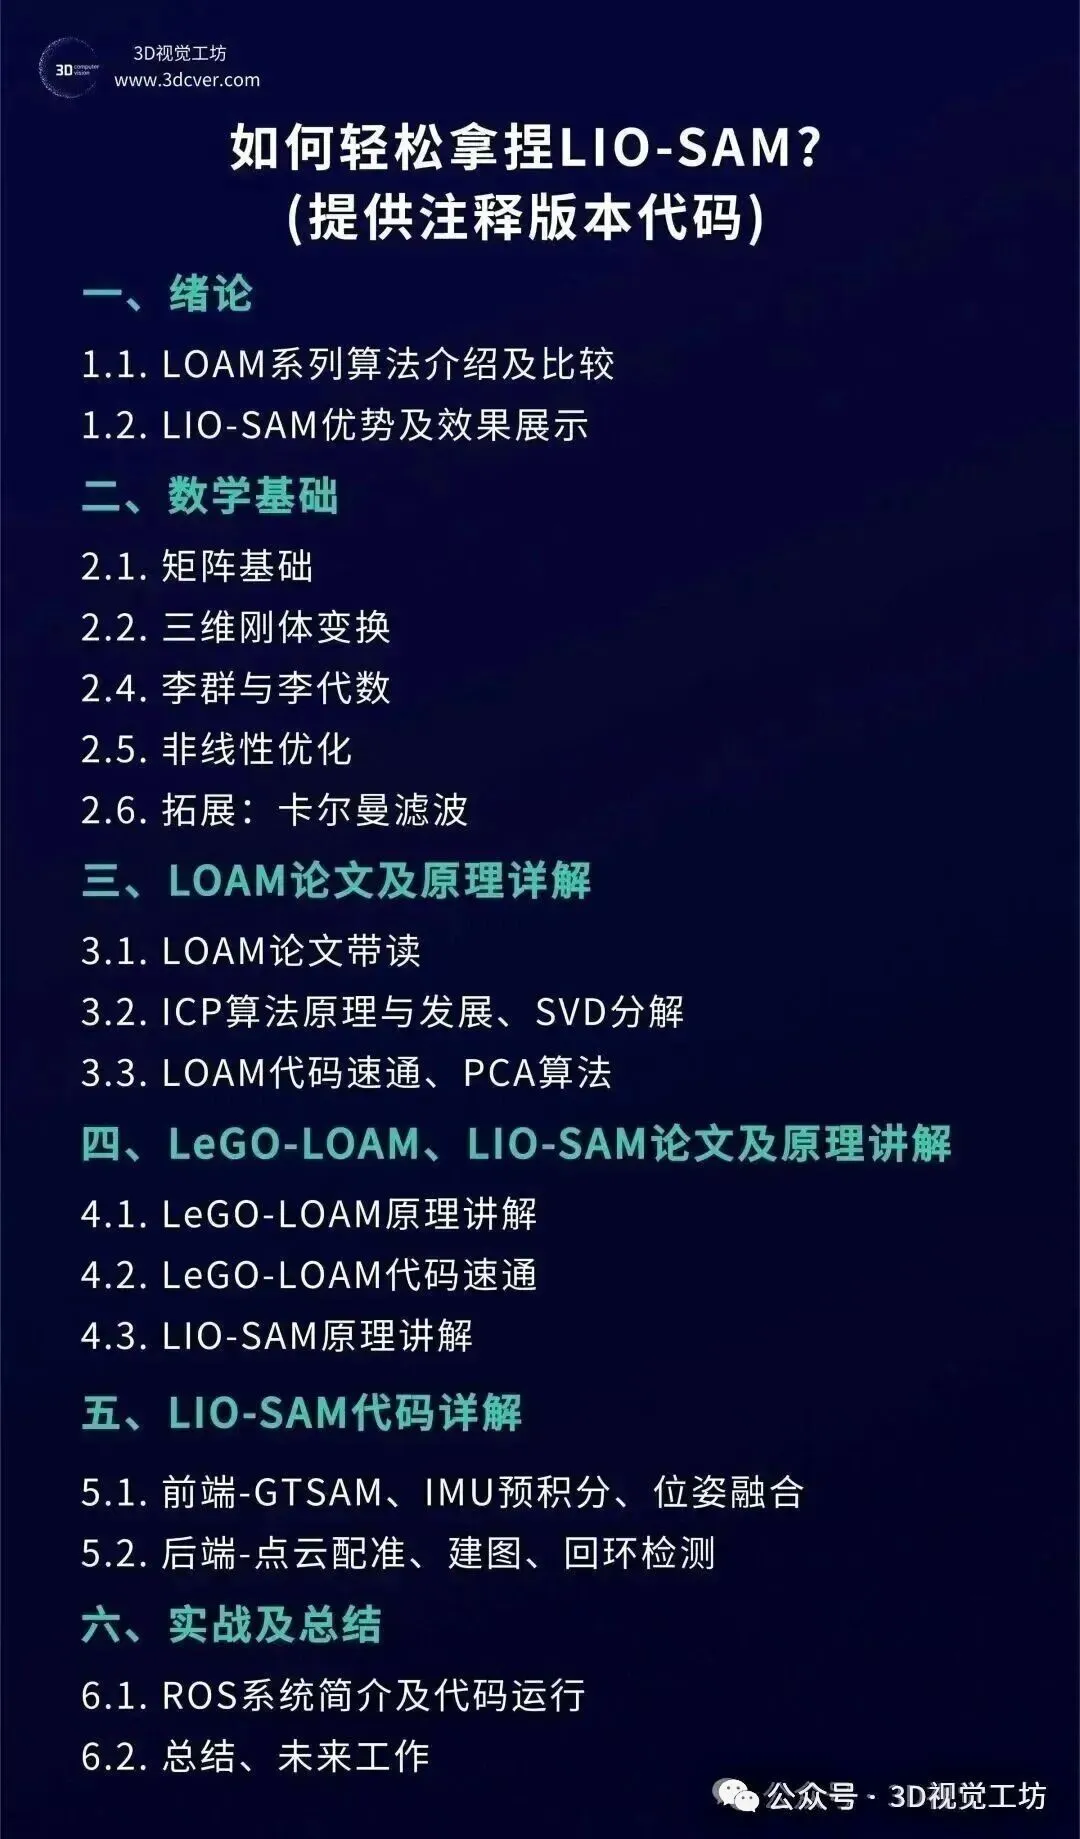
3.3.1 How to easily pinch LIO-SAM?
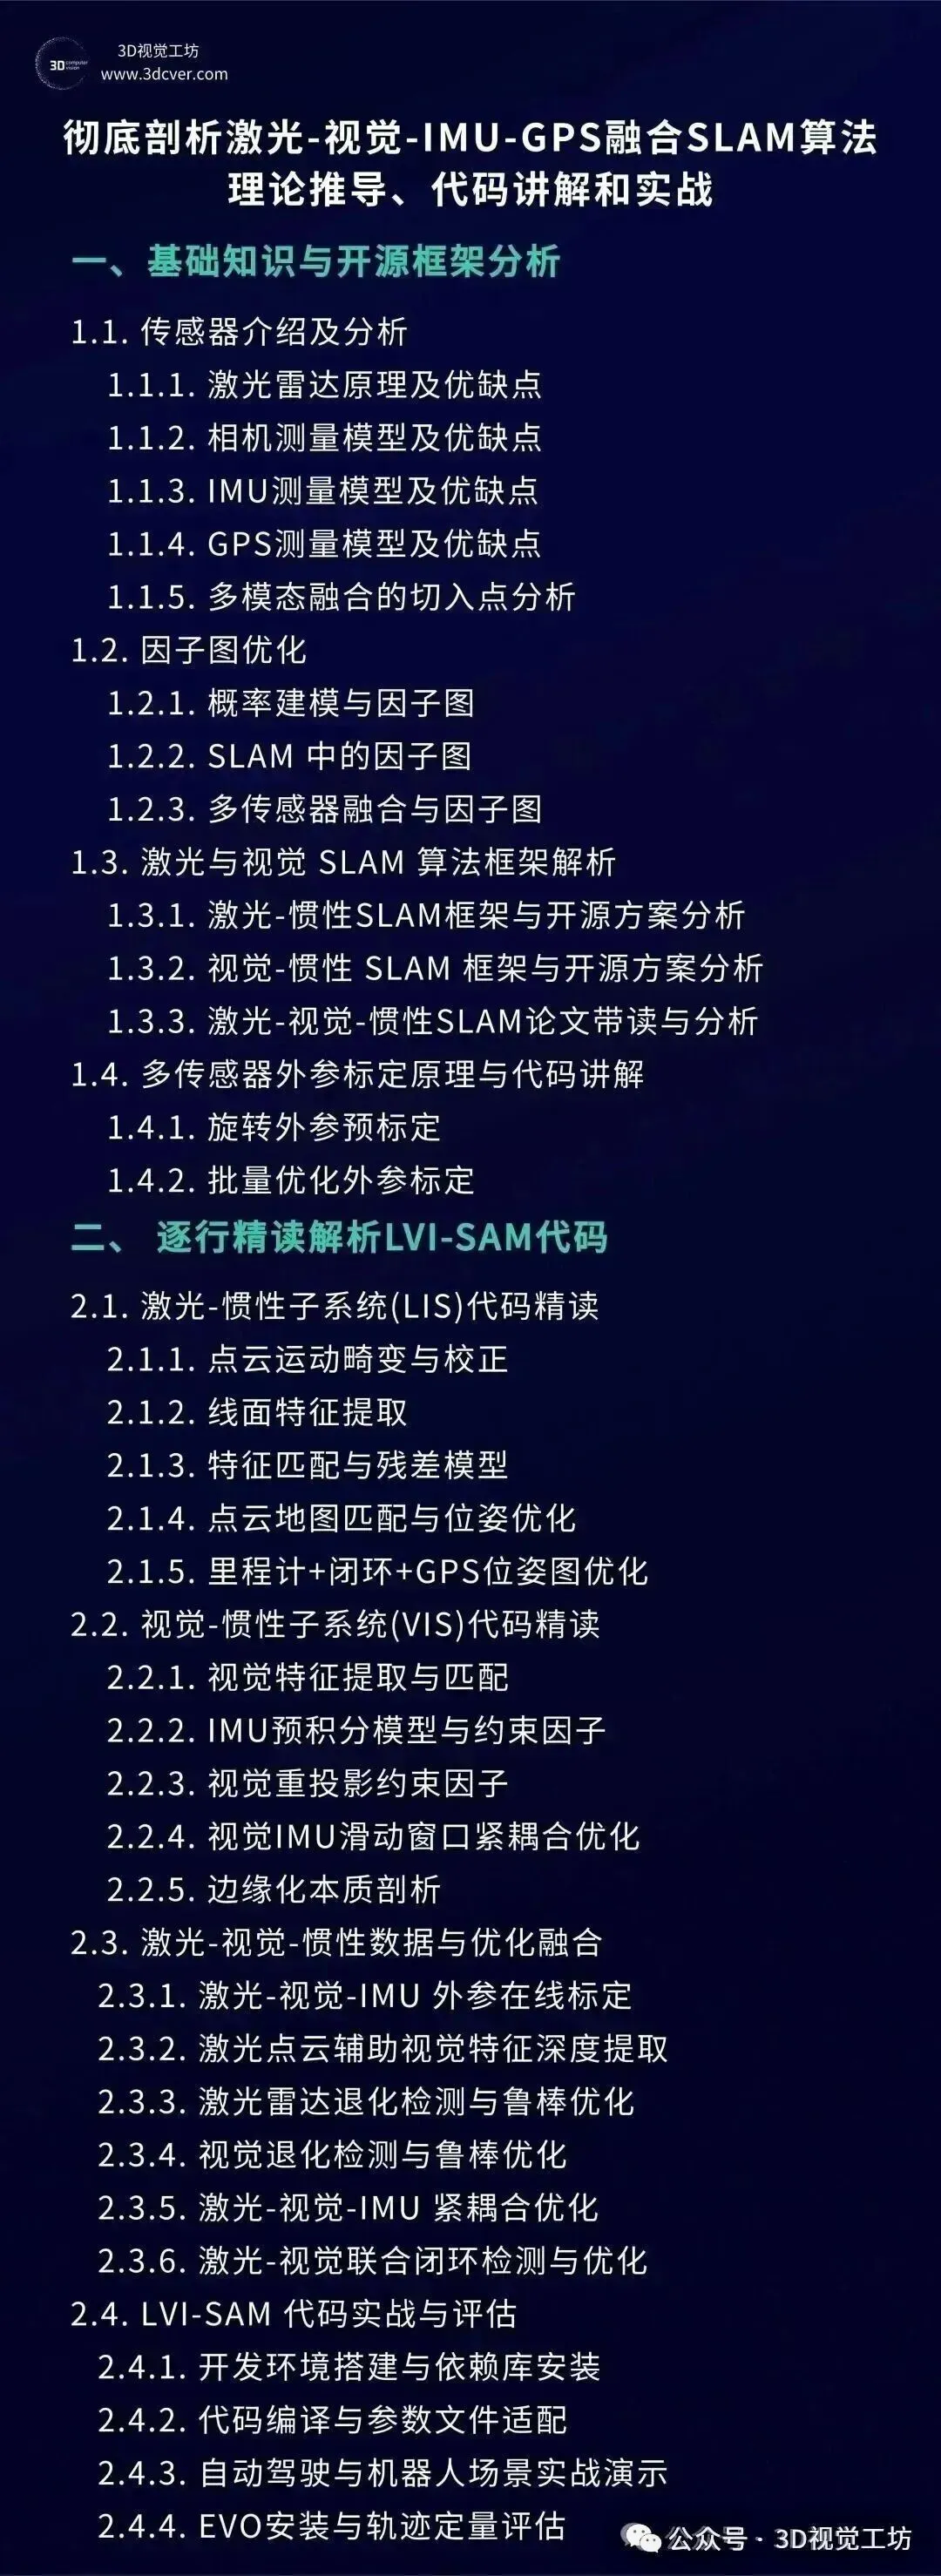
3.3.2 Thoroughly dissect the laser-visual-IMU-GPS fusion SLAM algorithm
This video course explains the technical difficulties and frameworks of the SLAM algorithm for laser radar-vision IMU-GPS integration from both theoretical and code implementation and, based on his years of experience in robotics engineering, explains the methods and techniques for multi-module integration in real-world robotic applications.
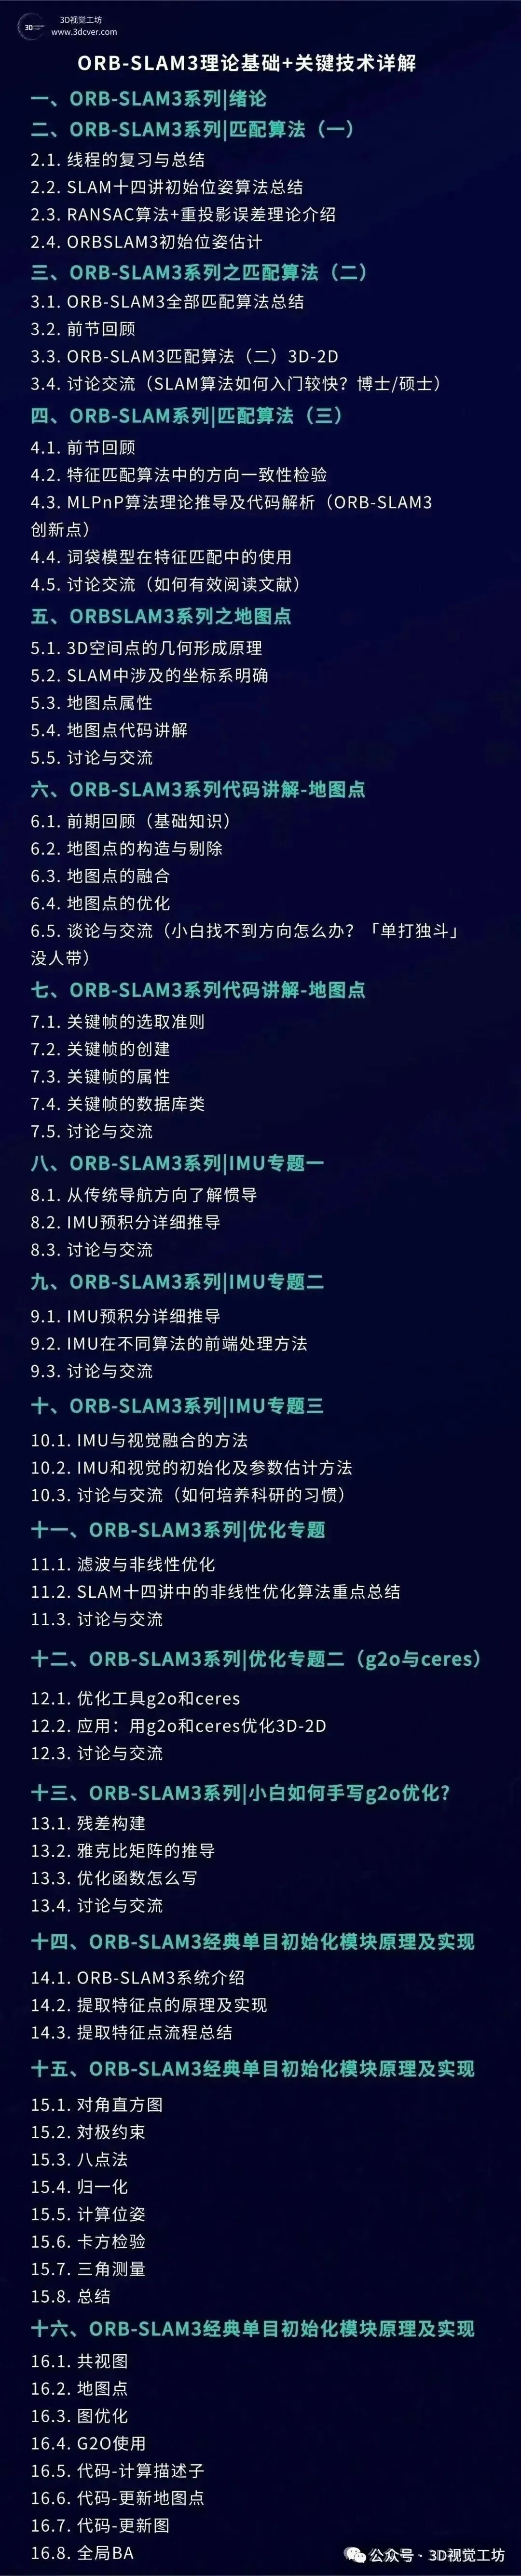
3.3.3 ORB-SLAM3 theoretical basis + key technical details
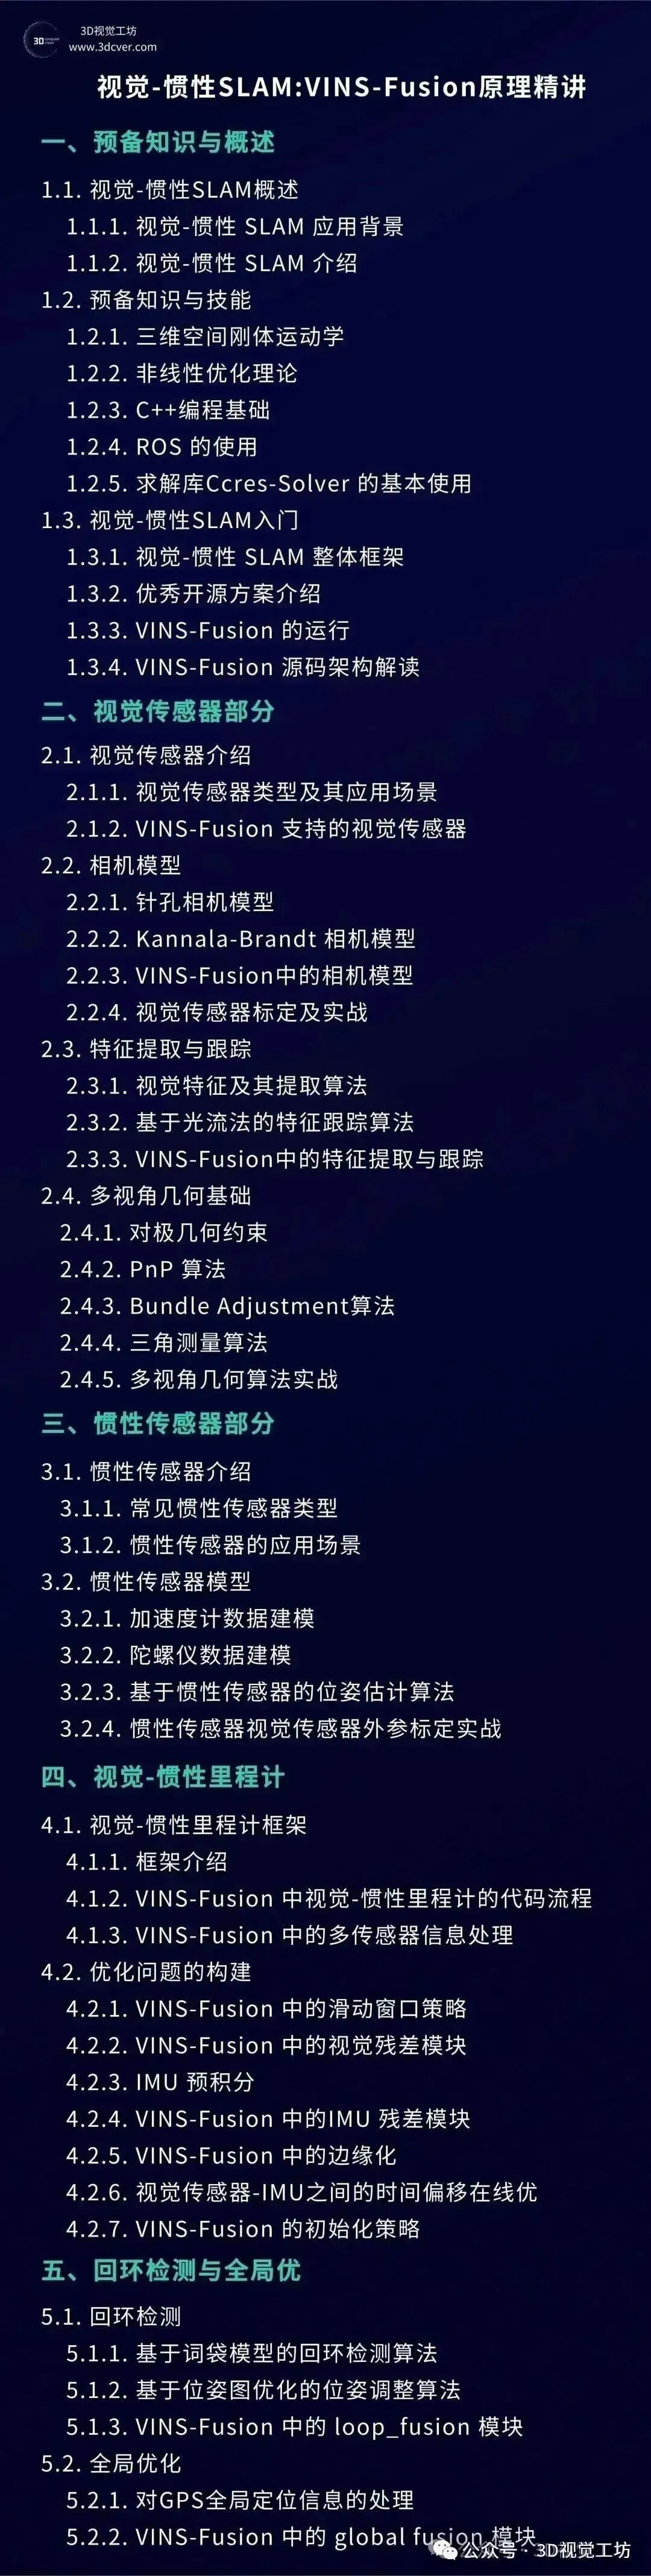
3.3.4 Visual-inertial SLAM: VINS-Fusion Principle Precision
The introductory and practical video tutorials for visual-inertial SLAM, combined with the VINS-Fusion source code, systematically align the basic theoretical knowledge of visual-inertial SLAM. The entire course is taught by first-rate algorithm engineers, from basic theory to code analysis, nursery-level teaching, assisting students to grow from small to large.
3.4 Self-driving
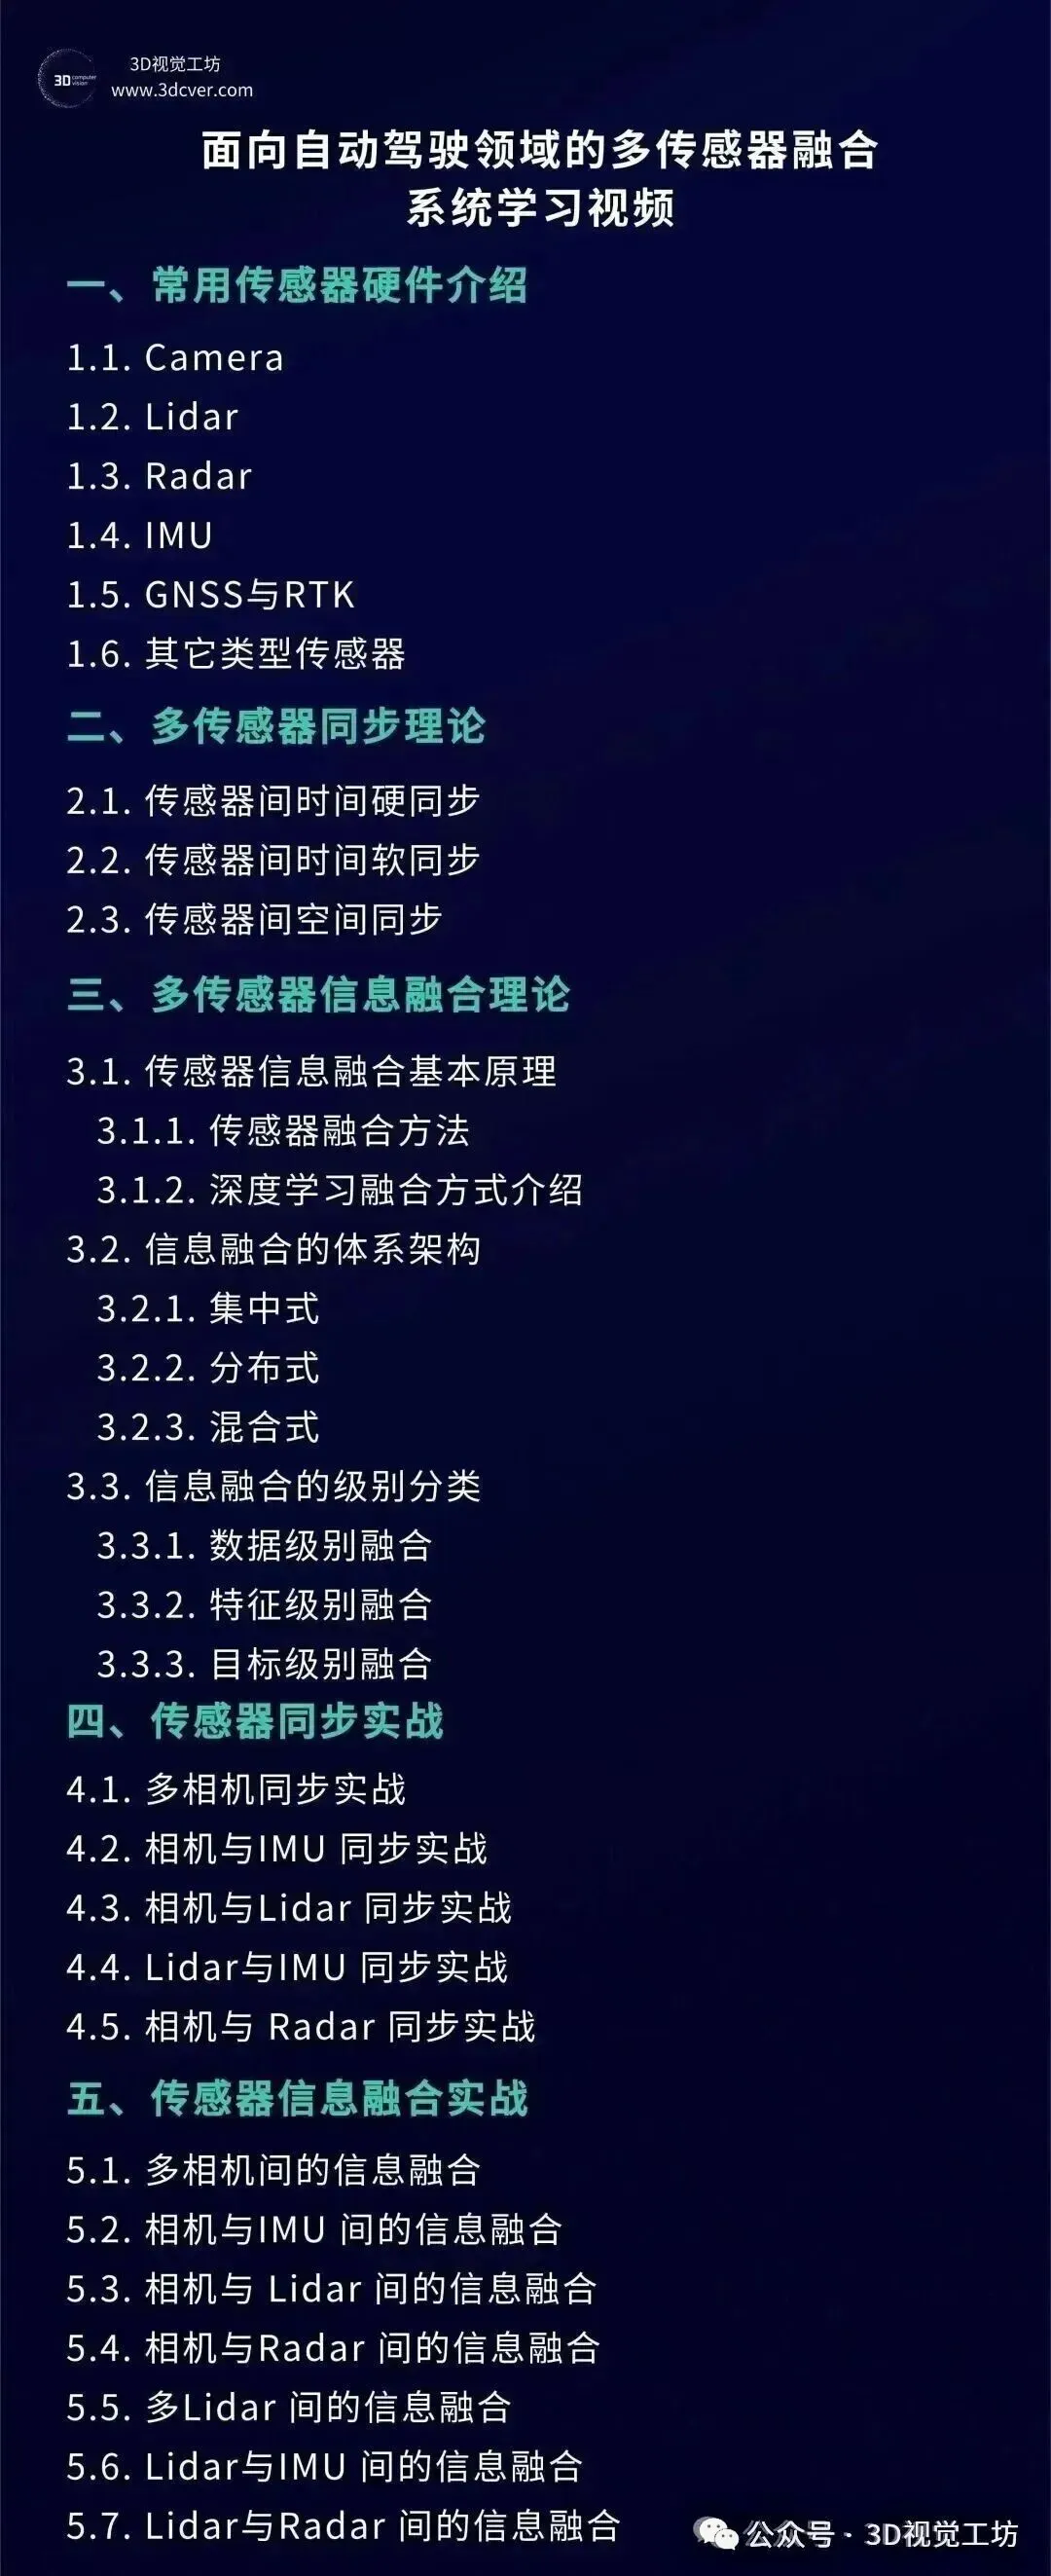
3.4.1 Multi-sensor integrated system tutorials for autonomous driving
Mainly divided into two large modules: theoretical and practical, theoretical sections mainly introduce the sensing hardware commonly used in autonomous driving, time synchronization and spatial synchronization between sensors and knowledge of information fusion rationality between multi-sensors; practical, more oriented engineering applications, how to achieve synchronization and integration between sensors in engineering, etc.
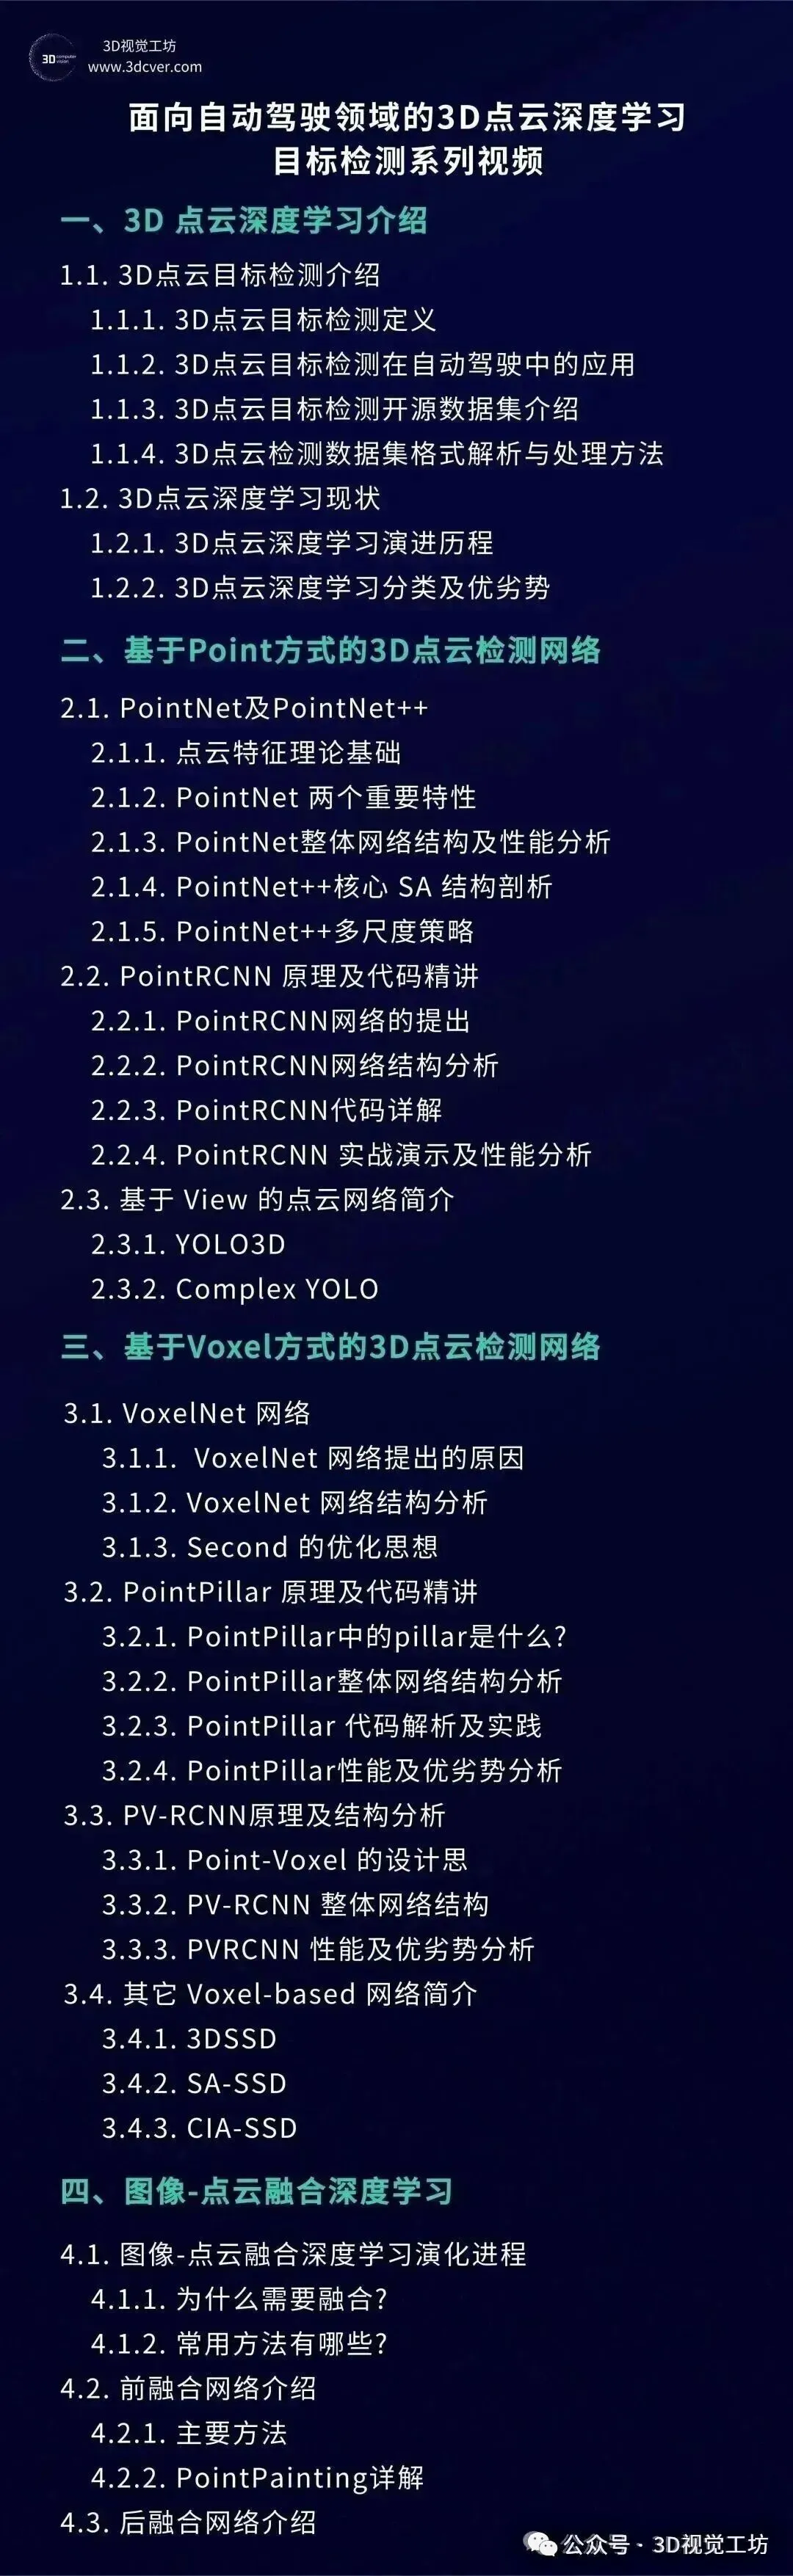
3.4.2 Detection of 3D point cloud deep learning targets for autonomous driving
This video tutorial focuses on 3D point cloud deep learning, system analysis and coding of point-based and Voxel-based 3D targeted detection network architectures to help students gain a faster insight and deeper understanding of point cloud depth.
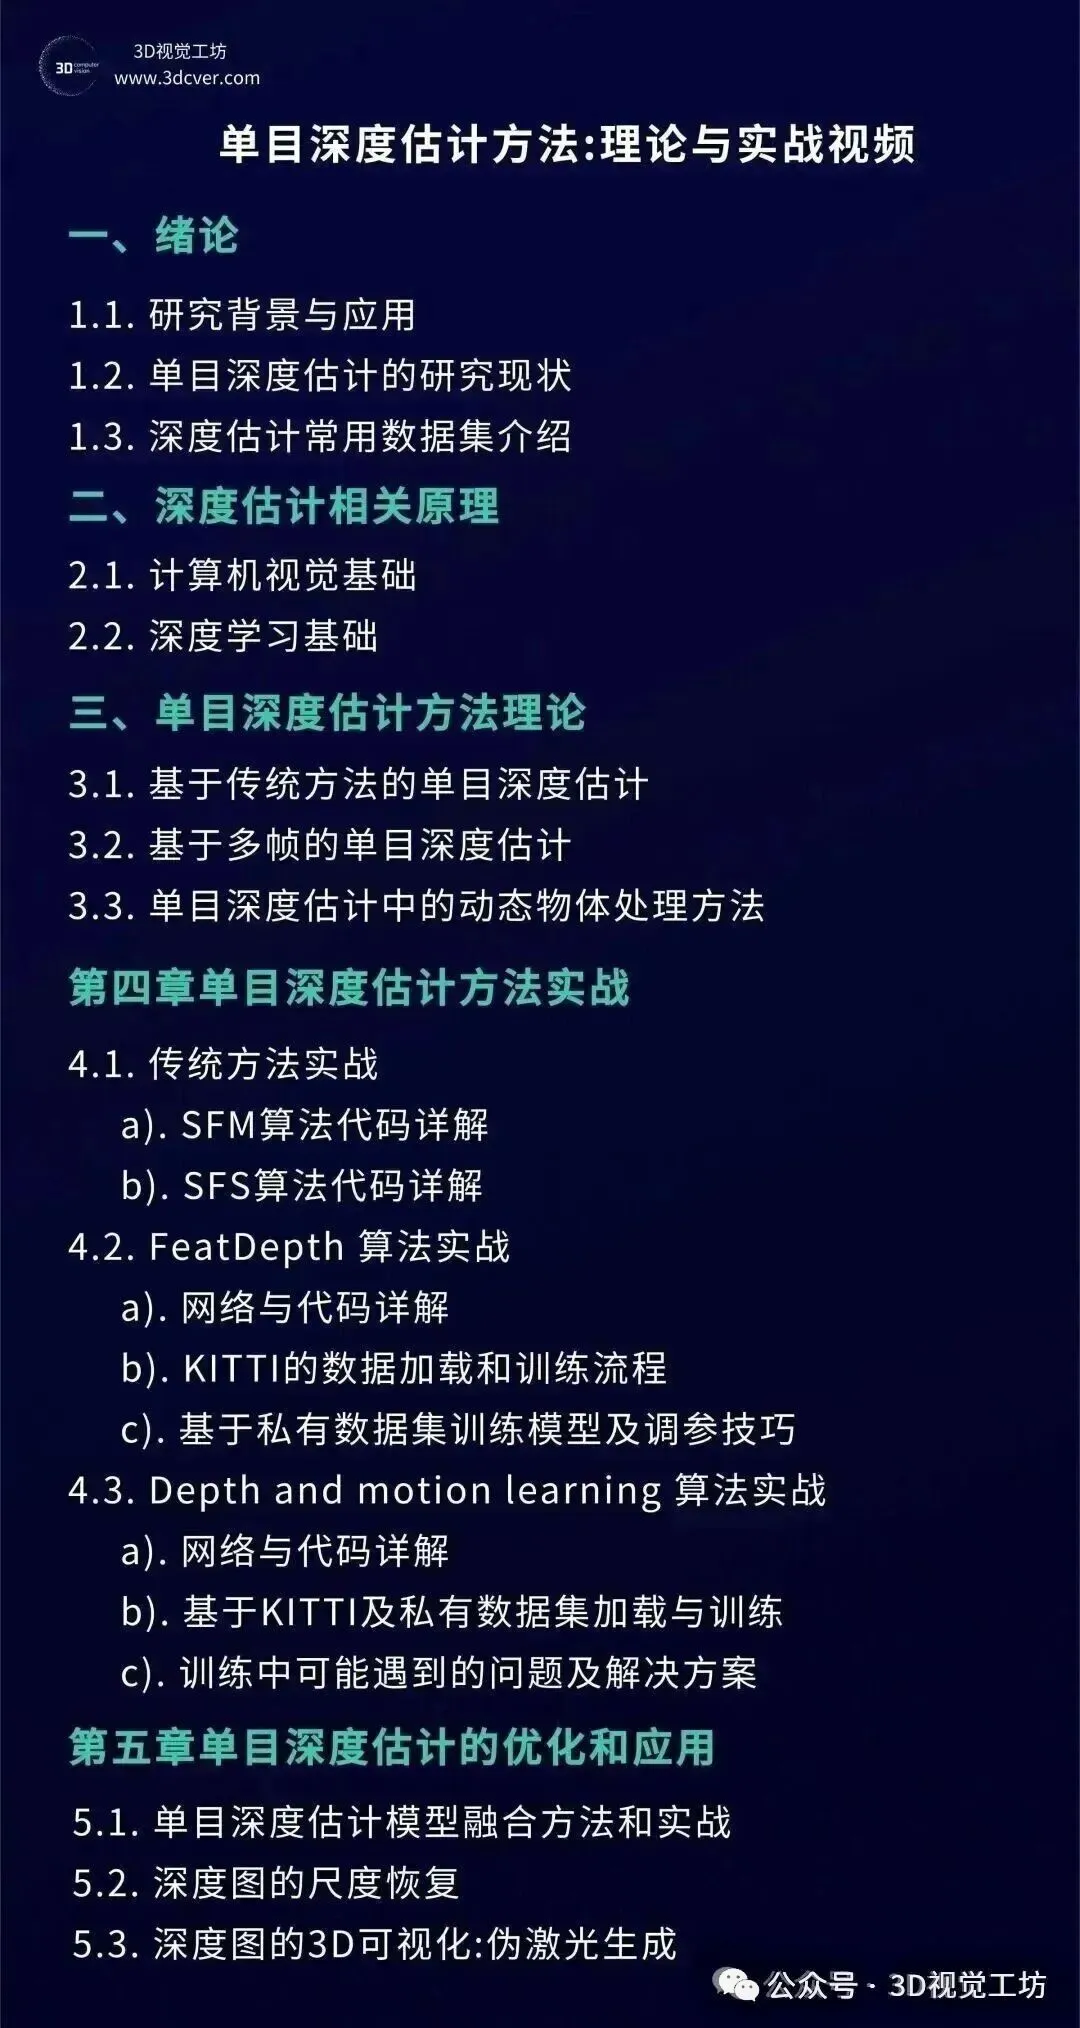
3.4.3 Single-point depth estimation methods: theoretical and real-world video
Video tutorials are mainly divided into two main sections: theoretical and practical, and due to the difficulty of obtaining the depth of the true value of the supervised method, and the effect of the unsupervised method is almost equivalent to that of the supervised method, we focus on the unsupervised method.
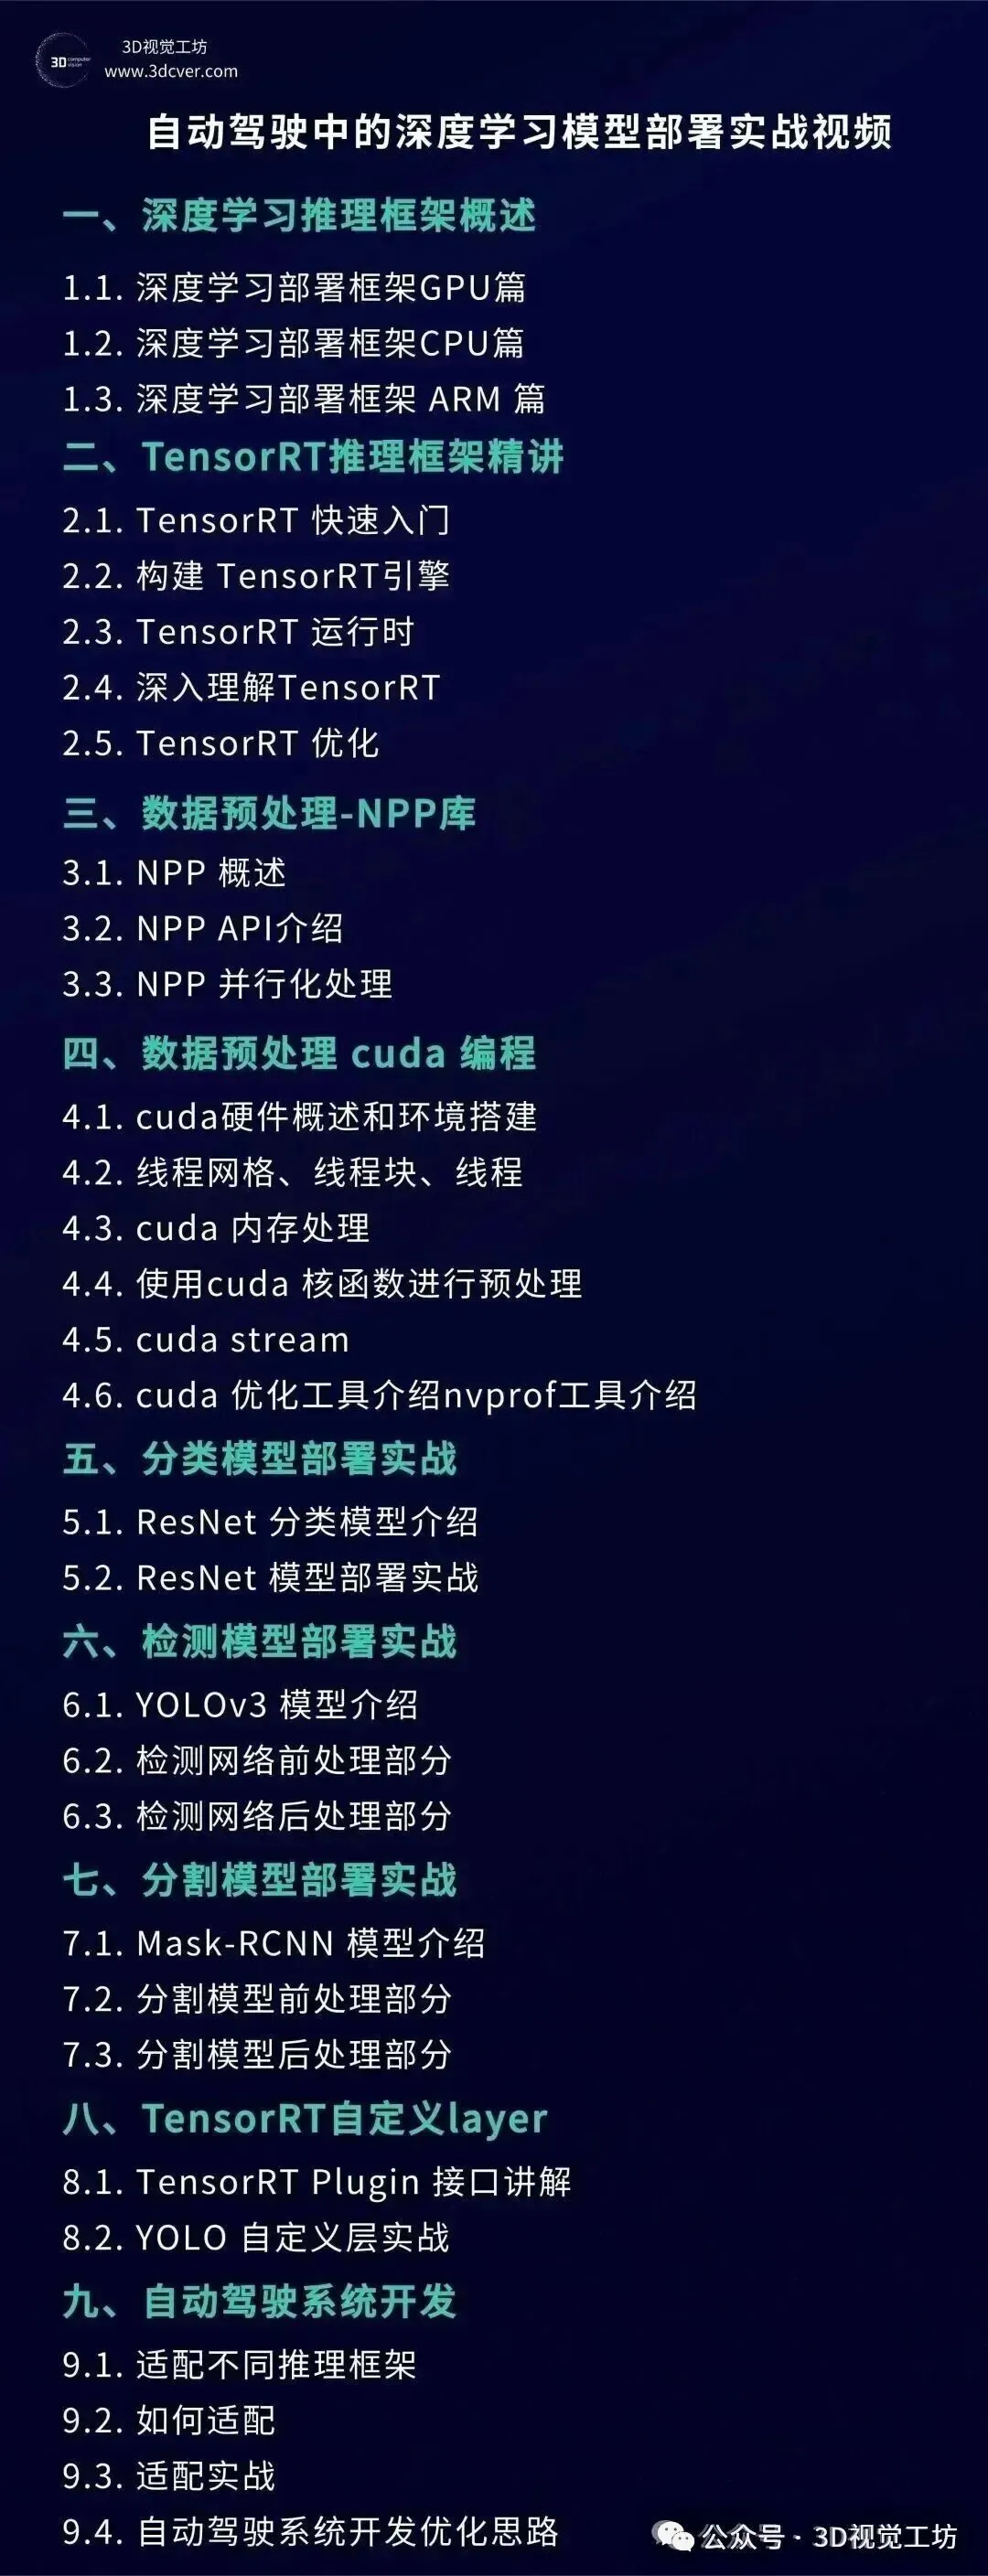
3.4.4 Deep learning models in autonomous driving deploy live video
This video tutorial will use a combination of theoretical and practical thinking, first to explain the programming model of TensorRT and the relevant knowledge of GPU/cuda to the extent that it is known; then the course will use three examples of classification, detection and division to demonstrate the detailed programming process and give the relevant code to achieve a truly landing industry share.
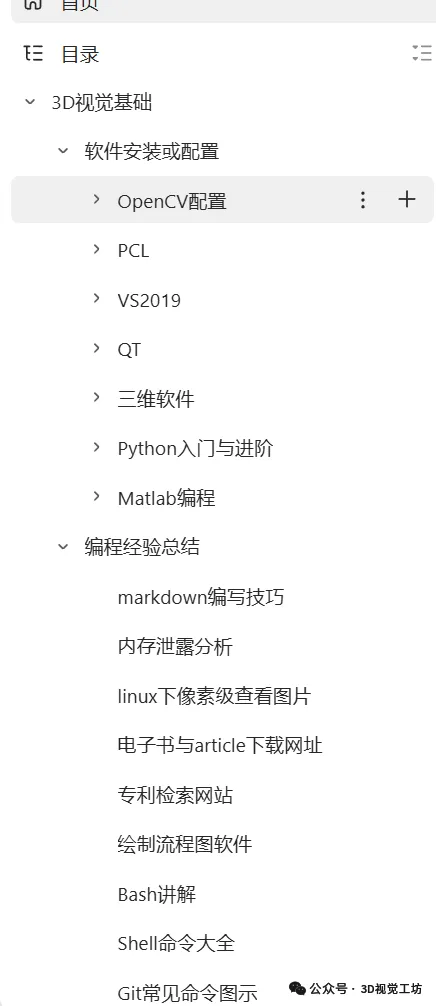
Four 3D visual foundations coming in
Considering that many beginners may find it difficult to configure 3D visual software or a visual library, we have prepared the configuration tutorial documentation for each module for you to learn.
5 3D visual source code summary
Below is the source code for the 3D vision industry on the planet: