At this year's WRC exhibition, many humanoids and industrial robots turned to real-world demonstrations, focusing more on real-world capabilities, but on real-world demonstrations, the vast majority of which still use traditional clawed hands. Many manufacturers showcased several high-frequency five-fingered hands, but there are few examples of real-frequency demonstrations that are actually embedded in the entire industrial product line.
Traditional claw is easy to control, training costs are low, carrying capacity is strong, but grasping the ability to generalize is weak, and replacement claw models have to be re-trained; agile models have excellent operating capabilities, but there is a real bottleneck in model training and load limits, and there is still a long way to go. In the development trend of manufacturing varieties and high-frequency switching, the market needs to break through existing schemes.
01.
Big Santa 1 takes to the stage: redefining industrial brilliance with transformation
Under this industry pain point and technical contradictions, on September 4th, Black Panther Technologies Joint Plug-in Robot officially unveiled the Big Bang 1 Industrial Variable Conceptual Craft to attempt to redefine the industry's brilliance by cracking the bottle of structural ideas that can be reconstructed. The Big Bang name, derived from its core characteristics, is the dynamic rebuilding capability of the Type 712 variants, achieving 7+N operational configuration switches. At the same time, the human-shaped robot attempts to solve the industry's ultimate challenge of whether to switch the dynamic end of a single-end executor, replace traditional multi-end claw rotation operations, simultaneously overload stable and sophisticated, and operate machines based solely on a single set of hardware components, model, and multi-line operations.
The official definition of the word is "multi-use, flexible transformation" and "overloading precision, pinching from the handle". These two phrases correspond to two groups of abilities: one group is a configuration variable, which switches movements such as pinching, grabbing, tilting, lifting by multi-finger gestures to accommodate different forms of workpiece; the other group is a load and precision coexistence, with the same hand carrying both large pieces and performing the fine removal of small pieces.
It's a phrase that comes down to the production line: one hand, replacing multiple end-user executors, multiple scenarios need to be satisfied at once.
According to public information, Hangzhou BlackBerry Technologies was founded in July 2025, by a joint venture between Shenzhen Technologies, a publicly traded company, and a core team of leading robotics companies from universities such as Jiangsu, Jeddah, Tsinghua, and the University of California, and established a joint laboratory with Zhejiang University, Jilin University, and established a strategic partnership with industry leaders and publicly traded companies such as Intel, Shenzhen Technologies, and MegaFon Shares.
Founder Liu He served as director of research and development of Shenzhen Technologies, General Manager of the Department of Robotics, operating nearly 20 complete robotics product development and large-scale delivery, and the rest of the core co-founders have an average of more than 8 years of experience in the robotics industry. For more than a year, three product lines have been laid out: underwater WA series, the world's first waterproof handset, engineered version available in water depths of millions of meters; general IN series, IP68 protection grade, whole hand ≤ 600 g; load ≥ 10 kg, target market; scientific research RE series, 16 active freedoms, with complete programming and graphic programming software.
02.
24 kg load and 0.03 mm accuracy, how long on the same hand
Load and accuracy are usually mutually reinforcing on the end-user. To overload, the transmission has to be magnified, reversed, rigid, self-loaded; to maintain accuracy, the load space often has to be released.
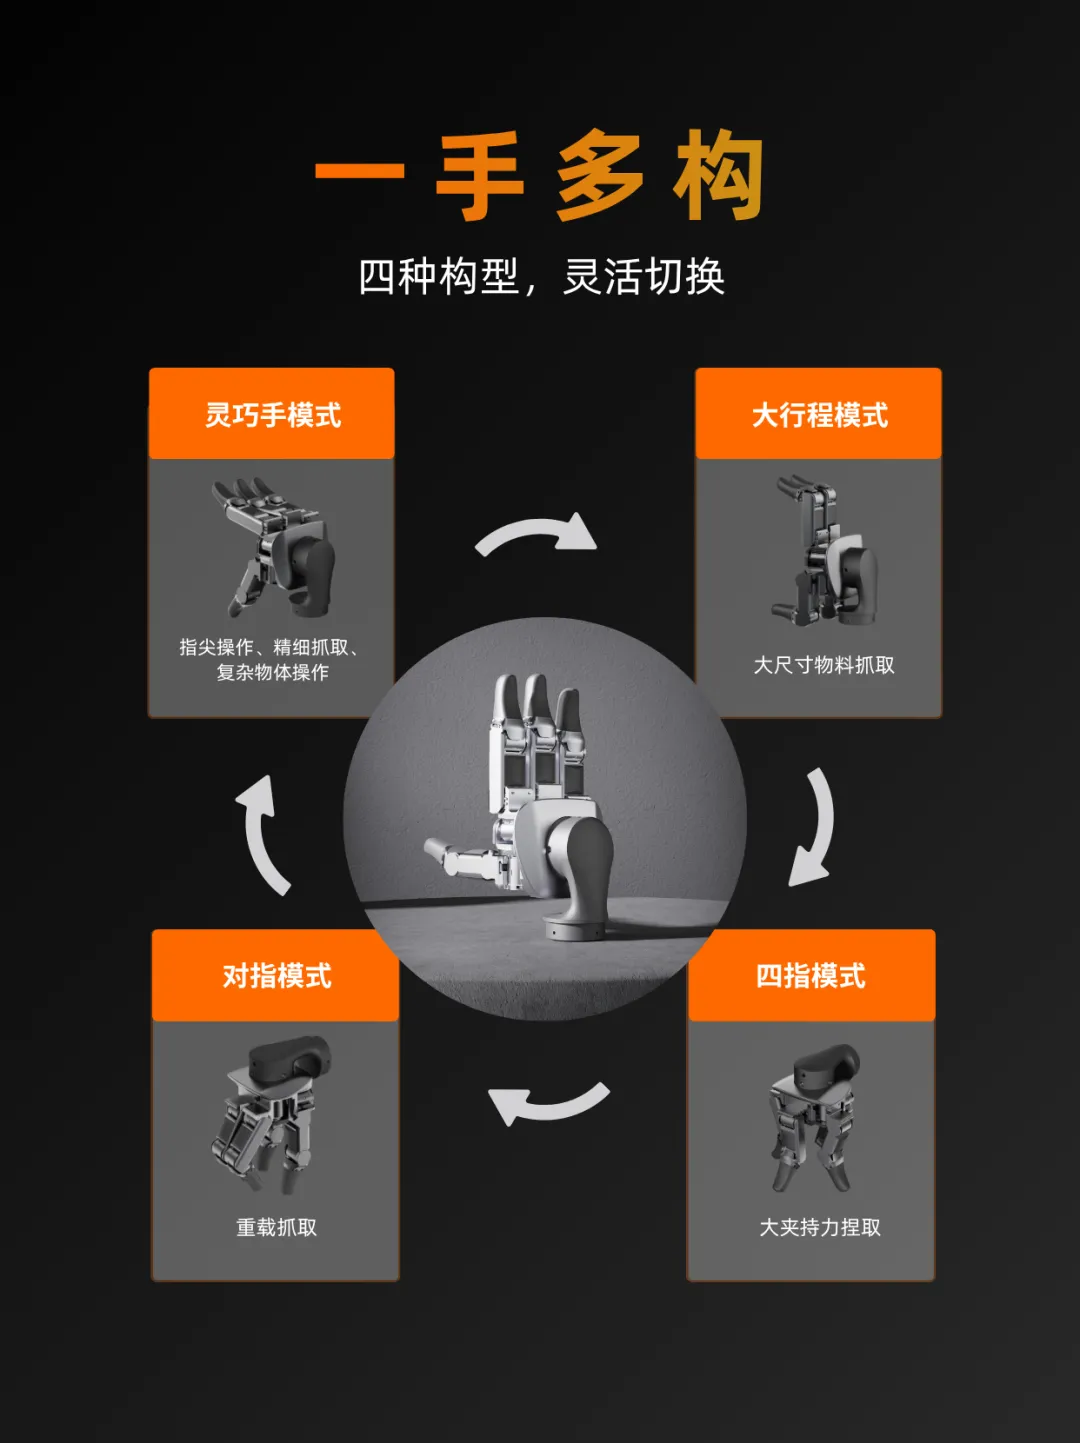
The solution to the "Great One" is to allow the configuration to share this contradiction: switching between the shape of a human hand and the shape of an industrial claw, clutching the wrapping web, fingertip operation and steady grip, respectively. It contains four basic models:
• Flexible hand patterns retain multi-finger multi-joint synergy, corresponding to finger manipulation, precise grasping and interaction with complex shaped objects;
• To improve the adaptability of irregular materials, the use of multiple fingers to form a stable wrap-around network for finger patterns;
• Shifting the large-scale route pattern to industrial claw shapes, reinforcing the rigidity and bearing of the claw, towards heavy-sized materials;
• In the production of four-finger service mixed-line, greater resistance is required for pinching.
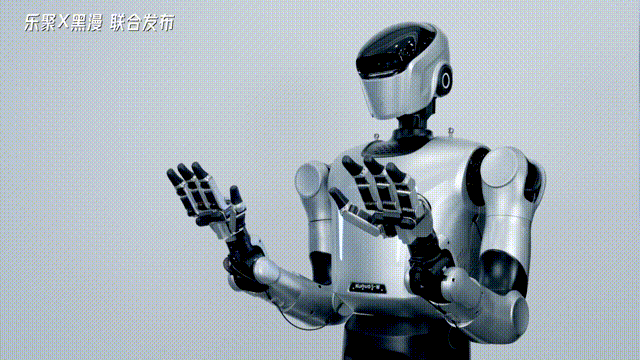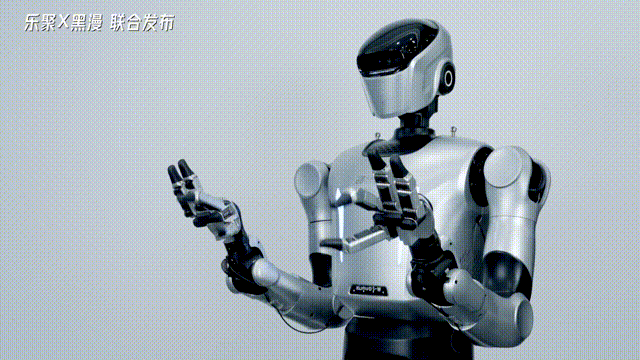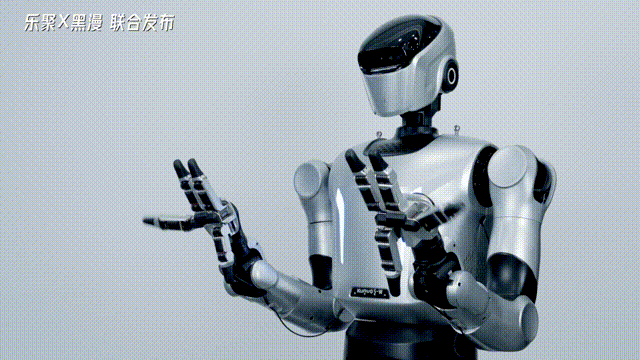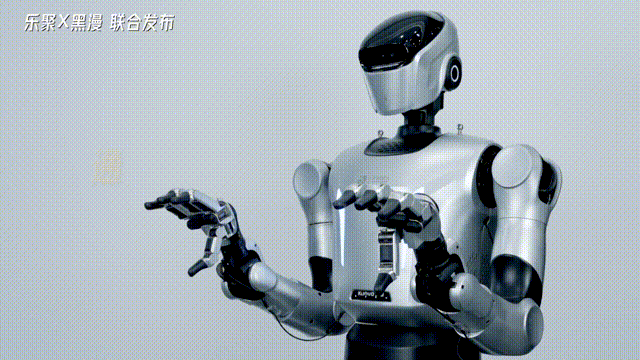
In the combined program, these four classes are further refined into seven types of structures for specific workpieces, i.e. in "7+N", 7N is the part that can be extended.
Structurally, the Grand Saint 1 uses a 4-inch, 11-inch activated frequency design, single-handed grip of a load ≥24 kg, repeated positioning accuracy ≤0.03 mm, finger sharpness ≥18 N, control frequency greater than 100 Hz, and can be synchronized with the robot's body to perform end motion.
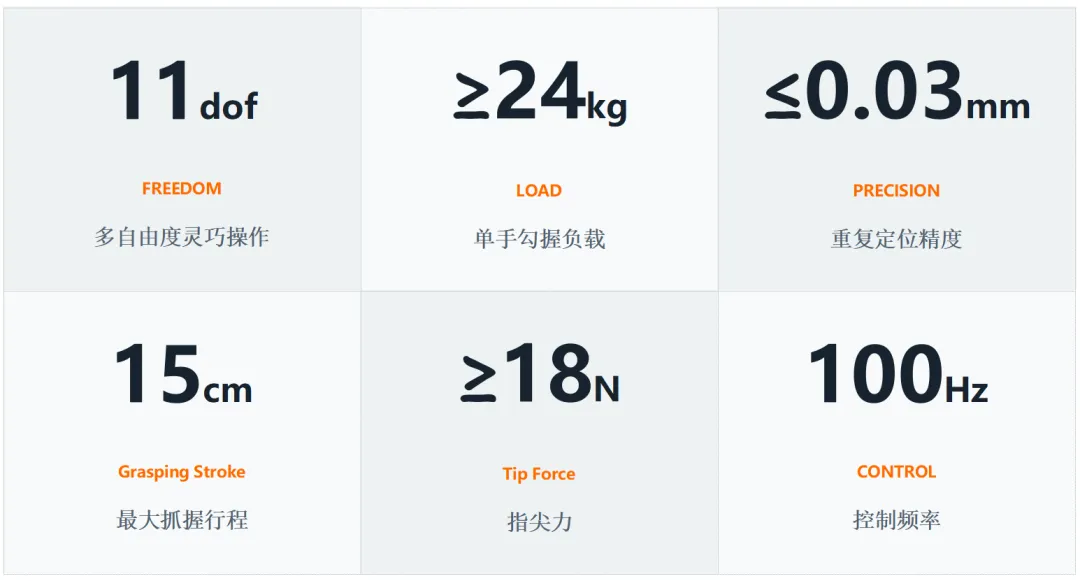
The two alternatives are worth mentioning. One is that in the 11 degrees of freedom all active aluminum industry, many programs use passive joints in exchange for adaptation and weight reduction, the cost of which is that the joint state is not completely controllable; the data is not completely retransmitted; all-active means that each joint can be controlled independently; they can both retransmit position and current, and the closed-loop control and data collection are thus based on the same observable state.
In addition to the parameters, the toolchain determines the distance between a hand from "powerful" to "researchable". It is known that "Great One" provides Python and C++ packaged SDKs, directly exposing joint-level controls and motion parameters; provides standard URDF models for kinetic analysis and system integration; supports MuJoCo simulation, for operational strategy and remote-operation program pre-verification. It also supports the mapping of operator hand movements to the end via VR or motion capture, recording joint movements and control instructions for reproduction, modeling, and verification of remote-operation sample collection, and is one of the main sources of current body-operation data.
03.
From custom to generic, meeting the demands of multiple types of typical industrial scenarios
At present, "Great Sanctuary 1" has covered many types of typical scenarios, such as small parts, dismantling codes, delivery sorting, SPS sorting and homeless warehouses. The common ground is clear: SKUs are numerous, bulky, small batches, frequent changes of type, the most difficult terrain for fixed functioning claw claw. These are also the research and development of "Great Sanctuary 1" in the real production line, which is repeatedly encountered.
• pinching pencils, screws, and electronic components with your fingers;
• The outside of the hollow ringed parts with holes and earplugs is uncomfortable to hold, and the cabinets are used to extract power from the inside;
• Separating small and medium-sized parts with two fingers;
• Handling of soft packaging, plastic boxes, courier items and metallic items by wrapping;
• Uncertain-shaped aluminum transmission power controls adapt to grip;
• Clutch around cylinders and regular triangles, such as water bottles, jars, etc.;
• Large packages are disassembled, coded, and transported by hand.
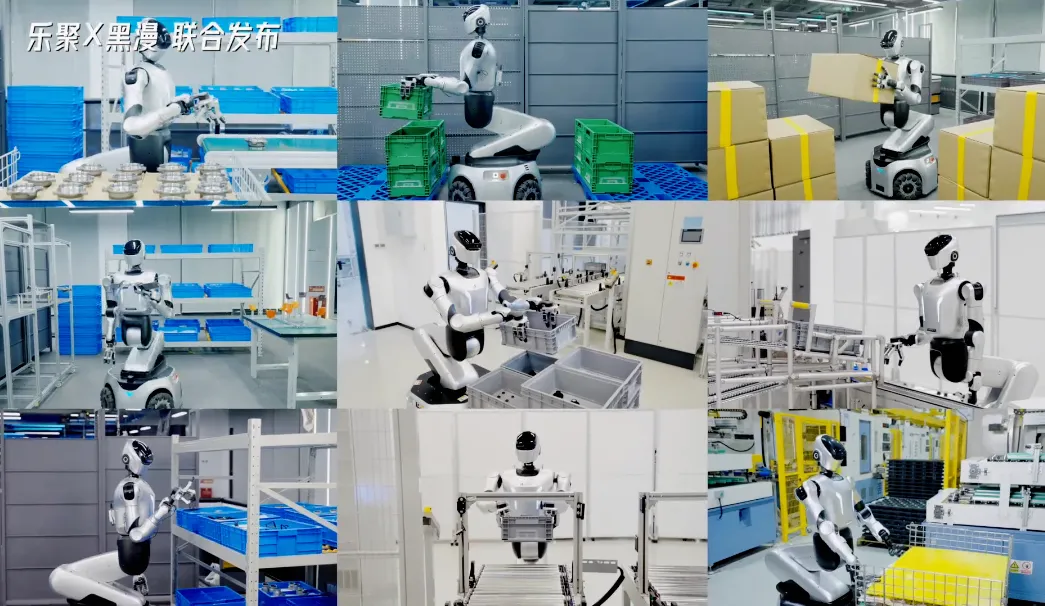
For example, in e-commerce warehouses, the form of materials sorted by delivery is almost impossible to list, the traditional practice is to sort by category lines, with each paired special end, the production line being cut into a number of non-interchangeable channels; the transformation scheme digests the differences in one hand, and the blending becomes possible, changing the production line structure rather than just the sections.
The demands of the unmanned warehouses are stable disposal under long-term unmanned care, the range of goods from bottled beverages to soft packaged snacks is enormous, one hand can agree directly to decide whether the model can be established. The pain point of dismantling plastic containers is easily deformed in the case, the official expression is "24 kg stable grip, easy to pull grip intact" in the fast delivery and food scene, the second half of the sentence is often more critical than the loading number itself.
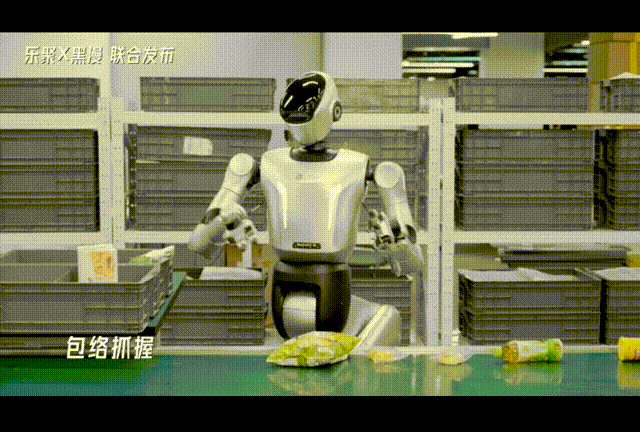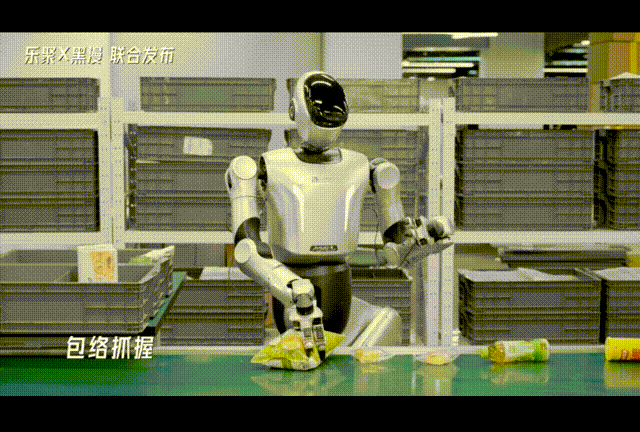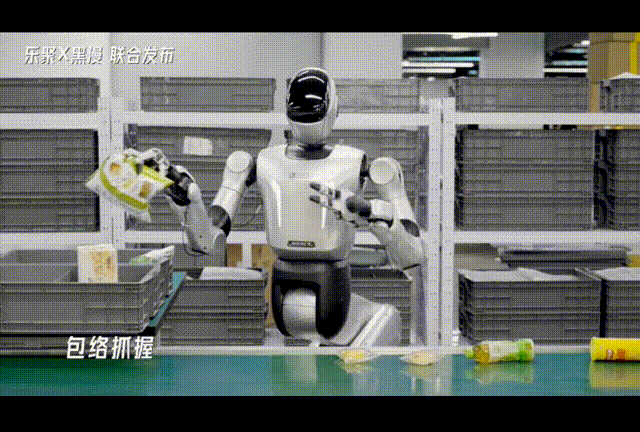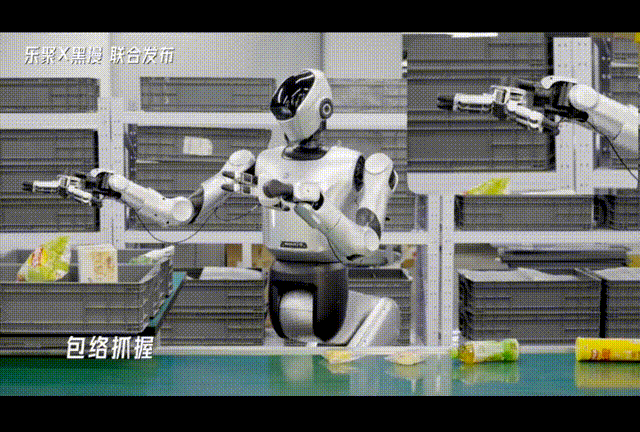
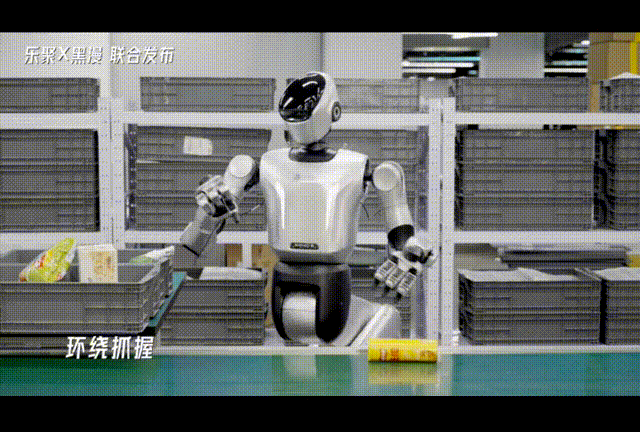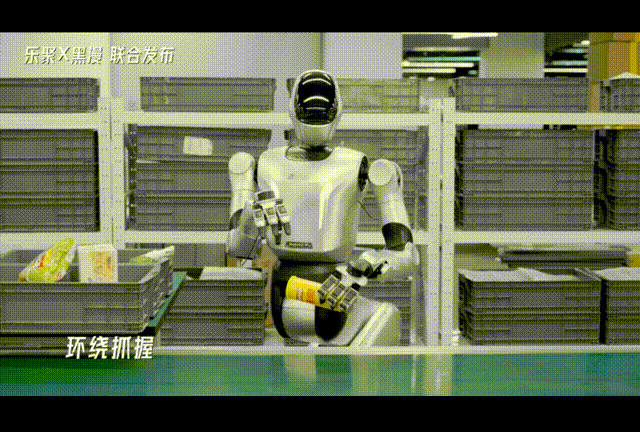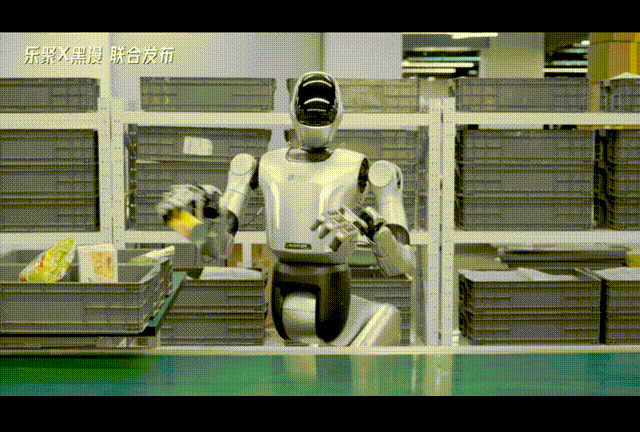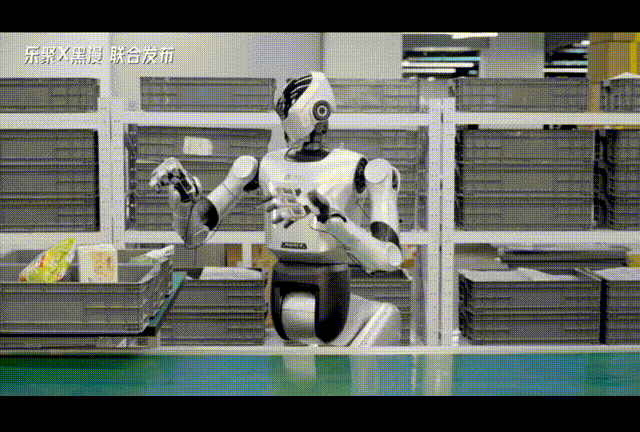
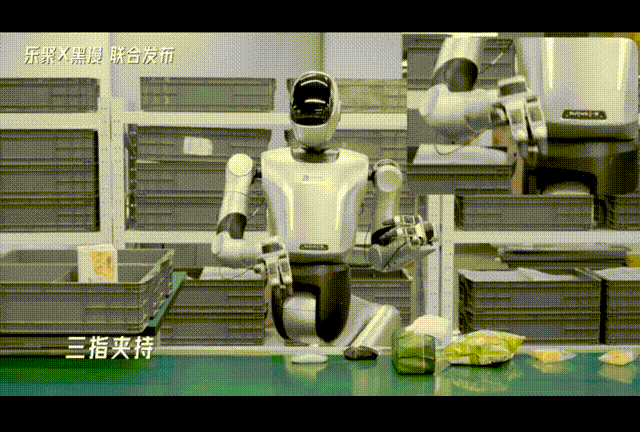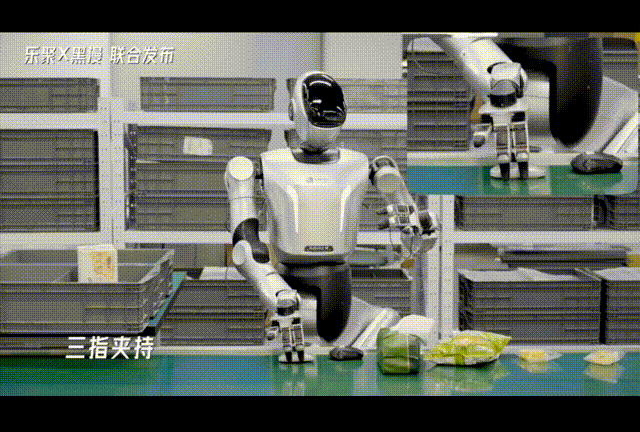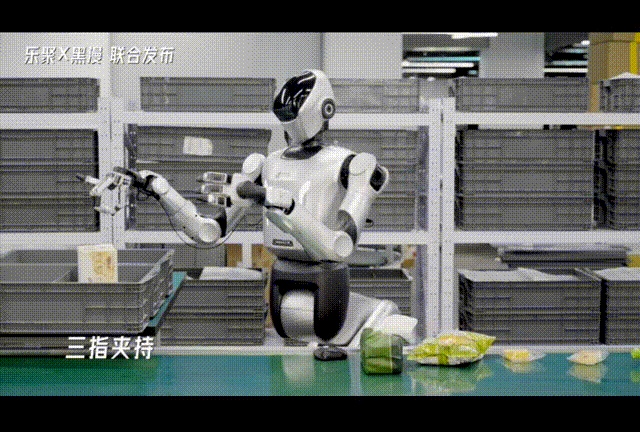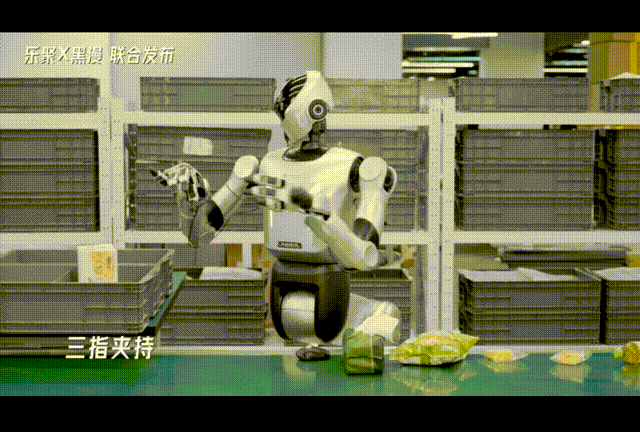
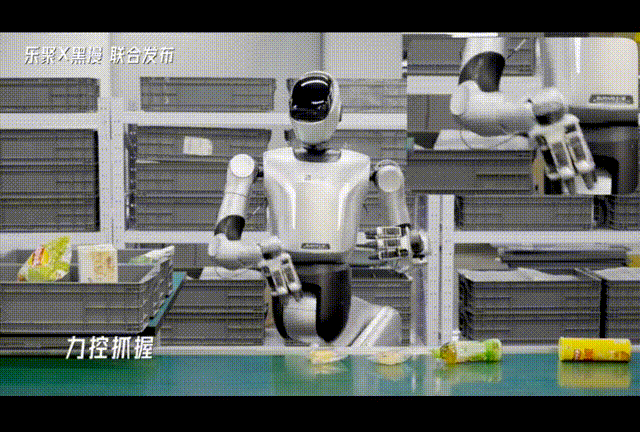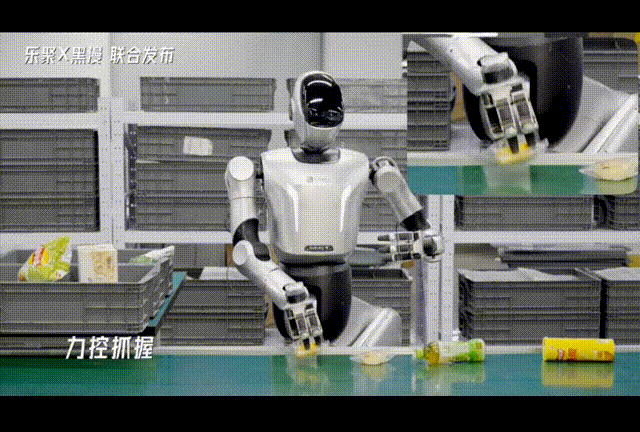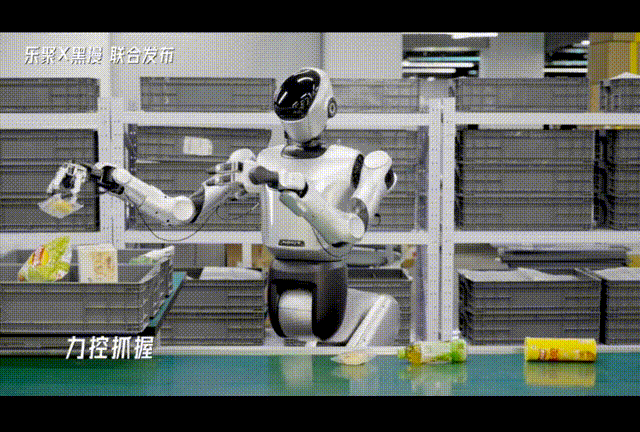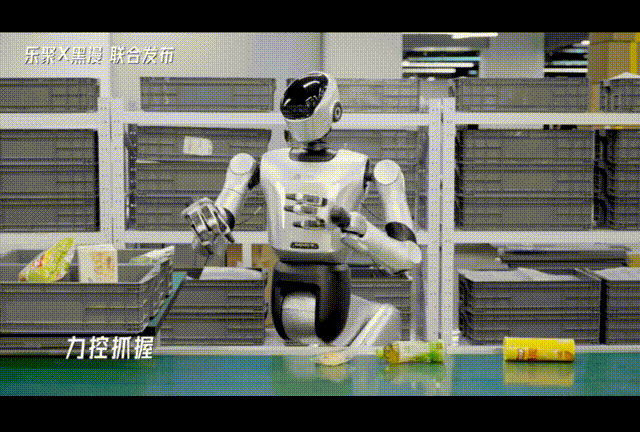
In 2023, domestic transportation robots and assembly and dismantling robots accounted for 52% and 15% of industrial robot shipments, respectively.
The other layer of value is on the data side. The early adoption of "action replication" in the field of physical intelligence allowed robots to remember specific joint trajectories, hardware changes, object changes, model capabilities often fail, data needs to be retrieved, parameters need to be reset. Uniformity of end-forms is itself a prerequisite for data reliability.
The Big Bang 1 has access to platforms such as machine arms, humanoid robots, both for use as end-user executors and as data and execution nodes, supporting a complete chain from remote-operation demonstration, data compilation, strategy training to simulation and real-world machine verification, for use in simulating learning, reinforcement learning, multi-joint synchronous control, and multi-modal studies of visual cuticle touch vibrations. For humanoid robot assembly plants, this means operational capabilities can be quantified, replicated, and continuously trained.
04.
Customized general-purpose hand tools for human-powered robots
From here, you can put the "Great One" back in the track coordinates and see where it is: it's not just another hand, it's more like a human hand.Customized general-purpose hand tools for human-powered robots。
Today, the vast majority of smart hands are following the path of life: stacking freedoms, mimicking human appearances, mimicking joints, with the goal of being "like human hands", essentially doing it for humanoid robots.Formally AdaptedIt's not the way that Big Santa 1 is going, and it's not about the shape, it's about the problem.How to adapt to work?More than that.It's a great way to make a living in the industry.
The path is different and the landing point is different. Before the latter entered the industrial scene and shifted to the variable configuration, BlackBerry Technologies pioneered a category that was blurring its previous boundaries: the variable configuration general endpoint for industrial operations. It was a pioneer on this path and thus became a defining factor.
The market data is also mutually supportive. According to industry research, the size of the smart hand market will increase from about 13.62 billion yuan in 2025 to about 20.728 billion yuan in 2030, with a compounded five-year growth rate of 72.38%.The capitalist side of the story is equally clear: with almost a billion yuan of cumulative financing over the course of a year, investors from industries such as robotics, eastern engineering, megafinance, Shenzhen technology, and other institutions such as PDA Capital, zero-capital investments, megafinance, and megafinance. BlackManufacture is able to jointly develop an industrial terminal program with the entire machine plant, which also indicates where new players with unidentified, real technology and accumulated real players can still enter the race.
The value of a hand is ultimately written down by the production line. It can "change" and is answered by rhythm, rate, and maintenance records; while the first to set standards for "industrial smart hands" is the one who holds the initiative in the second half of the game before the skillful hand enters the deployment era.