One of the observed changes at the 2026 World Robotics Congress is that the frequency of artificial intervention has significantly decreased in scenic chemistry demos.
Ballstands are no longer dependent on the on-site take-over or repositioning of the system by the engineer, the ballstands are used for batting, tea-making operations, transfer band sorting, and the task switching link is no longer dependent on the same robot continuously passing the cup movements after the tea bubble is completed, the material specifications are changed to automatically adjust the grabbing position, the entire process does not return to the original point, and the operation control strategy is not re-trained.
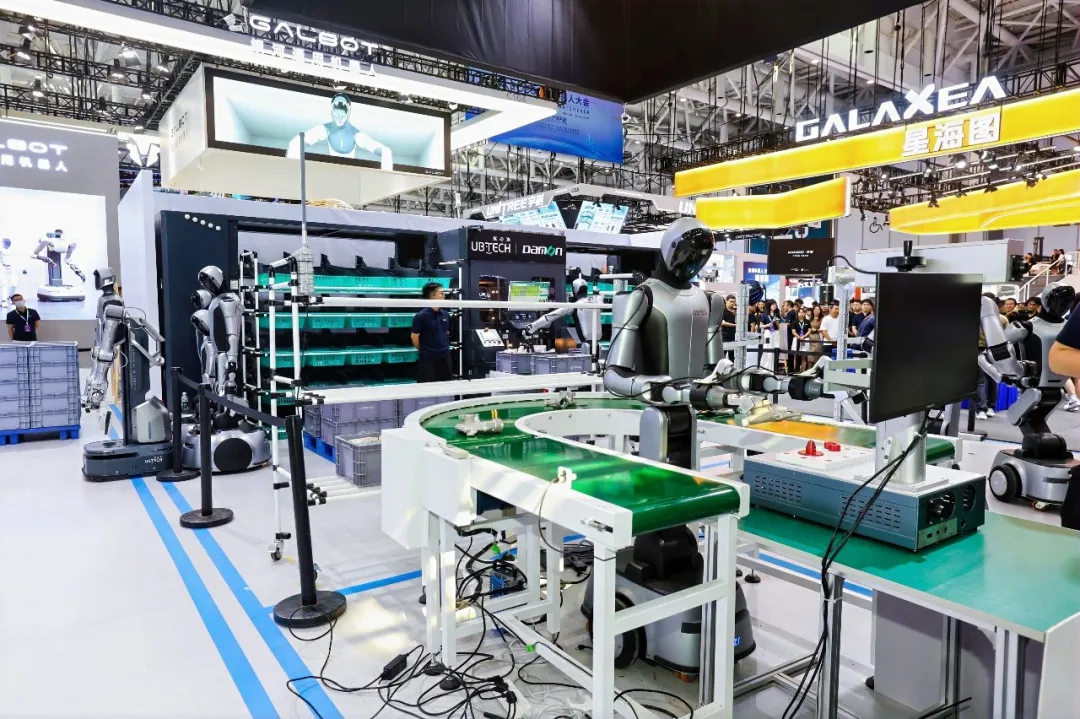
The technological context of this real-world change is: the physical intelligence industry emerged in the first half of 2026 with the emergence of architectural shrinkage. The rapid system + world model; the Beijing Human Innovation Center "Hui Thinking Object" (VLM Brain + Operating Brain); Ugen (Isoconomic Brain); Physical Intelligence (VLA Superimposed World Model Sub-Objects) present different schemes, but open technical discussions commonly refer to the same problem: the semantic layer of the brain/tasks) and the marginal yield of the brain/operating/executing layer) narrowing separately, the time sequence of the bottles between the two brains matching the following: how high-level language instructions are mapped to the synchronous sequence of tasks, and how the two layers are uninterrupted in the transcript state.
The WRC 2026 on-site continuous operation demo, which is the initial opening of this link, is verified. Its engineering meaning is different from the previous "post-overflow" class high dynamic movement demo: the latter verifies the single-point control limit, the former verifies the task layer and the motion layer in the open sequence of synchronous stability, the latter closer to the distance from the output line deployment.
01.
The decision-making and operational control flow is consensus, more than one legitimate path
The decision-making and operation control combined flow is consensus, with more than one legitimate path. The most interesting thing on this line is that it's not who has turned their head, but on the pitch, and it's easy to walk a path to the realization of a set called "physical intelligent agents", with both intelligent decision-making and stable operation control capabilities. In the PhyAgents system, PhyAgent carries upper-level decision-making, and PhyCore is responsible for bottom-level operation control, with the two modules sharing the same set of state-of-the-art operating spaces from the reinforcement training phase, without the need for additional intermediate themes to complete cross-brain communication closures when deployed.
Confirming the scene selection of the penny ball and the ping-pong ball, not because of the good video, is a ball class that uses a highly dynamic environment, milliseconds of intelligent prediction, moves the lower half of the body with the full body coordination of the half-half-half-half-half-half-half-half-half-half-half-half-half-half-half-half-half-half-half-half-half-half-half-half.
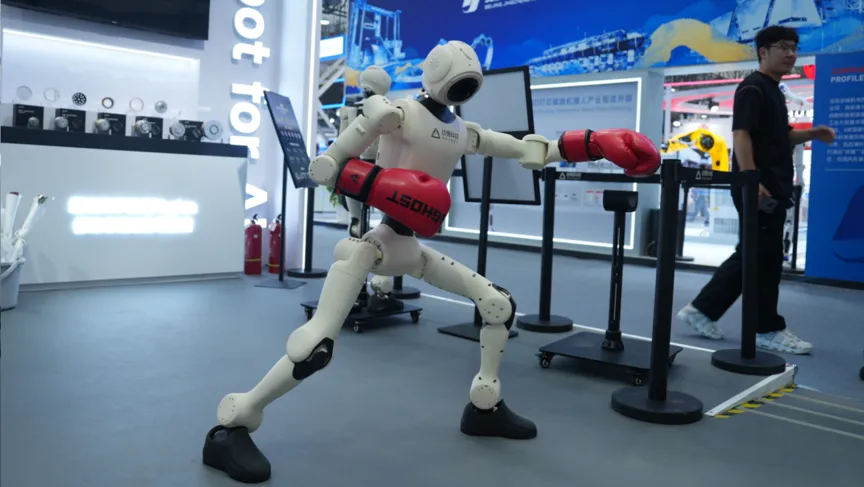
C2 ((135cm double-leg) links are: human demonstration of initial strategy, massive simulation from bowling pre-training, real-machine mitigation, deployment at the end of the expansion of the Karman pump wave to make trajectory predictions. According to EasyTech, during the general meeting in April this year, C2 faced foreign visitors for the first time to open the laboratory to play with humans autonomously experience, without a pre-set remote control; in July Guangzhou "Cough C Ballroom" mall fast flash shops to place the experience of entering the environment nearly a million times, a single day of interaction.
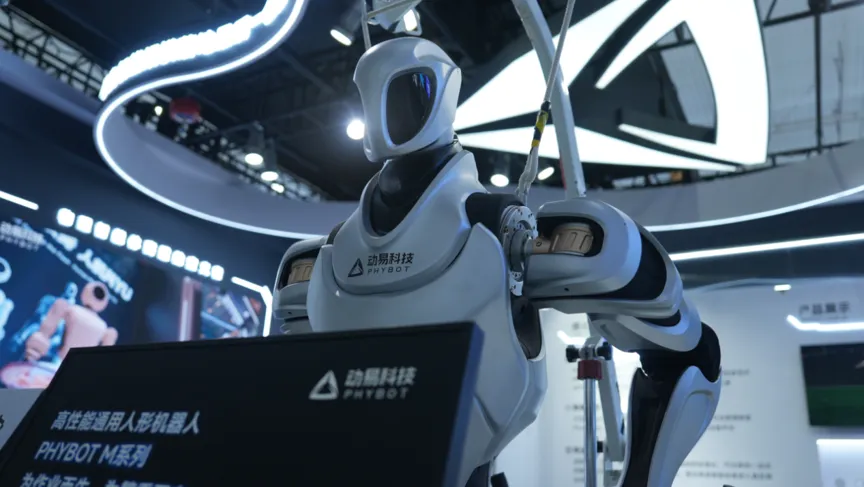
M series: 180cm/75kg) is a full-sized heavy electrically powered humanoid robot, which has been shown to be able to turn on and off in a man-made manner. The D-series integrated four-legged D1 machine weighs 130kg, has been officially designated as having a normal dynamic load of 210kg, a static load limit of up to 500kg; it can climb 45° slopes in the exhibition demonstration, crossing 85cm high ceilings, adjusting the dynamics in real time to its gravity and dynamics in the ruins, crumbling complex terrain.
At this WRC, the cross-section of the "World Model Edge Siderization, Unified Timing with Operating Control Systems", which is reflected on the side of the ball, by the side of the teapot, by the transmission belt and in front of the rotating workstation, the naming syntax of the various technical packages is different, but the direction is the same: the upper half of the brain and brain of the generation with physical intelligence, the second half must be combined, the world model can not only be hung in the cloud, sink to the side of the end, share the same timing signal with the underlying operating control.
02.
What is it that the factory is waiting for?
In today's mature process scenarios, the repetitive positioning of the single-piece robot itself, the precision of movement that basically meets production needs, really slow down the production line landing, the pain points that restrict mass production efficiency, and more focus on the synchronization of time between multiple processes, multiple devices.
The real working conditions of the isolated manufacture are not single-station screws. A station is finished, the transmission band on the container, B station takes parts, there is a caching point in the middle, rhythm fluctuations, the position of the workpiece is drifting, unusual parking.
This year's showcase is a two-piece disassembly and reassembly workstation: two rotary F1 turbocharged turbocharged turbocharged turbocharged turbocharged turbocharged turbocharged turbocharged turbocharged turbocharged turbocharged turbocharged turbocharged turbocharged turbocharged turbocharged turbocharged turbocharged turbocharged.
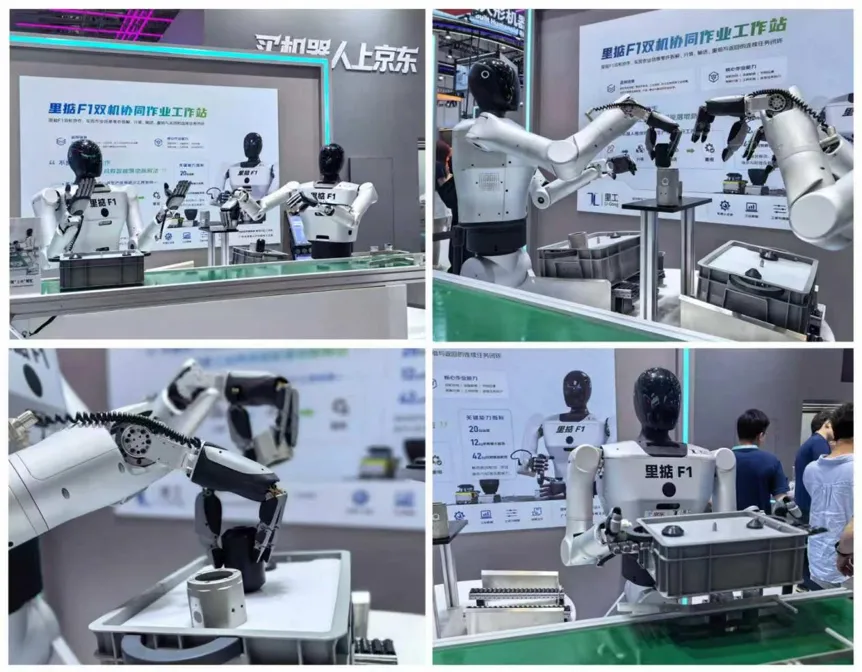
The workstations are built around typical industrial task logic and provide a stable operating cycle based on the logic of replicating real-life production lines. The core challenges of the project are not only the accuracy of mechanical arm movement, but also the ability to simultaneously coordinate multi-device coordination. The program focuses on verifying the task division of the F1 in two hands, the inter-machine synchronization of man-made procedures, and the deep process connectivity of humanoid robots with peripheral automation devices such as transmission belts, rotating workstations, solving the problem of isolating industrial multi-device collaboration, and the problem of coordinated landing.
The demonstration program of the factory corresponds to the real need for production, manufacture and maintenance of pumps in real-world training special operations: robots no longer stay in the pumps in the laboratory, but enter the factory to open the pumps, really integrate people, machines, the environment, collaborate in real working conditions, share timing, deal with anomalies, and continue to operate steadily.
In WRC 2026, the company moved the production line of the factory 1:1 to the progress stage, and the 5W excavator dismantled the boxes, the boxes were moved, the small parts were loaded, the axles were rotated for 8 to 10 hours at three locations, and the boxes were distorted by the calibration, without remote control and without engineers.
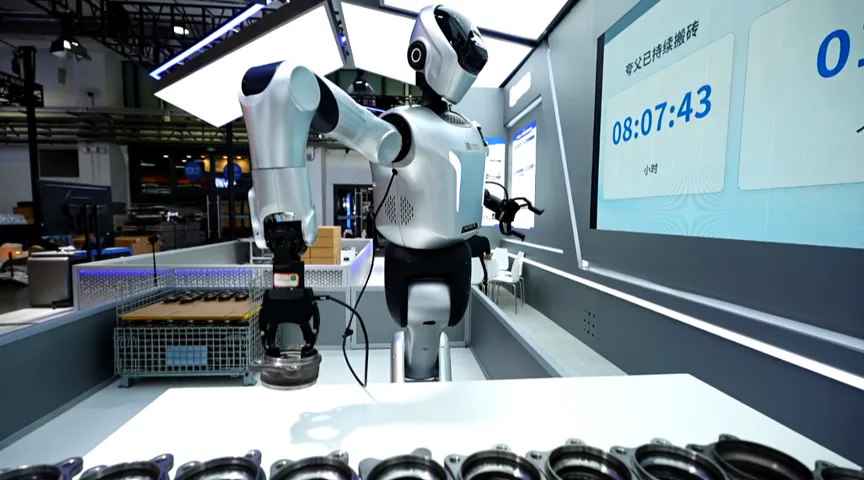
It doesn't tell an architectural story, runs the Taskor graphical layout, the production line engineers don't write code, the unit deployment goes from months to hours, the new skills run for 3 to 7 days.
In addition to Lithium, there is another volume: mass production itself reduces the chain of code tools, replacing single-stage processes in factories that can simultaneously compress the deployment cycle and repurchase orders, and calculate the purchase price.
At the Vietnamese stand, what really catches the eye is not a single robotic craft, but a set of body-smart platforms called Brainstorming Brainstorming Brainstorming Brainstorming Brainstorming Brainstorming Brainstorming Brainstorming Brainstorming Brainstorming Brainstorming Brainstorming Brainstorming Brainstorming Brainstorming Brainstorming Brainstorming Brainstorming Brainstorming Brainstorming Brainstorming Brainstorming Brainstorming Brainstorming Brainstorming Brainstorming Brainstorming Brainstorming Brainstorming Brainstorming Brainstorming Brainstorming Brainstorming Brainstorming Brainstorming Brainstorming Brainstorming Brainstorming Brainstorming Brainstorms Brainstorming Brainstorming Brainstorming Brainstorming Brainstorming Brainstorming Brainstorming Brainstorming Brainstorming Brainstorming Brainstorming Brainstorming Brainstorming Brainstorming Brainstorming Brainstorming Brainstorming Brainstorming Brainstorming Brainstorming Brainstorming Brainstorming Brainstorming Brainstorming Brainstorming Brainstorming Brainstorming Brainstorming Brainstorming Brainstorming Brainstorming Brainstorming Brainstorming Brainstorming Brainstorming Brainstorming Brainstorming Brainstorming Brainstorming Brainstorming Brainstorming Brainstorming Brainstorming Brainstorming Brainstorming Brainstorming Brainstorming Brainstorming Brainstorming Brainstorming Brainstorming Brainstorming Brainstorming Brainstorming Brainstorming Brainstorming Brainstorming Brainstorming Brainstorming Brainstorming Brainstorming Brainstorming Brainstorming Brainstorming Brainstorming Brainstorming Brainstorming Brainstorming Brainstorming Brainstorming Brainstorming Brainstorming Brainstorming Brainstorming Brainstorming Brainstorming Brainstorming Brainstorming Brainstorming Brainstor
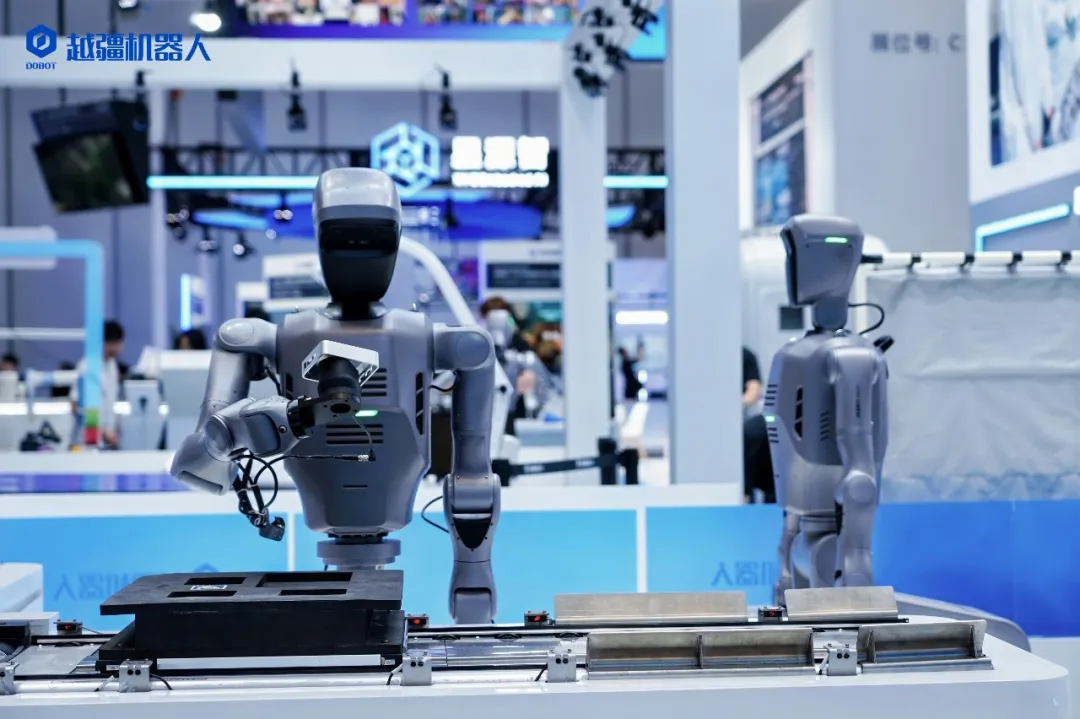
Multi-brain welding broke the boundaries of traditional robotic welding, allowing intelligence to move freely between different forms of bodies, significantly reducing the barrier to scene adaptation. Vietnam is not making a smarter machine, but building an intelligent foundation that can quickly replicate and generalize to multiple physical carriers. Whether industrial, home or travel, the same brain can flexibly command different brains, which is the key to a smart move to scale commerce.
HumanGPT is responsible for synthesizing the hands-on experience of workshop teachers, distilling it into a standardized multi-modal industrial knowledge base; large data platforms open up data collection, cleaning, labeling, training processes; inkblind IDE provides low-code drag to quickly generate robot work skills; Openmind OS is downstream compatible with all types of hardware devices and upstream business applications.
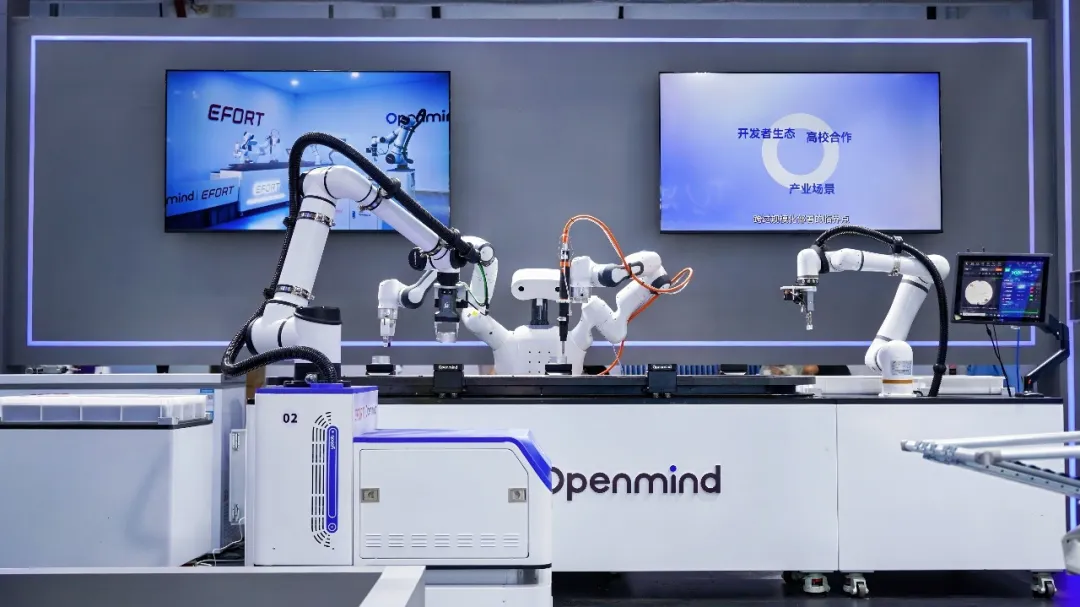
At the real-world level, intelligent welding relies on 3D visual automatic identification, online generation of motion paths, without the need for artificial complicated demonstrations, is a key to start operations; intelligent spraying is just to put into the workpiece, through point cloud modeling, large model generation of motion trajectories, simulation of micro-production; EXR series anti-explosion robots have positive pressure anti-explosion, IP65 level of protection, suitable for chemical, military, and civilian high-risk scenarios.
Superimposed composite robots and line-by-line warehouses SPS sorting chips have been produced in a host plant, hundreds of parts 3D recognition crawled, never expected to be connected to a closed loop.
Single precision dividends are converging, and the process-level closure is becoming an essential part of the industrial process.
03.
Why is it so hard to make tea, to make pizza, to arrange bed sheets, and to do all these "uncool" things?
The biggest problem in the last three years on the server robot circuit is that the more beautiful the video, the more awkward the landing. The robot makes a cup of tea, changes the shape of the cup, changes the height of the stage, and changes the accent.
URICH (UniXAI, Chile) presented six scenes of robot bands, industrial teas, watercolours, pizzas, hotel rooms, family breakfasts, the basement of the same set of three sets, UniCortex Long Task Reasoning, UniFlex mini-sampling, UniTouch visual touch fusion. It is worth noting that the "tea bubble is not good", but that the same set can be transferred from entertainment to dining to the living room: the tea bubble can be transferred in eight steps to the changing type of kettle, the nine-step cross-device process can be transferred to the kitchen, and the watercolour continuous pen control can be transferred to the graphite spray.
Along the same lines, the company's quest for intelligence goes the other way: long-distance reasoning + multi-crew teams. Moz1 on WAIC with Spirit v1.6 does "clean up the living room" for Coca-Cola locations, dirty bowls into dishwashers, paper troops interfere with re-planning routes; Moz2 amygdala body positioning commercial clothing. The WRC we see is a dual-plane show, focused not on two machines, but on the division of tasks in complex service tasks: a perceptual planning, a detailed operation, and real-time synchronization between the two.
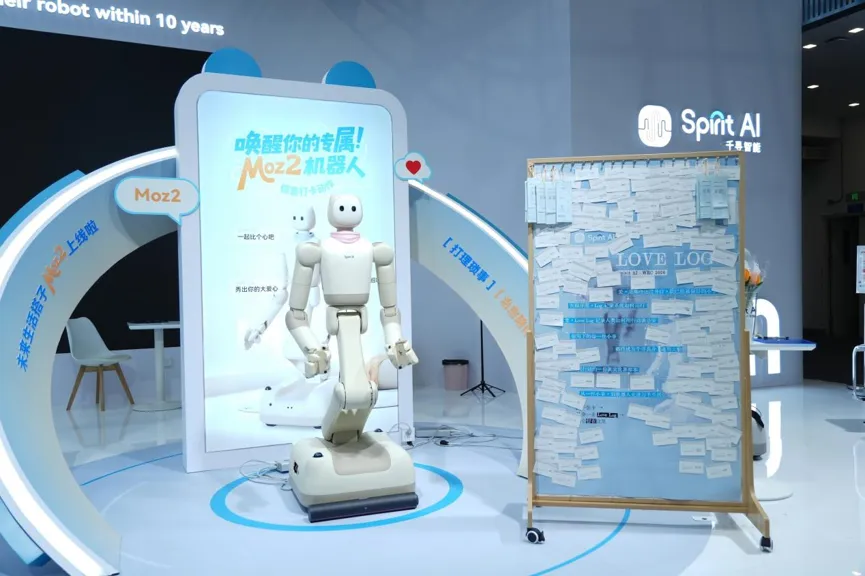
This is exactly the prelude to the "job" moving from the single to the classroom, the service robot used to work in the "single" and the next step was in the "how to connect to the context", and the reasoning chain of the Spirit was opened to the viewer, closer to the classroom structure of the real front desk/room than the single cup of tea.
The first human-powered Vbot (C-Pale C108) ATOM made its first public appearance at the WRC. The core team is equipped with an automotive and autonomous driving background that brings safety, reliability and engineering closure into the living space. The AI carrier machine dog "Big Head" first sold 6,540 units and achieved mass production delivery in May 2026, currently the first consumer-grade human-powered smart terminal; 1.266 million large model interactions, 131,500 hours of escort and three to four month OTAs, allowing Vbot to run-to-scale deliveries, real use and continuous generation of consumer terminals.
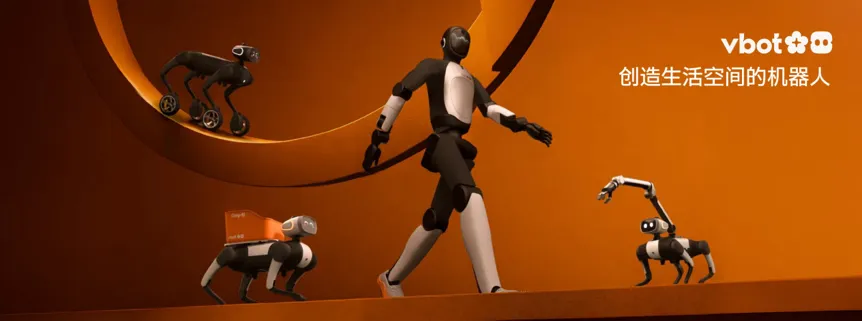
ATOM shares four-legged products with the Vbot Embodied Genome, a genome embodied body model system, with life-service tasks such as Vbot-OmniDuplex, Vbot-WorldModel, Vbot-EvoMorph, three core models that connect continuous interaction, future deployment and cross-body evolution.
Consumer level means that the cost structure, safety redundancy, and interaction paradigms are all recalculated, not from the industrial man-made reduction of prices, but from the definition of real users and long-term service reversal of products. Unlike the path cut from the laboratory prototype or commercial scene, Vbot starts from a verified four-legged consumer terminal, extending the quantity of product delivery, user operation and OTA closure to man-made materials.
04.
What is it that interactive intelligence solves when you walk into a bank, when you're a hall manager, when you're a progressionist, when you're a lecturer?
Before the human form entered the family, there was a problem that had long been covered up by the narrative of the movement: entering the door, not staying.
Bank halls, exhibition halls, and nursing homes spend eight hours a day working tirelessly to figure out who they are, remember where they last spoke, don't line up, don't talk.
EIR is a few interactive intelligent routes in the country. The ELA model, runtime-level unified ordering of perception, memory, roles, navigation, operation control, the same machine entering the bank is the hall manager, the progress hall is the lecturer.
It is involved in the operation of the Sichuan Provincial Human Robotics Training Ground B, real-time interaction failure, user disruption, artificial adoption data backflow counterfeiting the ELA model, scene entrance plus training ground closures, a combination of infrastructure that allows the interaction route to run. According to the idea of EIR's desktop machine product, open-ended interaction heads dismantle digital faces and sell them separately, and enterprises take their own models and IP chips into the family early, allowing digital employees to access the scene data.
But the final collapse of the interaction retention rate is often not verbal, but hand. The character sense is stabilized, the last few centimeters "pass the document to the person, pass the glass of water is confiscated", the user feeling instantly from "a character is" to "the machine hand is too hard".
This is the location of the TS-F series full-hand sensor module, TS-ECHO touch sensing fingerprint kit, TS-EST multi-modal electronic skin, equipped with advanced touch chips for signal front-end processing, which is the "power perception layer" on the hands of interactive robots. In sports routes, touch resolves "don't pinch", "don't hit", "slide", that's safety redundancy; in the service interaction scenario, touch resolves another thing: the time of touch.
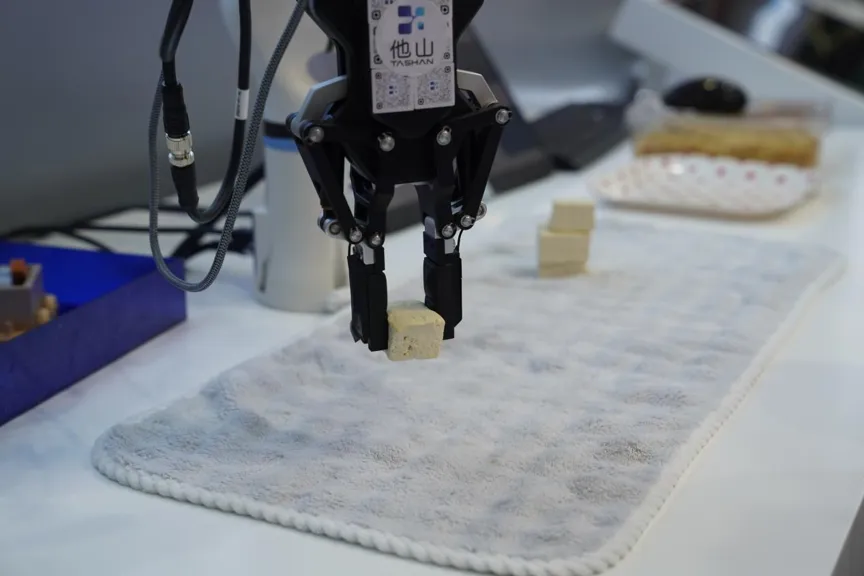
The basic unit visual module is now wrapped up in the one-hundred-degree area, but the need for service interaction touch still faces challenges such as precision drift, service life, and data consistency. Large-area flexible touch suite integrated BOM cost overruns, labeled processes are crowded, batch efficiency fluctuates greatly, many integrated machine manufacturers simplify touch locks at the showroom demonstration stage, using only visual estimates of touch power, which is also the main reason that on the safe stand robots can only pass water cups, pass documents can only move slowly, fixed trajectory, reserve 20 cm distance.
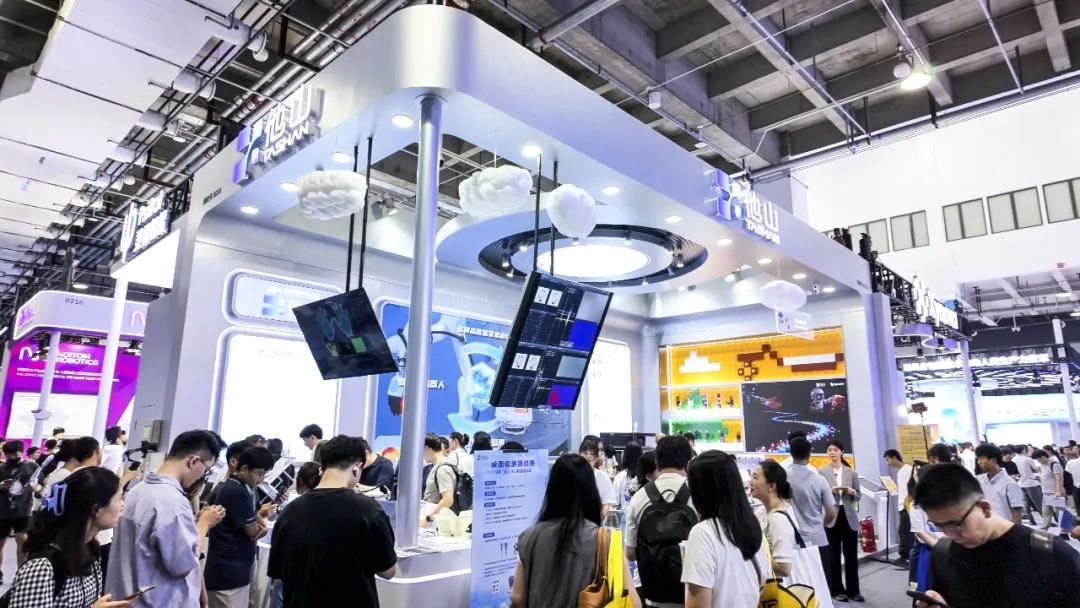
At the peak of the banking hall, when the nursing home workers are not around, without touching the closed loop, the interactive robot hand reaches out is the retention rate cliff.
The retention rate of service scenes does not come from the upper limits of movement, but from the lower limits of interaction, from character memory, digital faces, to the last few centimetres of the hand.
05.
Why is it "not like people" to actually run out of repurchase orders?
If you look at the list of purchases of electricity, fire, park inspection special scenes, you will find that the main purchasing power at this stage is still four-legged, wheel-legged models, man-made robots are restricted by geographical adaptation, designated costs, and the volume of purchases is temporarily behind.
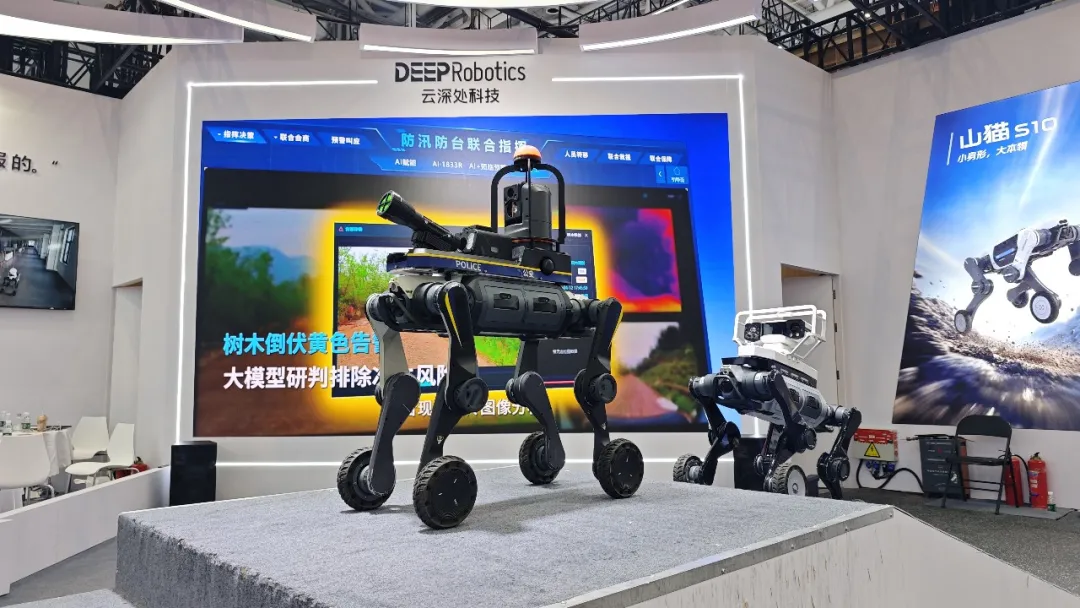
In the depths of the clouds (C220) "One Cat, One Dog" matrix is once again presented at the WRC site. Why did four feet in the turning power station be laid before the mannequin?
The acquisition was not "like a person", but "in the middle of the night, after 30 intervals, data feedback, no one enters".
As opposed to competing around single-body formats, Samsung emphasizes the combination of mobile and operational capabilities: university research can quickly build mobile robotics platforms based on standardized dashboards, and industry customers can also operate with flexible integration for logistics, routing, and other tasks.
This corresponds to the trend of physical intelligence shifting from a single body shaft to a rigid platforming capability. Once robots enter the real world, the problem needs to be solved not only with the ability to move, but also with the rapid synergy of mobile, perceptual, operational and upper-level algorithms. The platform is no longer just a walking institution, but an important foundation platform for connecting different capabilities to application scenarios.
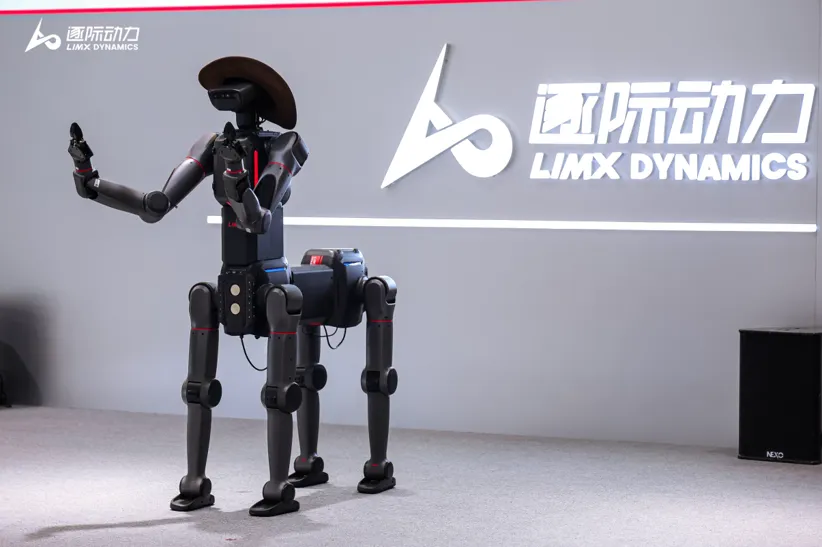
On the human body side, the intermodal dynamic humanoid robot Oli, Luna, parallel to the TRON series dual-line. In the exhibition space, the intermodal dynamic embodied the humanoid brain system, Oli incarnated as a cyborg host, chatting with the audience and answering questions, and even dancing in hot spots, also using English, Korean, French, Japanese and other multilingual communication, mainly demonstrating the ability of System 2 (cognitive) to communicate autonomously at the same time; TRON 2 via fully autonomous VLA operations to deliver sugar to the audience, mainly demonstrating the ability of System 1 (playing skills); relying on the WBT model, Oli demonstrated the same basic body embodiment as the actors currently performing: fast-moving arms, twisted shoulders, deep dance sequences, etc.
Intelligent Technology is making its debut at the WRC this year, and it's really trying to make people understand not just which four-legged robot they're releasing, but how their capabilities extend from one layer to another, once the core of all-electric technology matures.
From the joint modules, the sensing control unit, to the ZSD end-to-end navigation big model, the Intelligent Technology firmly self-developed and started to eat the bottom of the bottom. Then, the four-legged robot became the first mass-produced drop-off point in the bottom of the set, which is more human-friendly in terms of geospatial adaptation and labeling costs, allowing the scene data to turn first.
When the three key issues of power aggregation, mass production supply chain, and scene closure were run by quadriplegic robots one by one, the same base began to grow into more form: on the one hand, the humanoid robot Intelligent Ne01, achieving full-body coordination; on the other hand, the brake platform Intelligent Copper M1 with a mechanical arm Intelligent Iron Arm TA01, landing VLA.
With more than 300 ecological partners, it has expanded into a variety of mature applications, such as ground security, emergency, electricity, and other core industries, covering more than 100 provinces and cities across the country.
06.
This year's World Robot Congress, how are you going to win this exhibition?
The five lines are intertwined, and WRC 2026 isn't really about "being unlike humans, not being able to turn around", it's about the same thing: from one-point action to the complete mission closure, who actually ran away.
At this year's World Robotics Congress, it is recommended that you do not rush to the largest stand of human beings. See who has a conveyor belt, a rotary table, an oven, a ball table, a mattress, a teapot, real workplace props, and the engineers do not use a remote control, robots run themselves for more than half an hour, which is the thing to worry about this year.
The video was shot three months ago. This year, we are all about how to do the whole thing in the physical world without interruption.