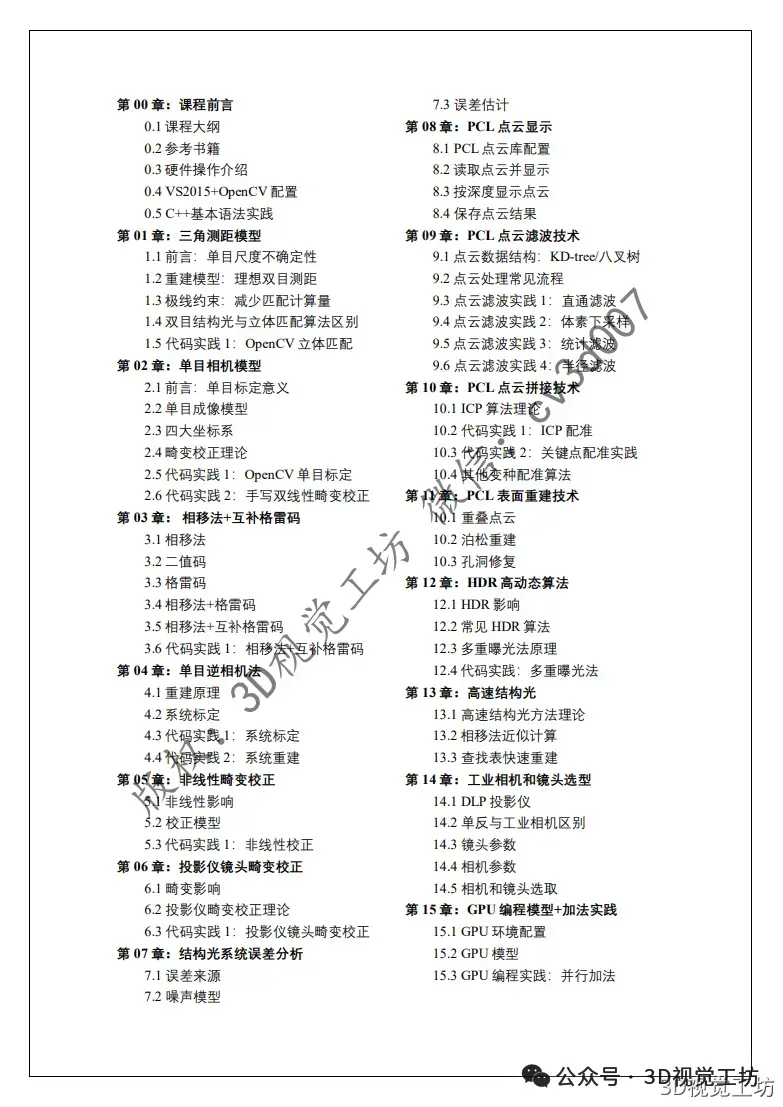
A product introduction
3D structural light is mainly aimed at the three-dimensional reconstruction of dimensional reflected silicon objects, often used in the field of mechanical arm grabbing, visual measurement, fault detection, etc. Currently, the mainstream structural light technology is: scattered structural light, robot navigation, linear structural light, visual measurement, surface structural light, and other rapid measurement scenarios.
NOTE: In addition to the Xenophon series, we also have scientific-grade devices for providing source code and courses, such as scientific-grade double-blind spot, phase deformation, and double-blind scan.
The following are some of the products we have launched in the "Express" series:
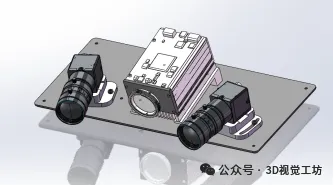
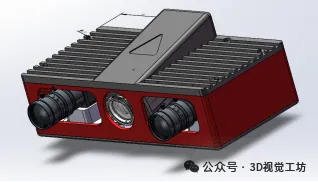
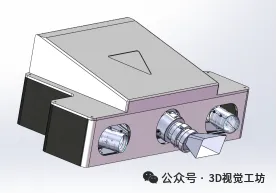
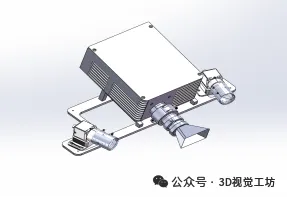
Chart of facts
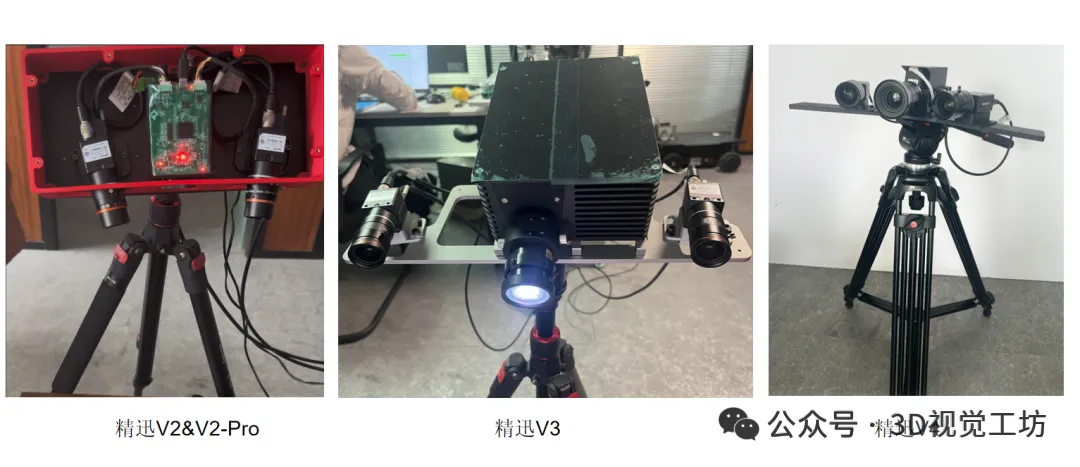
Hardware/software differences between them:
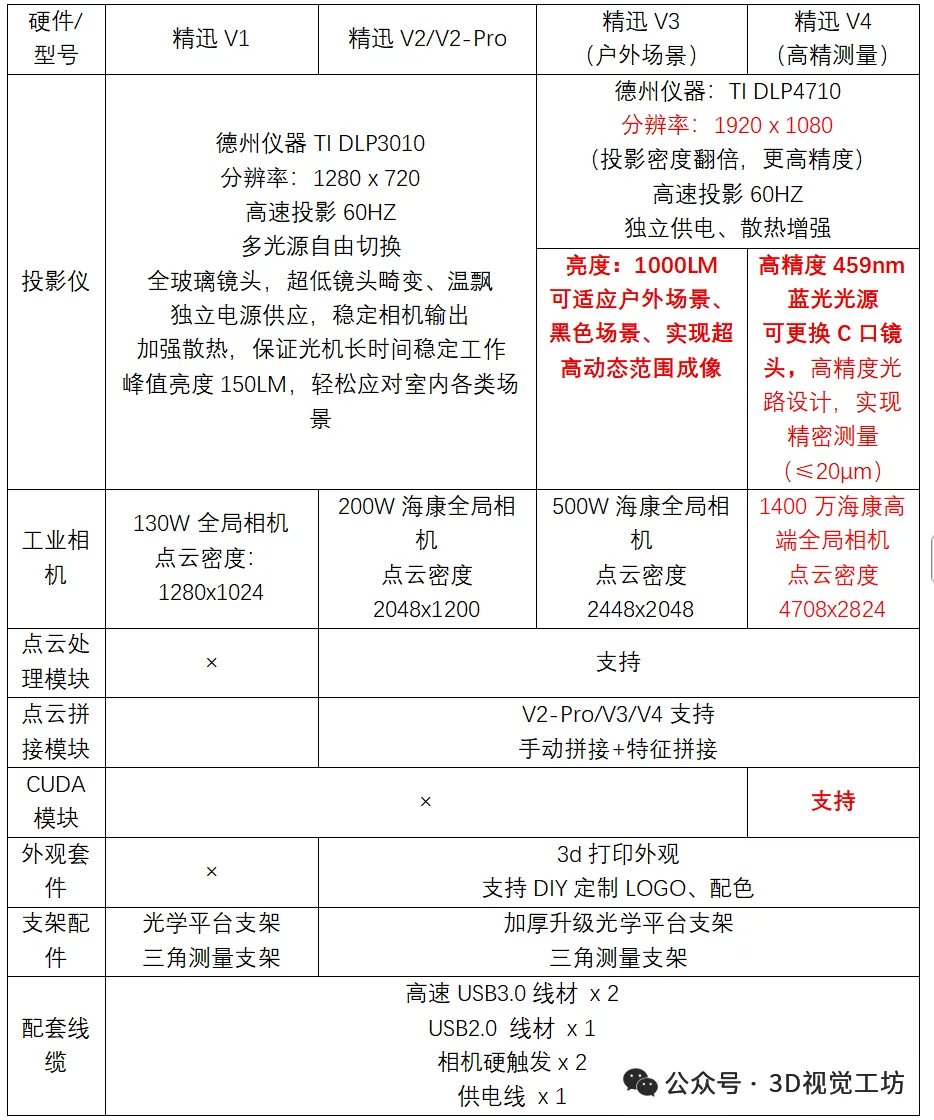
In a nutshell:
Fast forward to V1.: DLP3010 optical machine, with complete single/double-targeting, rebuilding functionality, suitable for learning structural light three-dimensional rebuilding, PCL point cloud processing courses.
V2 and V2 ProUsing the DLP3010 optical machine, the interface is highly optimized, one-key reconstruction, point cloud filtering, display, visual guidance, and measurement of scenes. It is very convenient to develop its own application under this code set.
Fast forward to V3Using the DLP4710 light machine, higher resolution, supporting strip writing, maximum brightness of 1000LM, no fear of outdoor and black scenes, suitable for large-scale scenes, but weighing more than 4 kg, suitable for out-of-hand visual guidance scenes.
Fantastic V4The camera uses DLP4710 optical machine, which can replace any focal point C lens, excellent linearity, passive copper tube heat dissipation to avoid heat drift, vibration, and other effects. The camera uses a high-end 14 million-pixel full-frame camera from Heikong, rebuilding rich details.
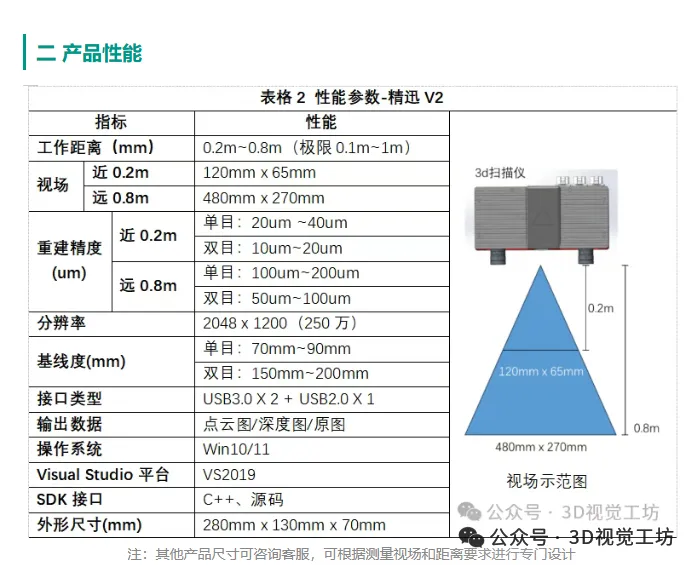
2 Product performance
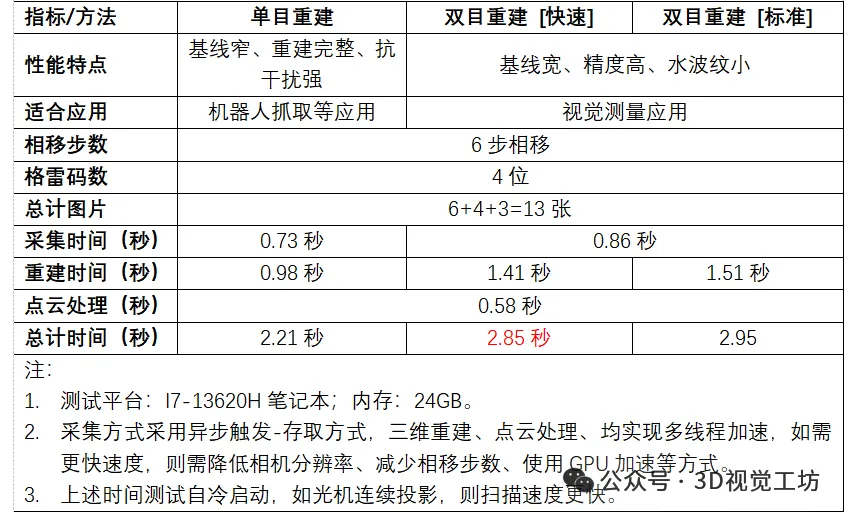
Rebuilds are time-consuming (Extended V2, CPU version) (One-time projection at 30 FPS with a maximum projection at 60 FPS):
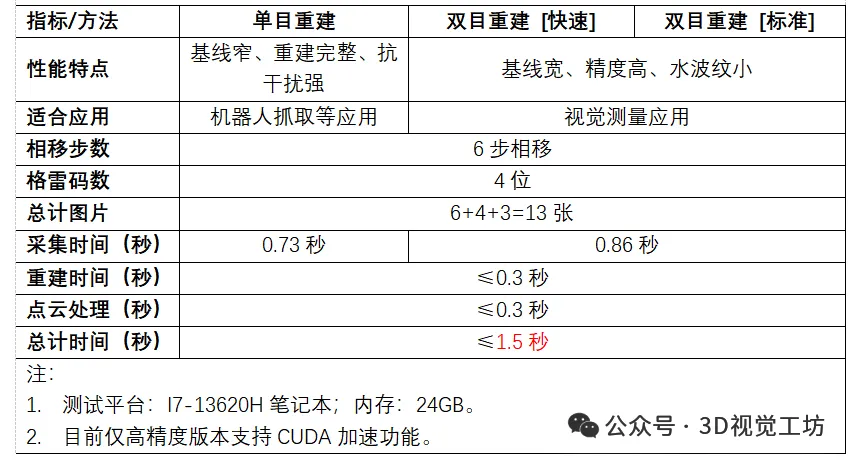
Rebuilds are time-consuming (GPU version) (one-off projection at 30 FPS with a maximum of 60 FPS):
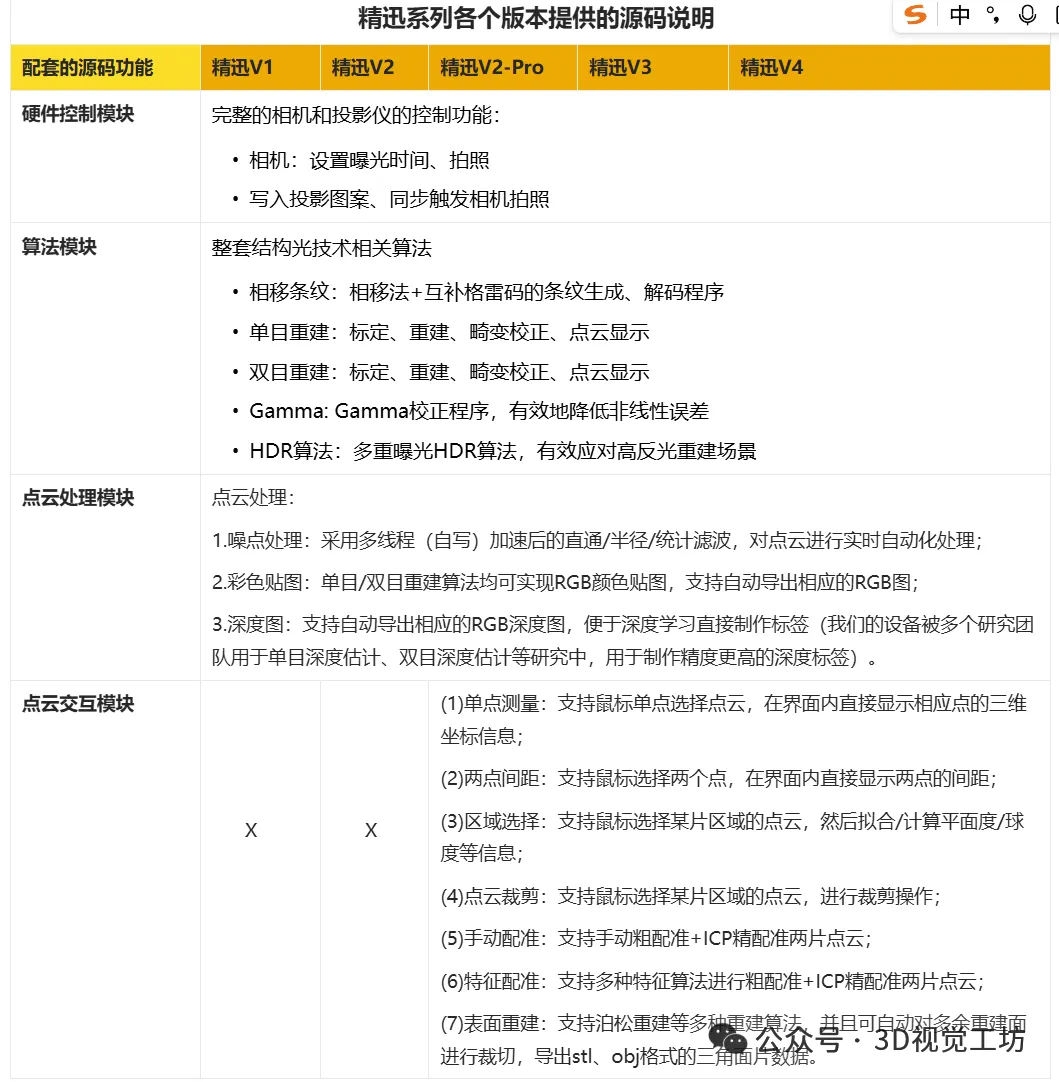
3 Source modules provided by V1 to V4
4 Software introduction
The demo upgrades to demonstrate QT development are as follows:
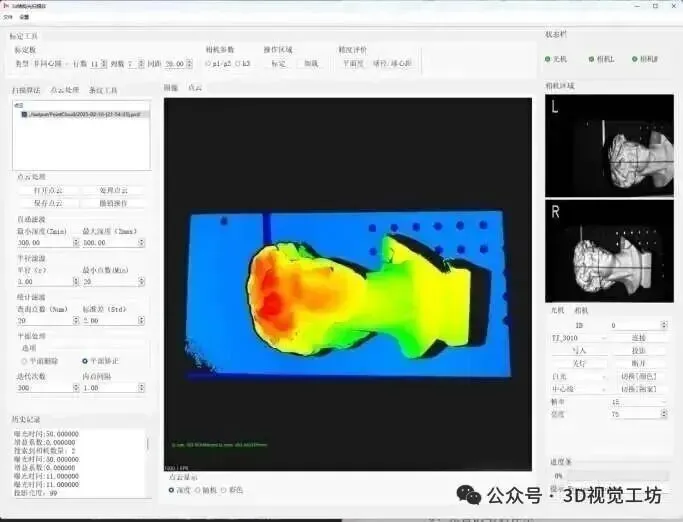
Compared to the fastest V1, the main improvements are as follows:
Interface upgrades: Hardware control, system labeling, three-dimensional reconstruction integrated into an interface that is easier to use.
Point-cloud processing: can manually set filter parameters, automate point-cloud processing, and can interact with point-clouding, cutting, and surface reconstruction algorithms.Spelling algorithms for dot cloud features。
Higher accuracy: The camera's resolution is upgraded to 2 million (up to support 14 million pixels) and single-target rebuilding algorithms with higher accuracy are used to significantly improve single-target rebuilding accuracy.
HDR algorithm: Optimizes HDR high dynamic synthesis algorithms to easily respond to most measurement scenarios such as high dynamic range (aluminum alloy, black background).
Expanded: Open source, supporting secondary development of mainstream machine vision libraries such as OpenCV, Halcon, and VisionMaster.
AI development: can be combined with OpenCV deployment of all types of AI applications, such as 6D gesture crawling, and can be combined with our workshop launch courses to complete most tasks in the field of 3D vision.
Starting from scratch, source-level teaching! will take you from zero to complete professional development training with basic 3D visual knowledge such as scoring, rebuilding, QT, PCL etc.
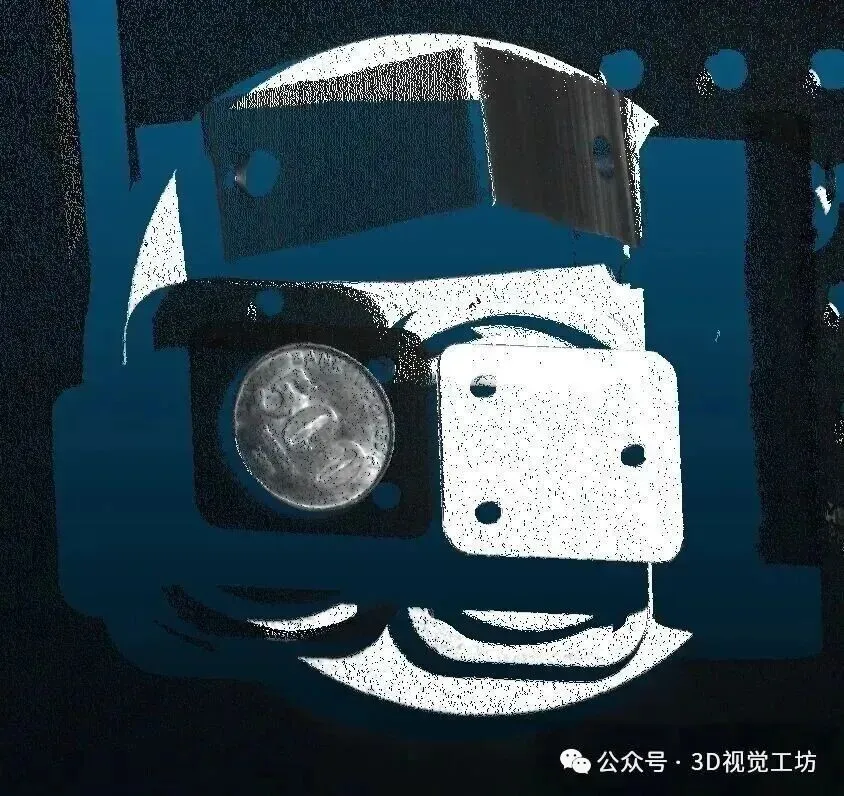
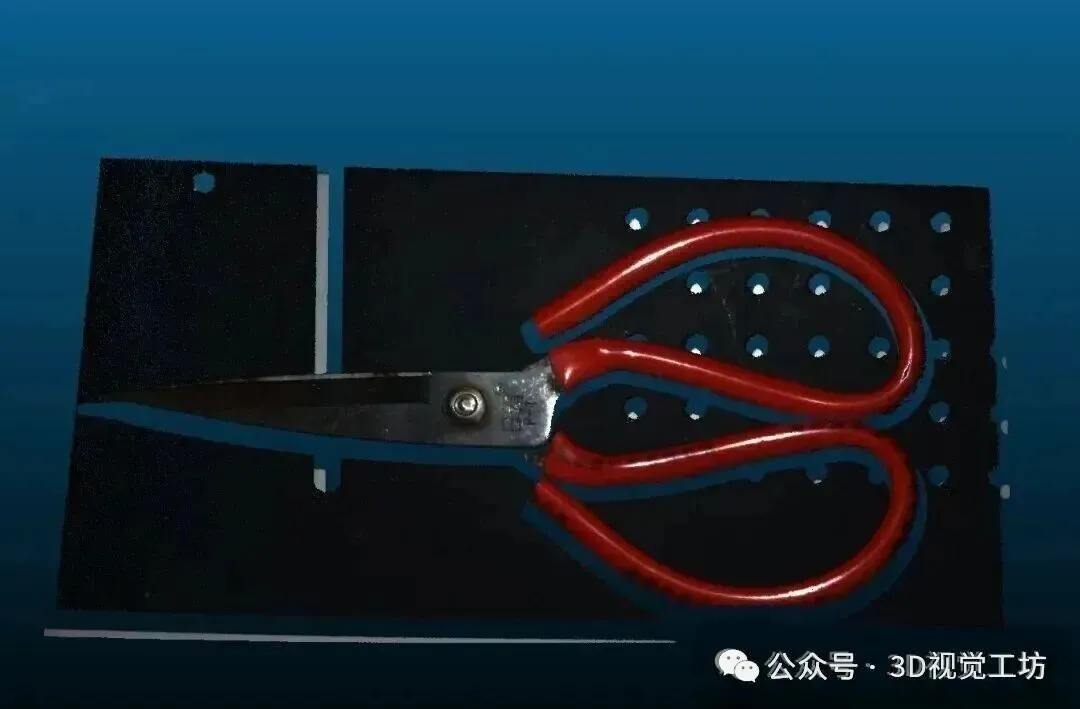
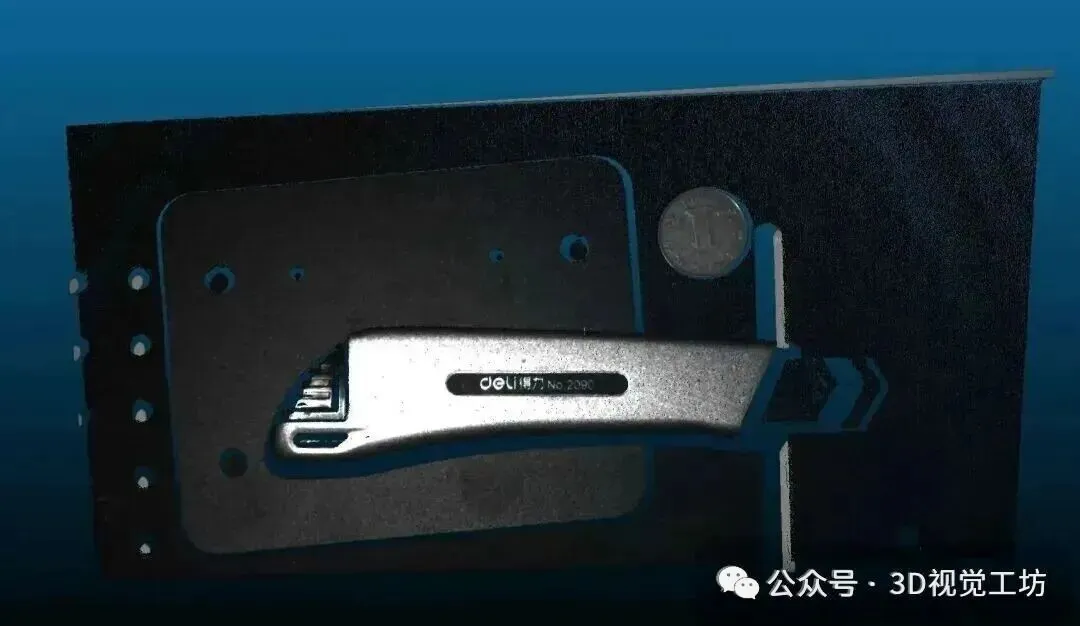
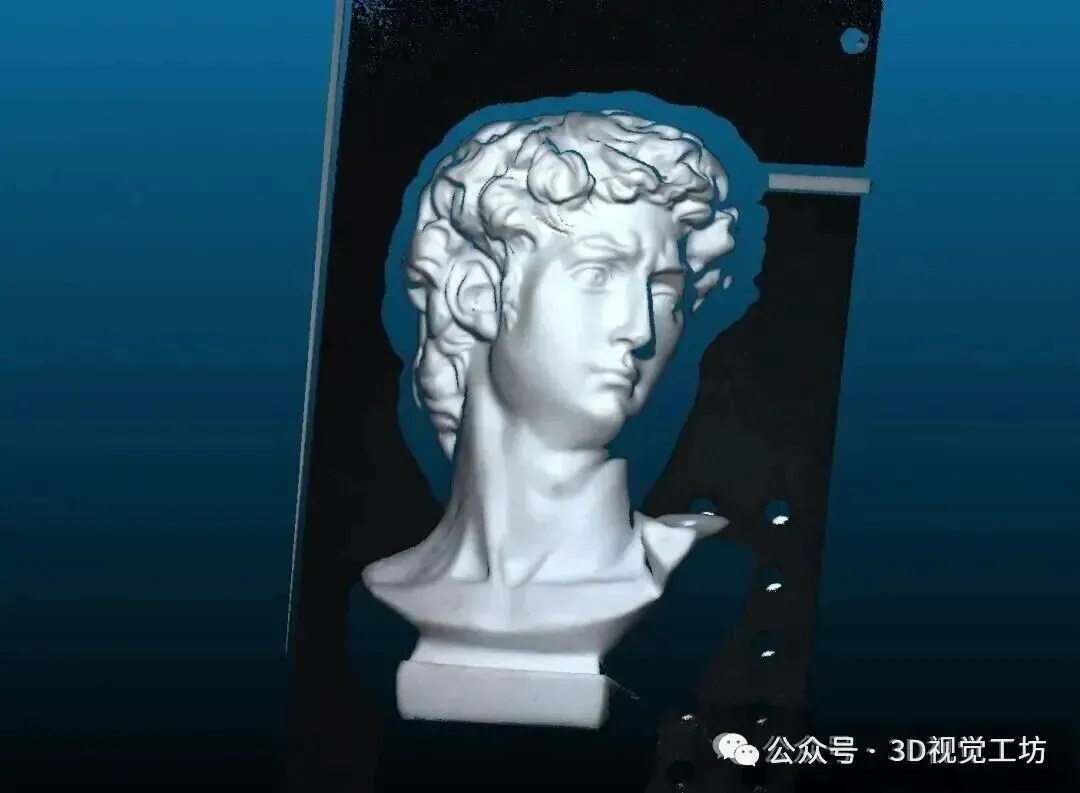
5 Measurement Effects
Actual measurement scenes
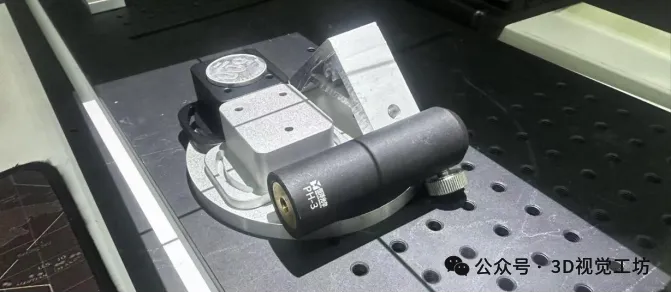
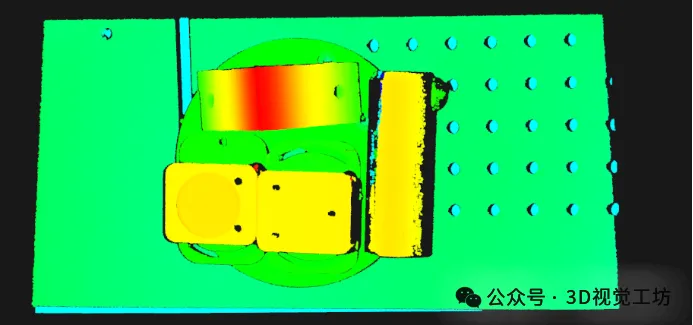
The Rebuilding Effect of Point Cloud
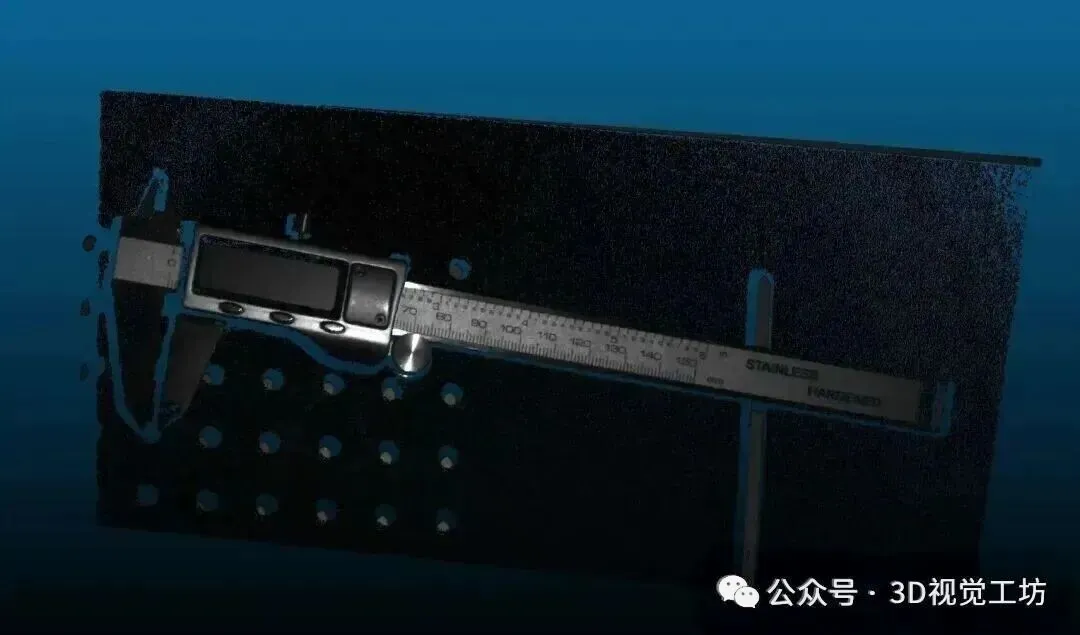
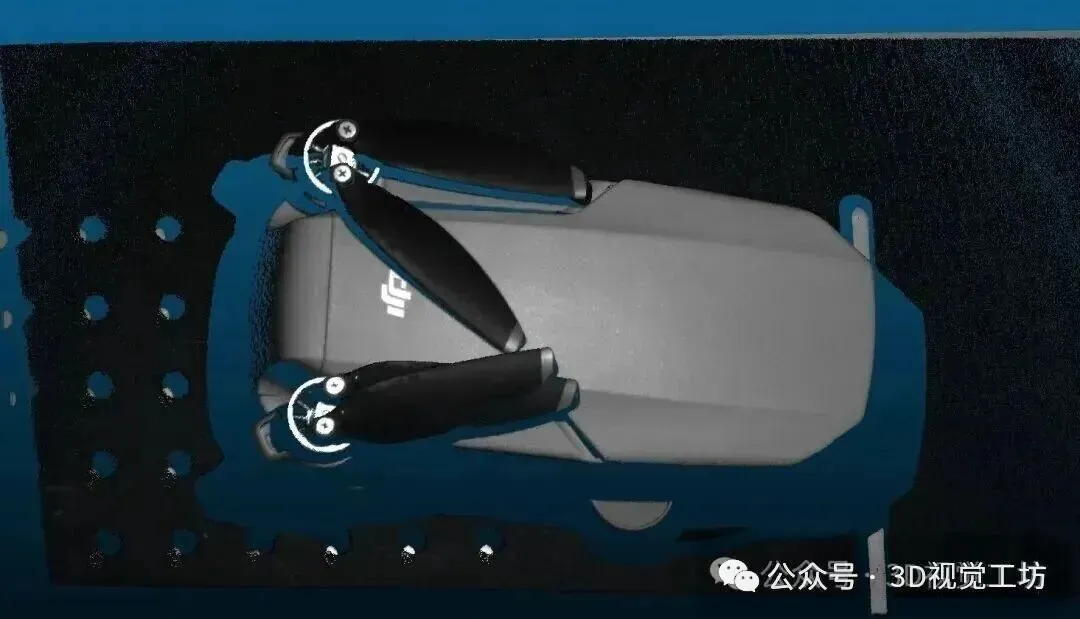
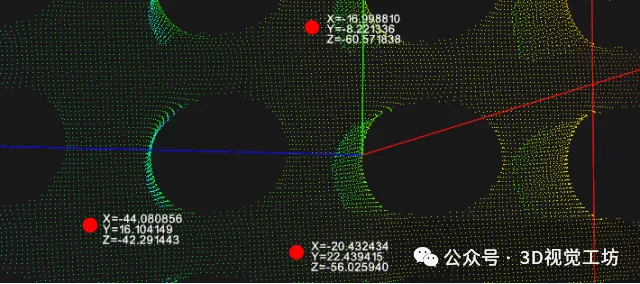
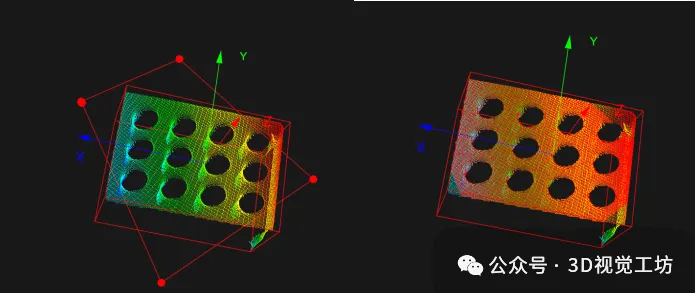
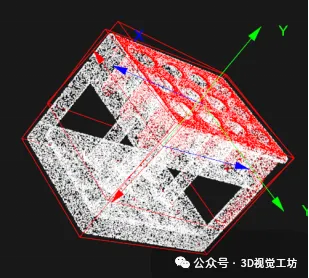
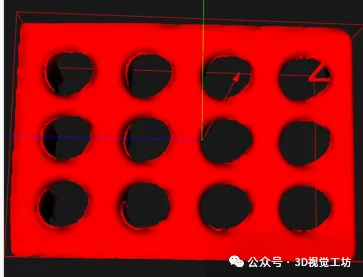
6 High-level functions
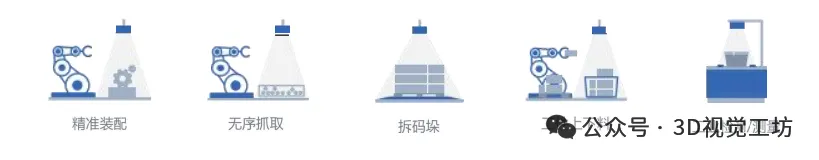
7 Application Scenes
If you buy this set of hardware, which courses will be supported by donations?
8.1 Lesson 1: Structural Light 3D Reconstruction of High Class Special Video Lessons + Lessons