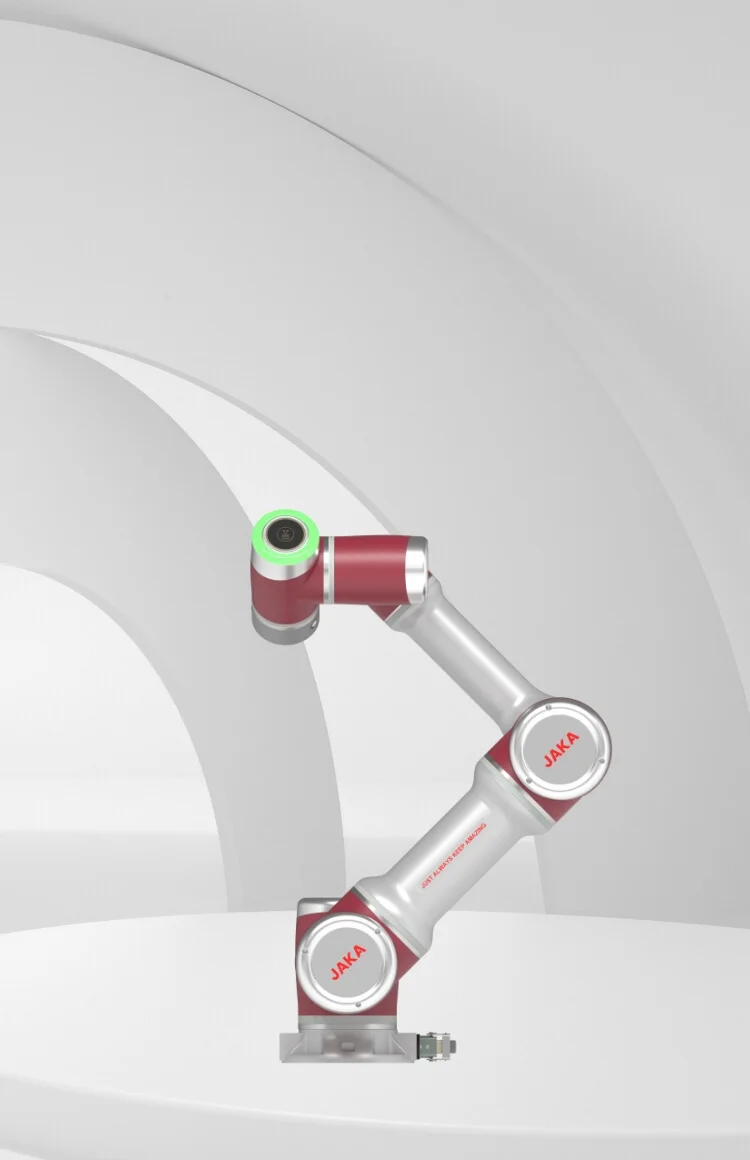
Overview
Six-axis collaborative robot arm with 7 kg payload, 819 mm reach, ±0.02 mm repeatability and 22 kg weight including cables. Manufacturer documentation describes built-in torque feedback and collision detection.
Product description
Six-axis collaborative robot arm with 7 kg payload, 819 mm reach, ±0.02 mm repeatability and 22 kg weight including cables. Manufacturer documentation describes built-in torque feedback and collision detection.
Technical specifications
| Product model | Zu7 |
|---|---|
| Degrees of freedom | 6 axes |
| Rated payload | 7 kg |
| Reach | 819 mm |
| Repeatability | ±0.02 mm |
| Power and force limiting | yes |
| Hand guiding | yes |
| Safety functions | power_force_limit |
| Ingress protection | IP54 |
| Communication protocol | Modbus_TCP|PROFINET|EtherNet_IP |
| Weight | 22 kg |
| Programming method | graphical|drag_to_teach|offline_programming |
| Collaborative mode | power_force_limiting|hand_guiding |
Additional manufacturer specifications
Official product page: typical power consumption 350 W; power supply 100–240 VAC, 50–60 Hz; tool I/O 2 DI/2 DO/2 AI; controller I/O 16 DI/16 DO/2 AI or AO; base diameter 158 mm. The page lists 410×307×235 mm and 15.4 kg in a separate basic-parameter block, so these are not assigned to the robot arm. Robot-arm weight is 22 kg incl. cables. The page lists IP54 and a separate IP44 rating; IP54 is recorded for the arm. Safety manual documents joint torque/power limits and TCP force limit.
Official sources: https://www.jaka.com/en_eu/productDetails/JAKA%20Zu7; JAKA safety manual.