Product description
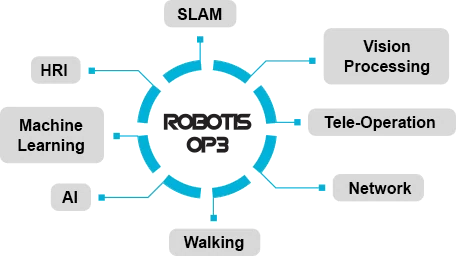
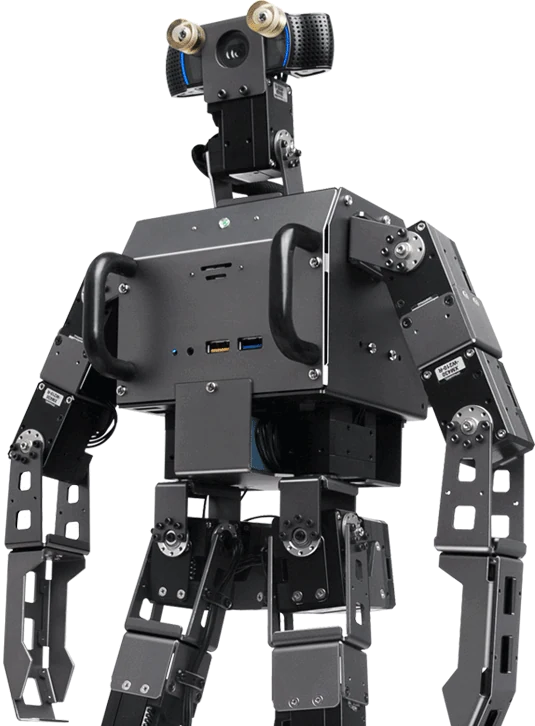
The ROBOTIS OP3 is a compact, open humanoid robot platform for research and education. The official English documentation lists a 20-DOF configuration, XM430-W350-R actuators, an Intel NUC i3 computer and an OpenCR sub-controller. The platform supports C++, ROS 2 and the DYNAMIXEL SDK. The current e-Manual specification lists an approximately 510 mm height, approximately 3.5 kg weight without the skin cover, a Logitech C920 webcam, a nine-axis IMU and a 3-cell 11.1 V, 3300 mAh battery. Battery capacity is shown as the e-Manual's current specification; older product-page revisions list a different battery configuration.
Manufacturer product page: https://en.robotis.com/model/page.php?co_id=prd_op3
English technical documentation: https://emanual.robotis.com/docs/en/platform/op3/introduction/
Manufacturer category: DYNAMIXEL SYSTEM / ROBOTIS OP
Specifications
| Product model | OP3 |
|---|---|
| Overall height | Approx. 510 mm |
| Robot weight | Approx. 3.5 kg (without skin cover) |
| Degrees of freedom | 20 |
| Perception sensors | RGB_camera|IMU |
| Communication protocol | ROS2 |
| Software and SDK | cplusplus_sdk|ros2_driver |
| Battery energy | 36.63 Wh (calculated from 11.1 V × 3.3 Ah; source specifies 3-cell 11.1 V, 3300 mAh) |
| Technical extension parameters | Joint layout: 6 DOF per leg × 2, 3 DOF per arm × 2, and 2 DOF neck; 20 actuator modules total. Actuator: DYNAMIXEL XM430-W350-R. Main computer: Intel NUC Core i3, 8 GB DDR4 2666 MHz, 250 GB M.2 SSD. Sub-controller: OpenCR. Camera: Logitech C920 HD Pro Webcam. IMU: 3-axis gyroscope, 3-axis accelerometer, and 3-axis magnetometer. Battery: 3-cell 11.1 V, 3300 mAh. Development: C++, ROS 2, DYNAMIXEL SDK. |