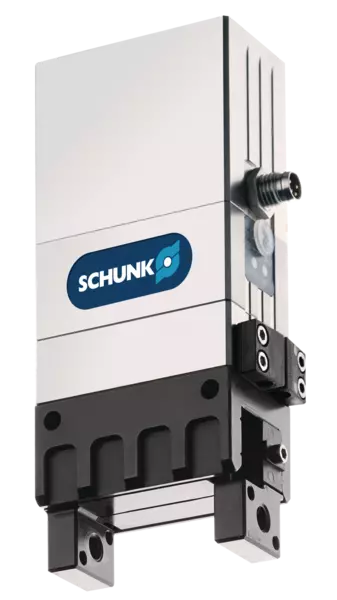
Listing typeSupply Product
Record ID950000259
StatusPublished
Overview
SCHUNK EGP 50-N-N-IOL servo-electric parallel gripper with IO-Link for small components. Manufacturer specifications are preserved with qualifiers for jaw stroke, grip force, workpiece weight and positioning accuracy.
Product description
SCHUNK EGP 50-N-N-IOL servo-electric parallel gripper with IO-Link for small components. Manufacturer specifications are preserved with qualifiers for jaw stroke, grip force, workpiece weight and positioning accuracy.
Standard specifications
| Product model | EGP 50-N-N-IOL |
|---|---|
| Gripper type | parallel |
| Rated payload | Recommended workpiece mass: 1.05 kg (manufacturer-recommended value; not a rated robot payload) |
| Grip force | Minimum 54 N; maximum 215 N (manufacturer defines gripping force as the arithmetic sum on both jaws) |
| Stroke / opening | 8 mm per jaw |
| Finger length | Maximum permitted finger length: 64 mm |
| Repeatability | Gripping repeat accuracy: 0.02 mm |
| Supply voltage | 24 V |
| Ingress protection | IP30 |
| Dimensions | 59.25 × 30.0 × 109.25 mm (X × Y × Z) |
| Weight | 0.55 kg |
| Operating temperature | 5 to 55 °C |
Additional manufacturer specifications
| Technical extension parameters | Communication interface: IO-Link; gripping modes: FastGrip and SoftGrip; repeat accuracy (positioning): ±0.15 mm unidirectional and ±0.15 mm bidirectional; opening time 0.21 s and closing time 0.21 s (base jaws only; excludes application-specific fingers and PLC reaction time); maximum total current 2.0 A; nominal current 0.3 A; recommended workpiece mass 1.05 kg; maximum permitted finger length 64 mm; maximum permitted finger mass 0.14 kg per finger; cleanroom class ISO 14644-1 Class 5 (1999); two digital inputs; noise emission <70 dB(A); rack-and-pinion operating principle; servo-electric actuation via brushless DC servomotor; coated aluminum-alloy housing and steel base jaws; maximum static moments per jaw Mx 3.0 Nm, My 4.0 Nm, Mz 5.0 Nm; maximum axial force Fz 200 N; 24-month warranty. Manufacturer defines gripping force as the arithmetic sum on both jaws. Recommended workpiece mass is not robot payload. SCHUNK labels the linked image an illustration similar to the selected variant. |
|---|
Image note: SCHUNK labels this linked product image an illustration similar to the selected variant.
Official English manufacturer source: https://schunk.com/de/en/gripping-systems/parallel-gripper/egp/egp-50-n-n-iol/p/000000000001383538
Specifications
Gripper typeparallel
Rated payloadRecommended workpiece mass: 1.05 kg (manufacturer-recommended value; not a rated robot payload)
Grip forceMinimum 54 N; maximum 215 N (manufacturer defines gripping force as the arithmetic sum on both jaws)
Stroke / opening8 mm per jaw
Finger lengthMaximum permitted finger length: 64 mm
Product modelEGP 50-N-N-IOL
RepeatabilityGripping repeat accuracy: 0.02 mm
Supply voltage24 V
Ingress protectionIP30
Dimensions59.25 × 30.0 × 109.25 mm (X × Y × Z)
Weight0.55 kg
Operating temperature5 to 55 °C