Listing typeSupply Product
Record ID950000231
StatusPublished
Overview
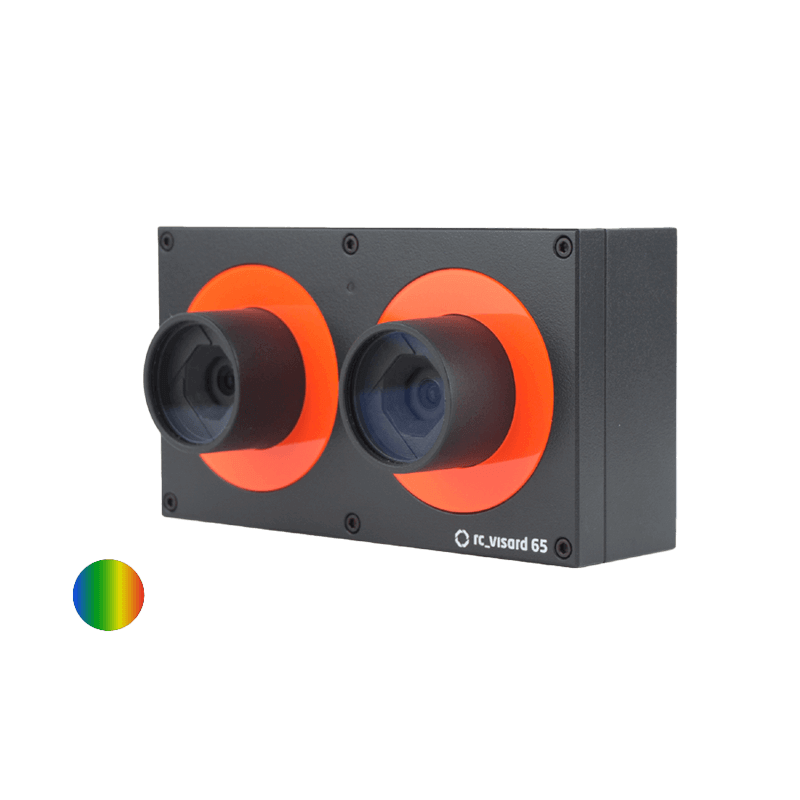
Robot-mounted color 3D stereo sensor with onboard processing for bin-picking, robot guidance and navigation. The rc_visard 65 color variant is optimized for short working distances (typically below 50 cm) where color differentiation is needed.
Product description
The Roboception rc_visard 65 color is a robot-mounted 3D stereo sensor variant for short-range color differentiation. Manufacturer specifications retain lens, depth-mode and target-condition qualifiers.
Standard specifications
| Vision type | stereo |
|---|---|
| Image sensor | Color 3D stereo vision sensor; produces color, depth and ego-motion data |
| Resolution | 1280 × 960 pixels (color image) |
| Field of view | 4 mm lens: 61° H × 48° V; 6 mm lens: 43° H × 33° V (lens-dependent family specification) |
| Working distance | Recommended depth range starts at 200 mm; rc_visard 65 depth range extends to infinity |
| Frame rate | Depth modes: 1280 × 960 Full at 1 Hz (StereoPlus license); 640 × 480 High at 3 Hz; 320 × 240 Medium at 15 Hz; 214 × 160 Low at 25 Hz |
| Data interface | GigE |
| Ingress protection | IP54 |
| Operating temperature | 0 to 50 °C |
| Dimensions | 135 × 75 × 96 mm (W × H × L), rc_visard 65 per manufacturer product page |
| Weight | 0.68 kg |
| SDK | Onboard rc_visard software; optional rc_reason components including SLAM, TagDetect and ItemPick |
| Technical extension parameters | Stereo baseline 65 mm; image resolution 1280 × 960; factory calibrated; global shutter; VINS ego-motion up to 200 Hz. Lens, depth mode and target conditions affect accuracy. |
Source-specific technical extensions
| Stereo baseline | 65 mm |
|---|---|
| Depth-image modes | Full 1280 × 960 @ 1 Hz (StereoPlus); High 640 × 480 @ 3 Hz; Medium 320 × 240 @ 15 Hz; Low 214 × 160 @ 25 Hz |
| Ego-motion rate | 200 Hz, low latency |
| Focal length | Standard 4 mm; manufacturer lists a 6 mm lens option for rc_visard 160 monochrome, not this 65 color variant |
| Computing unit | NVIDIA Tegra K1 |
| Supply voltage | 18–30 V DC; nominal 24 V |
| Maximum power consumption | 25 W |
| Cooling | Passive |
| IR cutoff | 650 nm |
| Connectors | M12 8-pin A-coded network socket (GigE); M12 8-pin A-coded plug for power/GPIO |
| Environmental conditions | 20–80% non-condensing relative humidity; vibration 5 g; shock 50 g |
| Resolution and accuracy | rc_visard 65-4, manufacturer full-resolution stereo results (mm at 200/500/1,000/2,000/3,000 mm): lateral resolution 0.2/0.5/0.9/1.9/2.8; depth resolution 0.04/0.2/0.9/3.6/8.0; average depth accuracy 0.2/0.9/3.6/14.2/32.1. Conditions and lens/mode dependent. |
Sources: Roboception official product page; rc_visard v24.05 datasheet; rc_visard product flyer.
Specifications
Vision typestereo
Image sensorColor 3D stereo vision sensor; produces color, depth and ego-motion data
Resolution1280 × 960 pixels (color image)
Frame rateDepth modes: 1280 × 960 Full at 1 Hz (StereoPlus license); 640 × 480 High at 3 Hz; 320 × 240 Medium at 15 Hz; 214 × 160 Low at 25 Hz
Field of view4 mm lens: 61° H × 48° V; 6 mm lens: 43° H × 33° V (lens-dependent family specification)
Working distanceRecommended depth range starts at 200 mm; rc_visard 65 depth range extends to infinity
Data interfaceGigE
Ingress protectionIP54
Operating temperature0 to 50 °C
Dimensions135 × 75 × 96 mm (W × H × L), rc_visard 65 per manufacturer product page
Weight0.68 kg
SDKOnboard rc_visard software; optional rc_reason components including SLAM, TagDetect and ItemPick
Technical extension parametersStereo baseline 65 mm; image resolution 1280 × 960; factory calibrated; global shutter; VINS ego-motion up to 200 Hz. Lens, depth mode and target conditions affect accuracy.