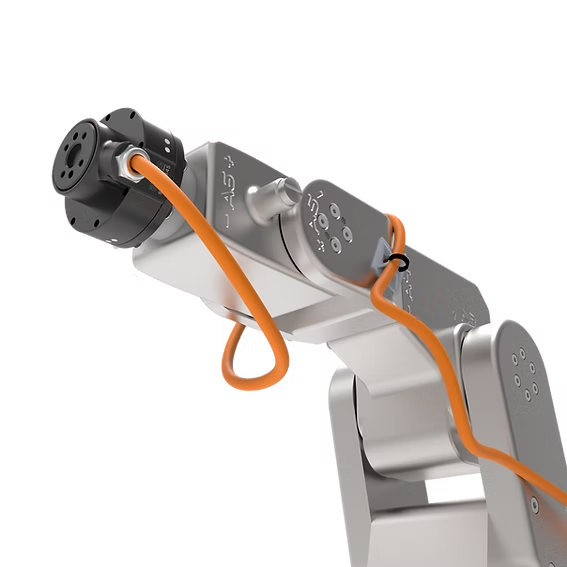
Listing typeSupply Product
Record ID950000166
StatusPublished
Product description
Ultra-sensitive six-axis force-torque sensor for precision assembly, optical alignment, micromanipulation and advanced robot force feedback, with integrated electronics and EtherCAT communication.
Specifications
| Sensor type | force_torque |
|---|---|
| Force range | Fxy 50 N; Fz 50 N |
| Torque range | Mxy 1 Nm; Mz 1 Nm |
| Force noise floor | 35 mN (Fxy); 21 mN (Fz) |
| Torque noise floor | 0.4 mNm (Mxy); 0.3 mNm (Mz) |
| Data interface | EtherCAT |
| Dimensions | 48 × 26.2 mm |
| Weight | 0.062 kg |
| Measurement axes | 6 |
| Overload capacity | High overload protection; configuration-dependent |
| Operating temperature | Suitable for demanding robotic and advanced automation environments |
| Calibration | Integrated sensor electronics; negligible drift and configurable filtering/resolution/update rate |
| Technical extension parameters | 6-DoF IMU and temperature sensors; low latency; direct force and torque data in N and Nm; supports ROS, Python, C++, LabVIEW, MATLAB and TwinCAT; EtherCAT variant supports high-speed robot control and precision alignment. |

Specifications
Sensor typeforce_torque
Force rangeFxy 50 N; Fz 50 N
Torque rangeMxy 1 Nm; Mz 1 Nm
Force resolution35 mN (Fxy); 21 mN (Fz)
Torque resolution0.4 mNm (Mxy); 0.3 mNm (Mz)
Overload capacityHigh overload protection; configuration-dependent
Data interfaceEtherCAT
Dimensions48 × 26.2 mm
Weight0.062 kg
Operating temperatureSuitable for demanding robotic and advanced automation environments
Number of measurement axes6
CalibrationIntegrated sensor electronics; negligible drift and configurable filtering/resolution/update rate
Technical extension parameters6-DoF IMU and temperature sensors; low latency; direct force and torque data in N and Nm; supports ROS, Python, C++, LabVIEW, MATLAB and TwinCAT; EtherCAT variant supports high-speed robot control and precision alignment.