Payload1000 kg
Navigation methodSLAM_LiDAR
Speed1.2 m/s
Battery capacity50 V, 50 Ah, 14S10P
Drive configurationdifferential
Obstacle detection sensorsLiDAR|depth_camera
Product description
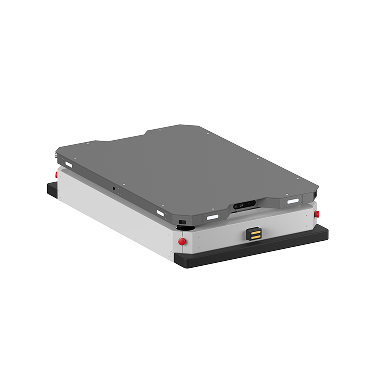
Industrial autonomous mobile robot platform for ultra-heavy material transport up to the 1000 kg class, with SLAM navigation and web-based fleet management.
Specifications
| Product model | RBM-D1000 |
|---|---|
| Drive configuration | Differential drive: active wheel ×2 and dual-wheel caster ×4 |
| Navigation method | Sensor-fusion SLAM autonomous navigation |
| Rated payload | 1000 kg |
| Maximum speed | 1.2 m/s |
| Battery capacity | 50 V, 50 Ah, 14S10P |
| Charging method | Charging station or separate adapter jack |
| Obstacle detection sensors | 2D LiDAR ×2 and 3D depth camera ×1; floor QR optional |
| Dimensions | 800(W) × 1100(D) × 300(H) mm |
| Weight | 150 kg |
| Fleet management | Web-based FMS with real-time operation, logs, alerts and route management |
| Technical extension parameters | Drive wheels 200 mm ×2; caster wheels 125 mm ×4; supports large lifts, conveyors and loading devices; MES/WMS/FMS integration; wireless charging station option |
Specifications
Drive configurationdifferential
Navigation methodSLAM_LiDAR
Rated payload1000 kg
Maximum speed1.2 m/s
Product modelRBM-D1000
Battery capacity50 V, 50 Ah, 14S10P
Obstacle detection sensorsLiDAR|depth_camera
Dimensions800(W) × 1100(D) × 300(H) mm
Weight150 kg
Fleet managementWeb-based FMS with real-time operation, logs, alerts and route management
Technical extension parametersDrive wheels 200 mm ×2; caster wheels 125 mm ×4; supports large lifts, conveyors and loading devices; MES/WMS/FMS integration; wireless charging station option; Official source specifies differential drive (two active wheels and four dual-wheel casters), sensor-fusion SLAM, two 2D LiDARs and one 3D depth camera; floor QR is optional. Charging station or separate adapter jack are listed configurations, not one fixed charging method.